
Robot pcb0

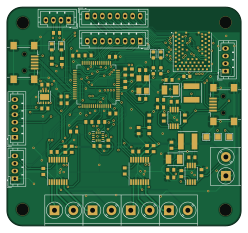
About the Robot pcb0 PCB
Robot pcb0 is an open source STM32 PCB design by svenssonjoel, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 61.9 × 57.8 mm, with 77 components from 34 distinct parts.
Its main chip is the STM32F40X_LQFP64, from the STM32 family. Other key parts include the TJA1051TK-3, BMI160, MCP16311/2, DRV8833PW and BMD-340-A-R. By type, the board carries 33 capacitors, 16 resistors, 13 connectors, 8 ICs, 4 diodes and 2 inductors.
It belongs with the robotics & motion designs in this gallery.
From the project
Four Motor Robot Controller
FMRC: UART communication between NRF52 and STM32!
* PROGRAMMING NRF52 stlink: openocd -f interface/stlink.cfg -f target/nrf52.cfg
telnet localhost 4444 > reset > program zephyr.hex verify
FMRC V2 PART 14: First draft of completely routed PCB
FMRC V2 PART 13: More routing -- finishing off at the DRV8848 area
FMRC V2 PART 12: Starting to route in the DRV8848 area
FMRC V2 PART 9: Tightening up the placement of components
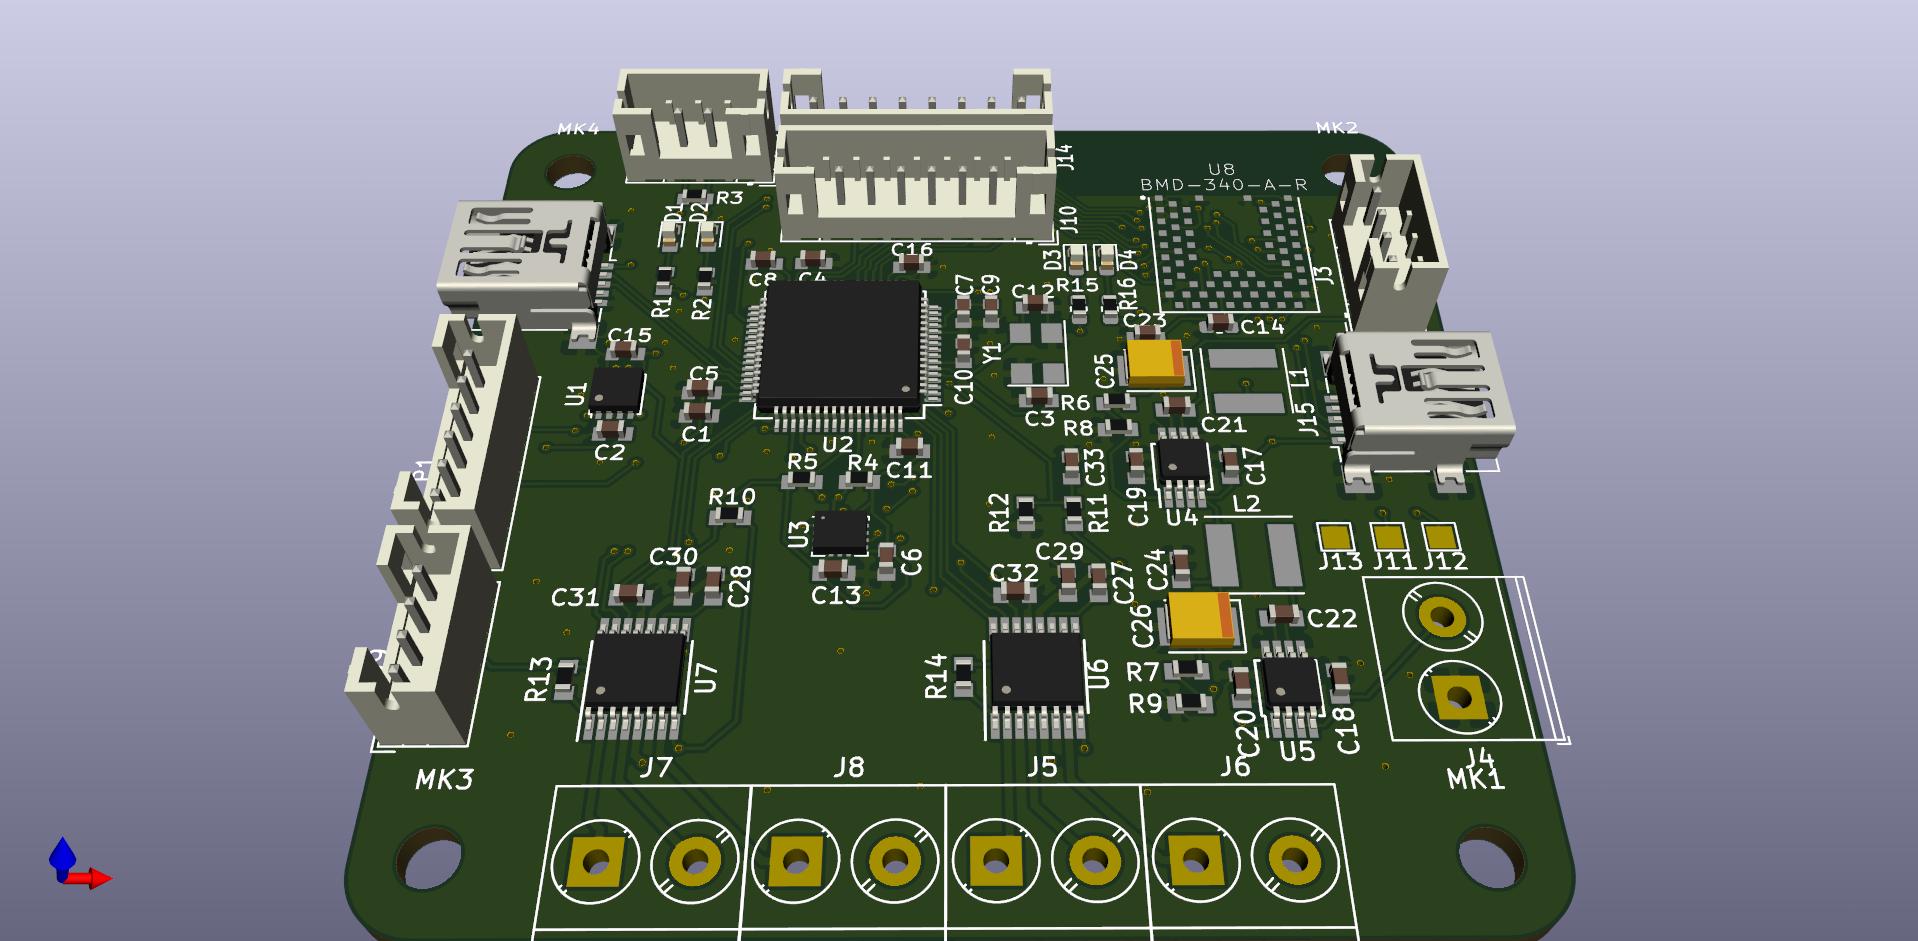
Main components on the Robot pcb0
Robot pcb0 bill of materials (BOM)
77 components, 34 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TJA1051TK-3 | DFN-8-1EP_3x3mm_P0.65mm_EP1.55x2.4mm | U1 |
| 1 | STM32F40X_LQFP64 | LQFP-64_10x10mm_P0.5mm | U2 |
| 1 | BMI160 | Bosch_LGA-14_3x2.5mm_P0.5mm | U3 |
| 2 | MCP16311/2 | MSOP-8_3x3mm_P0.65mm | U4, U5 |
| 2 | DRV8833PW | TSSOP-16_4.4x5mm_P0.65mm | U6, U7 |
| 1 | BMD-340-A-R | RIGADO_BMD-340-A-R | U8 |
| 1 | 8M | Crystal_SMD_5032-4Pin_5.0x3.2mm | Y1 |
| 2 | USB_B_Mini | USB_Mini-B_Lumberg_2486_01_Horizontal | J1, J15 |
| 1 | CAN | JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J2 |
| 1 | PWR | JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J3 |
| 1 | Power_terminal | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J4 |
| 1 | Motor1 | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J5 |
| 1 | Motor2 | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J6 |
| 1 | Motor3 | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J7 |
| 1 | Motor4 | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J8 |
| 1 | UART | JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J9 |
| 1 | GPIO | JST_PH_B8B-PH-K_1x08_P2.00mm_Vertical | J10 |
| 1 | NRFGPIO | JST_PH_B8B-PH-K_1x08_P2.00mm_Vertical | J14 |
| 1 | SWD | JST_PH_B6B-PH-K_1x06_P2.00mm_Vertical | P1 |
| 2 | RED | LED_0603_1608Metric | D1, D3 |
Show 14 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | GREEN | LED_0603_1608Metric | D2, D4 |
| 2 | 22U | L_Taiyo-Yuden_MD-5050 | L1, L2 |
| 22 | 2.2u | C_0603_1608Metric | C1, C2, C4, C5, C6, C7, C8, C9 +14 |
| 2 | 15p | C_0603_1608Metric | C3, C12 |
| 3 | 100n | C_0603_1608Metric | C10, C21, C22 |
| 2 | 100u | CP_EIA-3528-12_Kemet-T | C25, C26 |
| 2 | 0.01uF | C_0603_1608Metric | C27, C28 |
| 2 | 10uF | C_0603_1608Metric | C29, C30 |
| 6 | 1k | R_0603_1608Metric | R1, R2, R4, R5, R15, R16 |
| 1 | 220R | R_0603_1608Metric | R3 |
| 2 | 33k | R_0603_1608Metric | R6, R12 |
| 1 | 52.3k | R_0603_1608Metric | R7 |
| 5 | 10k | R_0603_1608Metric | R8, R9, R10, R13, R14 |
| 1 | 56k | R_0603_1608Metric | R11 |
Robot pcb0 design files
The KiCad project lives in the svenssonjoel/FMRC repository on GitHub; these links point at the commit this page was built from.
Robot pcb0: common questions
What microcontroller does the Robot pcb0 use?
The Robot pcb0 is built around the STM32F40X_LQFP64, from the STM32 family.
How big is the Robot pcb0 PCB?
The Robot pcb0 measures 61.9 × 57.8 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot pcb0?
77 components, from 34 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot pcb0 design files?
From the svenssonjoel/FMRC repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Robot pcb0 design in my own project?
Yes, under the terms of its GPL-3.0 license, which svenssonjoel chose for the repository.
Can I test firmware for the Robot pcb0 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in FMRC
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
LibreVNA
jankae
122 × 98 mm592 parts6LGPL-3.01.6k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k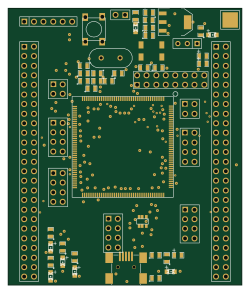 STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k