
VEPR-Robotarm

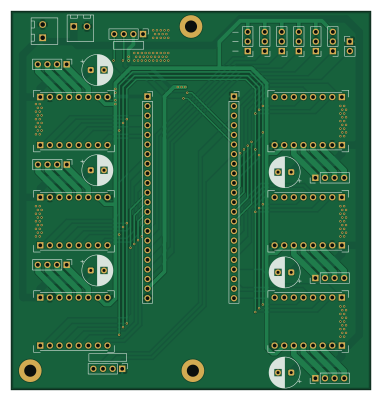
About the VEPR-Robotarm PCB
VEPR-Robotarm is an open source ESP32 PCB design by Vinomakon, published on GitHub. It is a 2-layer board measuring 95 × 100 mm, with 30 components from 14 distinct parts.
Its main chip is the ESP32-S3-DEVKITM, from the ESP32 family. Other key parts include the SILENTSTEPSTICK TMC2130. By type, the board carries 17 connectors, 7 ICs and 6 capacitors.
It belongs with the robotics & motion designs in this gallery, and the repository also holds 1 earlier revision of it.
From the project
The driver carrier v2 includes its project, PCB, hierarchical schematic sheets, and unpacked Gerber outputs. The v1 source design is retained for reference because the board revision on the physical robot is unconfirmed. Original subfolder names are preserved.
The driver carrier v2 includes its project, PCB, hierarchical schematic sheets, and unpacked Gerber outputs. The v1 source design is retained for reference because the board revision on the physical robot is unconfirmed. Original subfolder names are preserved.
KiCad Custom Libraries/ keeps the original custom symbols and footprints. Automatic backups, editor preferences, footprint caches, duplicate Gerber ZIPs, and the broad third-party Espressif library/model cache were omitted. The separate mock ESP32 board experiment remains in the original repository.
Main components on the VEPR-Robotarm
VEPR-Robotarm bill of materials (BOM)
30 components, 14 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | SILENTSTEPSTICK TMC2130 | SILENTSTEPSTICK TMC2130 | U1, U2, U3, U4, U5, U6 |
| 1 | ESP32-S3-DEVKITM | ESP32-S3-DEVKITM Female Headers | U13 |
| 6 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Vertical | J1, J2, J3, J4, J5, J6 |
| 1 | Limit Switch Connector n1 | PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | Limit Switch Connector n2 | PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | Limit Switch Connector n3 | PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | Limit Switch Connector n4 | PinHeader_1x03_P2.54mm_Vertical | J10 |
| 1 | Limit Switch Connector n5 | PinHeader_1x03_P2.54mm_Vertical | J11 |
| 1 | Limit Switch Connector n6 | PinHeader_1x03_P2.54mm_Vertical | J12 |
| 1 | CAN Connector | PinHeader_1x04_P2.54mm_Vertical | J13 |
| 2 | Screw_Terminal_01x02 | Phoenix_TerminalBlock_1x02_3.5mm_1984617 | J14, J15 |
| 1 | Controller Reset | PinHeader_1x02_P2.54mm_Vertical | J16 |
| 1 | Remaining GPIOs | PinHeader_1x04_P2.54mm_Vertical | J17 |
| 6 | 100uF/50V 20% | CP_Radial_D8.0mm_P3.50mm | C1, C2, C3, C4, C5, C6 |
VEPR-Robotarm design files
The KiCad project lives in the Vinomakon/VEPR-Robotarm repository on GitHub; these links point at the commit this page was built from.
VEPR-Robotarm: common questions
What microcontroller does the VEPR-Robotarm use?
The VEPR-Robotarm is built around the ESP32-S3-DEVKITM, from the ESP32 family.
How big is the VEPR-Robotarm PCB?
The VEPR-Robotarm measures 95 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the VEPR-Robotarm?
30 components, from 14 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the VEPR-Robotarm design files?
From the Vinomakon/VEPR-Robotarm repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the VEPR-Robotarm design in my own project?
The repository has no license, so all rights stay with Vinomakon. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the VEPR-Robotarm without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Earlier revisions in the repo: Driver Carrier v1
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Esp32 minimal
atopile
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Badge
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k