
Multirotor ros

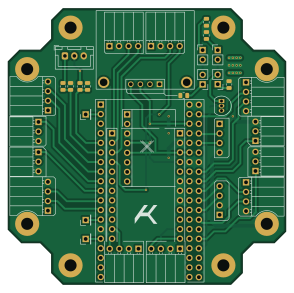
About the Multirotor ros PCB
Multirotor ros is an open source ESP32 PCB design by adnksharp, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 73.5 × 73 mm, with 36 components from 20 distinct parts.
Its main chip is the ESP32-DEVKITC-V4, from the ESP32 family. By type, the board carries 9 resistors, 4 connectors, 4 diodes, 1 IC, 1 transistor and 1 LED.
It belongs with the sensors designs in this gallery.
From the project
Plataforma de adquisición de datos de un multirotor con ESP32 y ROS2
El proyecto se desarrolló usando KiCAD. electronic.kicad_pro se desarrollo para comunicar multiples sensores a una placa de ESP32. Los componentes utilizados para esta PCB son:
1 ESP32 WROOM-32 DevKit 1 Módulo MPU6050 1 Módulo BMP280 1 Módulo NEO6M GPS 1 Pantalla OLED 128x64 1 Sensor DHT22 1 Resistencia de 10K $\Omega$ 4 Módulos HC-SR04 1 Conector B2B-XH-A para la batería 1 Conector B4B-XH-A para los motores PinSockets** de 2.54mm
Main components on the Multirotor ros
Multirotor ros bill of materials (BOM)
36 components, 20 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32-DEVKITC-V4 | MODULE_ESP32-DEVKITC-V4 | U1 |
| 1 | 2222A | TO-92_Inline | Q1 |
| 3 | Conn_01x01 | PinHeader_1x01_P2.54mm_Vertical | J1, J3, J4 |
| 1 | Conn_01x02 | PinHeader_1x04_P2.54mm_Vertical | J5 |
| 4 | AS5600-ASOT | PinSocket_1x04_P2.54mm_Horizontal | AS1, AS2, AS3, AS4 |
| 1 | BAT | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | BAT1 |
| 1 | ESC | ESC1 | ESC1 |
| 1 | ESC | ESC2 | ESC2 |
| 1 | ESC | ESC3 | ESC3 |
| 1 | ESC | ESC4 | ESC4 |
| 1 | MPU+BMP280 | MPU9250 | MPU1 |
| 1 | NEO6M-GPS | PinHeader_1x04_P2.54mm_Vertical | NEO1 |
| 1 | TCA9548AMRGER | TCA9548A | TCA1 |
| 4 | HC-SR04 | PinSocket_1x04_P2.54mm_Horizontal | ULTRA1, ULTRA2, ULTRA3, ULTRA4 |
| 1 | OLED DISPLAY | MODULE_DM-OLED096-636 | OLED1 |
| 4 | LED | PinHeader_1x02_P2.54mm_Vertical | D1, D2, D3, D4 |
| 2 | 390k | R_0805_2012Metric | R1, R2 |
| 2 | 100k | R_0805_2012Metric | R3, R4 |
| 4 | 220 | R_0805_2012Metric | R5, R6, R7, R8 |
| 1 | 330 | R_0805_2012Metric | R9 |
Multirotor ros design files
The KiCad project lives in the adnksharp/multirotor-ros repository on GitHub; these links point at the commit this page was built from.
Multirotor ros: common questions
What microcontroller does the Multirotor ros use?
The Multirotor ros is built around the ESP32-DEVKITC-V4, from the ESP32 family.
How big is the Multirotor ros PCB?
The Multirotor ros measures 73.5 × 73 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Multirotor ros?
36 components, from 20 distinct parts. The full bill of materials is listed on this page.
Where can I download the Multirotor ros design files?
From the adnksharp/multirotor-ros repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Multirotor ros design in my own project?
Yes, under the terms of its GPL-3.0 license, which adnksharp chose for the repository.
Can I test firmware for the Multirotor ros without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k