
Robodev Actuators

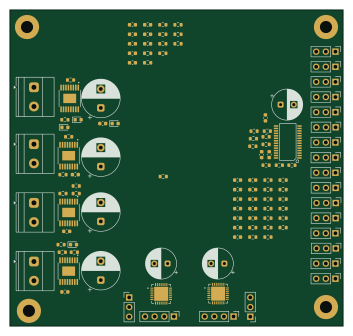
About the Robodev Actuators PCB
Robodev Actuators is an open source PCB design by alexbnz-1, published on GitHub under the MIT license. It is a 4-layer board measuring 88 × 83.5 mm, with 113 components from 25 distinct parts.
It belongs with the robotics & motion, dev boards & breakouts and sensors designs in this gallery.
From the project
A repository for the development of a robotics development board designed to aid in the development of robotics projects
An open-source STM32-based robotics carrier board with integrated WiFi. Plug in power, plug in your motors and sensors — that's it. No breadboard, no stacked breakout boards, no wiring harness.
Five independent rails from a single XT60 input with reverse polarity protection (IRF4905 P-channel MOSFET) and a slide switch.
VMOT and VSTEP are separate adjustable bucks so DC motors and steppers can run at different voltages simultaneously.
Robodev Actuators bill of materials (BOM)
113 components, 25 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 4.7 µF 10V X5R | C_0603_1608Metric | C_5VOUT1, C_5VOUT2 |
| 1 | 22nF 50V X7R | C_0603_1608Metric | C_CP1 |
| 3 | 22 nF 50V X7R | C_0603_1608Metric | C_CP2, C_CP3, C_CP4 |
| 15 | 100 nF 50V X7R | C_0603_1608Metric | C_CPS1, C_CPS2, C_VCP1, C_VCP2, C_VCP3, C_VCP4, C_VCPS1, C_VCPS2 +7 |
| 5 | 100 nF 10V X7R | C_0603_1608Metric | C_VCC1, C_VCC2, C_VDD_SERVO1, C_VREFS1, C_VREFS2 |
| 1 | 10 µF 10V X5R | C_0603_1608Metric | C_VDD_BULK_SERVO1 |
| 4 | 470 µF 50V electrolytic | CP_Radial_D10.0mm_P5.00mm | C_VM1, C_VM2, C_VM3, C_VM4 |
| 2 | 100 µF 50V electrolytic | CP_Radial_D8.0mm_P3.50mm | C_VS1, C_VS2 |
| 1 | 220 µF 25V electrolytic | CP_Radial_D8.0mm_P3.50mm | C_VSERVO_BULK1 |
| 4 | Conn_01x02 | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J_M1, J_M2, J_M3, J_M4 |
| 2 | Stepper 4-pin 2.54mm | PinHeader_1x04_P2.54mm_Vertical | J_S1, J_S2 |
| 1 | Stepper 1 DIAG/INDEX | PinHeader_1x03_P2.54mm_Vertical | J_S1_DIAG1 |
| 1 | Stepper 2 DIAG/INDEX | PinHeader_1x03_P2.54mm_Vertical | J_S2_DIAG1 |
| 16 | Conn_01x03 | PinHeader_1x03_P2.54mm_Vertical | J_SV0, J_SV1, J_SV2, J_SV3, J_SV4, J_SV5, J_SV6, J_SV7 +8 |
| 15 | 100 kΩ 1% 0603 | R_0603_1608Metric | R_A0, R_A1, R_A2, R_A3, R_A4, R_A5, R_CLK1, R_CLK2 +7 |
| 10 | 1 kΩ 1% 0603 | R_0603_1608Metric | R_FAULT_LED1, R_FAULT_LED2, R_FAULT_LED3, R_FAULT_LED4, R_IPROPI1, R_IPROPI2, R_IPROPI3, R_IPROPI4 +2 |
| 7 | 10 kΩ 1% 0603 | R_0603_1608Metric | R_FAULT_PU1, R_FAULT_PU2, R_FAULT_PU3, R_FAULT_PU4, R_MS1_S2, R_VREF_H1, R_VREF_H2 |
| 4 | 20 kΩ 1% 0603 | R_0603_1608Metric | R_IMODE1, R_IMODE2, R_IMODE3, R_IMODE4 |
| 2 | 4.7 kΩ 1% 0603 | R_0603_1608Metric | R_SCL1, R_SDA1 |
| 4 | 100 mΩ 1% 0603 | R_0603_1608Metric | R_SENSE_SA1, R_SENSE_SA2, R_SENSE_SB1, R_SENSE_SB2 |
Show 5 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 27 kΩ 1% 0603 | R_0603_1608Metric | R_VREF_L1, R_VREF_L2 |
| 4 | DRV8874PWPR | SOP65P640X120-17N | U_M1, U_M2, U_M3, U_M4 |
| 2 | TMC2209-LA-T | QFN50P500X500X90-29N | U_S1, U_S2 |
| 1 | PCA9685PW | TSSOP28-0.65-9.7X4.4MM | U_SERVO1 |
| 4 | LTST-C190KRKT Red | LED_0603_1608Metric | LED_FAULT1, LED_FAULT2, LED_FAULT3, LED_FAULT4 |
Robodev Actuators design files
The KiCad project lives in the alexbnz-1/RoboDev repository on GitHub; these links point at the commit this page was built from.
Robodev Actuators: common questions
How big is the Robodev Actuators PCB?
The Robodev Actuators measures 88 × 83.5 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Robodev Actuators?
113 components, from 25 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robodev Actuators design files?
From the alexbnz-1/RoboDev repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robodev Actuators design in my own project?
Yes, under the terms of its MIT license, which alexbnz-1 chose for the repository.
More boards in RoboDev
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
Eecv breakout
rusefi
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
134pin 7-967288-1
139.7 × 73.7 mm38 parts2LGPL-3.01.2k