
C robot

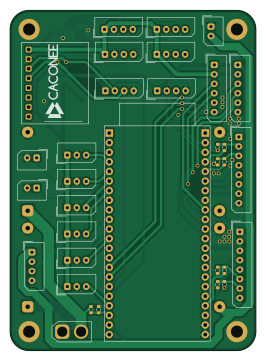
About the C robot PCB
C robot is an open source ESP32 PCB design by caconee22, published on GitHub. It is a 2-layer board measuring 65 × 90 mm, with 47 components from 30 distinct parts.
Its main chip is the YD-ESP32-S3, from the ESP32 family. Other key parts include the AMS1117-3.3 and TCA9548APWR. By type, the board carries 21 connectors, 17 resistors, 5 ICs, 3 capacitors and 1 module.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
ESP32-S3 주행 제어, 라즈베리파이 영상 처리, 회로 설계를 관리하는 저장소다. 현재 주행 펌웨어는 V1 하드웨어를 대상으로 한다.
ESP32-S3 주행 제어, 라즈베리파이 영상 처리, 회로 설계를 관리하는 저장소다. 현재 주행 펌웨어는 V1 하드웨어를 대상으로 한다.
처음 사용하는 사람은 펌웨어 구조·사용법 전체 설명을 먼저 읽는다. 파일별 책임, 실제 FSM/안전 흐름, 센서 설정·교정, UART 규격, 모터 API, 주기와 실물 시험 순서를 설명한다. 별도 벤치의 콘솔/CSV는 BENCH_TESTS.md, 검토 근거는 VERIFICATION.md에 있다. 아래는 저장소 전체와 영상 프로그램 안내다.
2026-10-05 기준, ESP32 펌웨어는 부팅부터 센서·통신·안전·FSM·모터 출력까지 연결했다. 하드웨어 없는 자동 시험과 ESP32용 빌드를 통과했으며, 실제 기체 시험과 튜닝은 남아 있다. 컴파일/PC 시험 통과를 실제 차량의 완전한 동작 보증으로 해석하면 안 된다.
Main components on the C robot
C robot bill of materials (BOM)
47 components, 30 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | ~ | XL4015 | U1, U2 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U3 |
| 1 | TCA9548APWR | TSSOP-24_4.4x7.8mm_P0.65mm | U4 |
| 1 | ~ | MPU6050 | U5 |
| 1 | YD-ESP32-S3 | YD-ESP32-S3 | A1 |
| 1 | IR1 | Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J1 |
| 1 | IR2 | Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J2 |
| 1 | IR3 | Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J3 |
| 1 | IR4 | Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J4 |
| 1 | CONN_01X02 Conn_01x02 | AMASS_XT30U-M_1x02_P5.0mm_Vertical | J5 |
| 1 | CONN_01X02 Conn_01x02 | Molex_SPOX_5267-02A_1x02_P2.50mm_Vertical | J6 |
| 1 | IR5 | Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J7 |
| 1 | IR6 | Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J8 |
| 2 | CONN_01X08 Conn_01x08 | Molex_SPOX_5267-08A_1x08_P2.50mm_Vertical | J9, J10 |
| 1 | AS7341_1 | Molex_SPOX_5267-04A_1x04_P2.50mm_Vertical | J11 |
| 1 | AS7341_2 | Molex_SPOX_5267-04A_1x04_P2.50mm_Vertical | J12 |
| 2 | CONN_01X06 Conn_01x06 | Molex_SPOX_5267-06A_1x06_P2.50mm_Vertical | J13, J16 |
| 1 | AS7341_3 | Molex_SPOX_5267-04A_1x04_P2.50mm_Vertical | J14 |
| 1 | AS7341_4 | Molex_SPOX_5267-04A_1x04_P2.50mm_Vertical | J15 |
| 1 | SW1 | Molex_SPOX_5267-02A_1x02_P2.50mm_Vertical | J17 |
Show 10 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SW2 | Molex_SPOX_5267-02A_1x02_P2.50mm_Vertical | J18 |
| 3 | UART | Molex_SPOX_5267-04A_1x04_P2.50mm_Vertical | J19, J20, J21 |
| 2 | 10UF 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2 |
| 1 | 0.1UF 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3 |
| 1 | 100K | R_0603_1608Metric | R1 |
| 4 | 10K | R_0603_1608Metric | R2, R15, R16, R17 |
| 4 | 1K | R_0603_1608Metric | R3, R4, R7, R8 |
| 4 | 470 | R_0603_1608Metric | R5, R6, R9, R10 |
| 2 | 6.8K | R_0603_1608Metric | R11, R13 |
| 2 | 4.7K | R_0603_1608Metric | R12, R14 |
C robot design files
The KiCad project lives in the caconee22/c_robot repository on GitHub; these links point at the commit this page was built from.
- LayoutPCBV2/C_ROBOT.kicad_pcb
- SchematicPCBV2/C_ROBOT.kicad_sch
- BOMPCBV2/production/bom.csv
C robot: common questions
What microcontroller does the C robot use?
The C robot is built around the YD-ESP32-S3, from the ESP32 family.
How big is the C robot PCB?
The C robot measures 65 × 90 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the C robot?
47 components, from 30 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the C robot design files?
From the caconee22/c_robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the C robot design in my own project?
The repository has no license, so all rights stay with caconee22. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the C robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k