
EMG-Mechanical-Arm

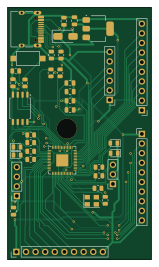
About the EMG-Mechanical-Arm PCB
EMG-Mechanical-Arm is an open source RP2040/RP2350 PCB design by dominicmorris002, published on GitHub under the CC-BY-NC-4.0 license. It is a 2-layer board measuring 38 × 66.6 mm, with 39 components from 21 distinct parts.
Its main chip is the RP2040, from the RP2040/RP2350 family. Other key parts include the W25Q32JVSS and AMS1117-3.3. By type, the board carries 15 resistors, 7 capacitors, 5 diodes, 3 ICs, 3 connectors and 1 crystal.
It belongs with the usb & debug tools designs in this gallery.
From the project
EMG Mechanical Arm
A myoelectric prosthetic arm that uses surface EMG signals to detect muscle gestures and drive a mechanical arm via a DC motor. The system consists of a MyoWare 2.0 EMG sensor, an RP2040 microcontroller, DC motor driver H Bridge, Electrode Pads and Cable for Myoware Sensor, and a DC motor to control a 3D-printed mechanical arm.
The RP2040 reads raw ADC values from the EMG sensor and uses the data to drive the H-Bridge to control the motor
Main components on the EMG-Mechanical-Arm
EMG-Mechanical-Arm bill of materials (BOM)
39 components, 21 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | W25Q32JVSS | SOIC-8_5.23x5.23mm_P1.27mm | U1 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U2 |
| 1 | RP2040 | QFN-56-1EP_7x7mm_P0.4mm_EP3.2x3.2mm | U3 |
| 1 | 12MHZ 12Mhz | Crystal_SMD_SeikoEpson_FA238V-4Pin_3.2x2.5mm | Y1 |
| 1 | USB_C_RECEPTACLE_USB2.0_16P USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J1 |
| 1 | CONN_01X03 Conn_01x03 | PinSocket_1x03_P2.54mm_Vertical | J2 |
| 1 | CONN_01X04 Conn_01x04 | PinSocket_1x04_P2.54mm_Vertical | J3 |
| 1 | CONN_01X10 Conn_01x10 | PinHeader_1x10_P2.54mm_Vertical | GPIOS1 |
| 2 | Conn_01x10 | PinHeader_1x10_P2.54mm_Vertical | H-Bridge1, H-Bridge2 |
| 1 | CONN_01X06 Conn_01x06 | PinHeader_1x06_P2.54mm_Vertical | MyowareSensors1 |
| 1 | SW_SPST | SW_SPST_CK_RS282G05A3 | SW1 |
| 1 | D_Schottky_Small | D_SMA | D1 |
| 4 | LED | LED_0805_2012Metric | D2, D3, D4, D5 |
| 3 | 100NF 100nF | C_0805_2012Metric | C1, C2, C9 |
| 4 | 10UF 10uF | C_0805_2012Metric | C4, C6, C7, C8 |
| 6 | 1k | R_0805_2012Metric | R1, R9, R10, R13, R14, R15 |
| 2 | 10K 10k | R_0805_2012Metric | R2, R7 |
| 2 | 27 | R_0805_2012Metric | R3, R4 |
| 2 | 5.1K | R_0805_2012Metric | R5, R6 |
| 1 | 100 | R_0805_2012Metric | R8 |
Show 1 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 4.7K 4.7k | R_0805_2012Metric | R11, R12 |
EMG-Mechanical-Arm design files
The KiCad project lives in the dominicmorris002/EMG-Mechanical-Arm repository on GitHub; these links point at the commit this page was built from.
EMG-Mechanical-Arm: common questions
What microcontroller does the EMG-Mechanical-Arm use?
The EMG-Mechanical-Arm is built around the RP2040, from the RP2040/RP2350 family.
How big is the EMG-Mechanical-Arm PCB?
The EMG-Mechanical-Arm measures 38 × 66.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the EMG-Mechanical-Arm?
39 components, from 21 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the EMG-Mechanical-Arm design files?
From the dominicmorris002/EMG-Mechanical-Arm repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the EMG-Mechanical-Arm design in my own project?
It is published under CC-BY-NC-4.0, which limits how it may be reused; read the license before building on it.
Can I test firmware for the EMG-Mechanical-Arm without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Msa
Mentra-Community
47.8 × 9.4 mm53 parts2LMIT1.2k RP2040/RP2350
Open Source Smart Glasses
93 × 10.5 mm80 parts4LMIT1.2k RP2040/RP2350
MSA
30.5 × 138 mm61 parts2LMIT1.2k