
PicoServo

About the PicoServo PCB
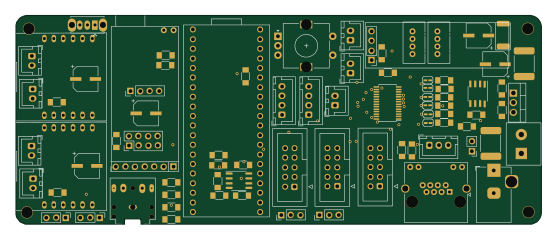
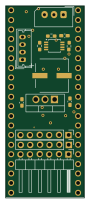
PicoServo is an open source Raspberry Pi PCB design by edwindertien, published on GitHub. It is a 2-layer board measuring 20.7 × 50.7 mm, with 19 components from 13 distinct parts.
Its main chip is the Module_RaspberryPi_PicoW_SocketTHT, from the Raspberry Pi family. Other key parts include the LM7805_TO220 and MAX14783ExS. By type, the board carries 5 connectors, 5 resistors, 4 capacitors, 2 ICs and 1 module.
It belongs with the robotics & motion, displays & leds and rf & radio designs in this gallery.
From the project
- the MegaAnimaltroniek board is used to controls the bell's and whistles on the animaltroniek machines. Effectively it uses a design developed earlier as 'main' control board. For the animalLove robot it is equipped with a 433Mhz RF link at 9600 bd instead of the (standard) RS48
- the MegaAnimaltroniek board is used to controls the bell's and whistles on the animaltroniek machines. Effectively it uses a design developed earlier as 'main' control board. For the animalLove robot it is equipped with a 433Mhz RF link at 9600 bd instead of the (standard) RS485 (57600 bd) over UTP cable. These settings (per vehicle) are placed in the config.h file - the picoControl module which is designed to interface with different radio modules, links to RS485/dynamixel, has two sound modules and expansion ports for Relays and / or Servos (using PCF9685) or PCF9635 (pin compatible) for…
Main components on the PicoServo
PicoServo bill of materials (BOM)
19 components, 13 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LM7805_TO220 | TO-220-3_Vertical | U1 |
| 1 | MAX14783ExS | SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | Module_RaspberryPi_PicoW_SocketTHT | RaspberryPi_PicoW_SocketTHT | M1 |
| 1 | GND | PinHeader_1x06_P2.54mm_Horizontal | J1 |
| 1 | signals | PinHeader_1x06_P2.54mm_Vertical | J2 |
| 1 | VCC | PinHeader_1x06_P2.54mm_Vertical | J3 |
| 1 | grove | Molex_Micro-Latch_53253-0470_1x04_P2.00mm_Vertical | J4 |
| 1 | molex | Molex_SPOX_5267-04A_1x04_P2.50mm_Vertical | J5 |
| 2 | 5V 3.3V | SolderJumper-3_P1.3mm_Bridged2Bar12_RoundedPad1.0x1.5mm_NumberLabels | 123, 456 |
| 1 | 470u | CP_Elec_D8.0mm | C1 |
| 3 | 100n | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C2, C3, C4 |
| 3 | R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2, R3 |
| 2 | 4k7 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R4, R5 |
PicoServo design files
The KiCad project lives in the edwindertien/animatronics repository on GitHub; these links point at the commit this page was built from.
PicoServo: common questions
What microcontroller does the PicoServo use?
The PicoServo is built around the Module_RaspberryPi_PicoW_SocketTHT, from the Raspberry Pi family.
How big is the PicoServo PCB?
The PicoServo measures 20.7 × 50.7 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the PicoServo?
19 components, from 13 distinct parts. The full bill of materials is listed on this page.
Where can I download the PicoServo design files?
From the edwindertien/animatronics repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the PicoServo design in my own project?
The repository has no license, so all rights stay with edwindertien. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the PicoServo without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
More boards in animatronics
Similar boards
 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k Raspberry Pi
Iot
dotnet
56 × 65 mm24 parts2LMIT2.4k Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license672 Raspberry Pi
Phased
Neumi
75 × 100 mm71 parts2LNo license507