
QuadMotorHAT

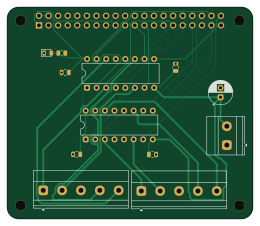
About the QuadMotorHAT PCB
QuadMotorHAT is an open source PCB design by itsjeanxx12, published on GitHub under the MIT license. It is a 2-layer board measuring 65 × 56 mm, with 13 components from 9 distinct parts.
Other key parts include the L293D. By type, the board carries 5 capacitors, 4 connectors, 2 ICs, 1 diode and 1 resistor.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
A custom Raspberry Pi HAT for controlling four DC motors with simple Python control.
A simple Raspberry Pi HAT for controlling four DC motors.
While making my WRO robot, I ran into a problem: I needed to control multiple motors from a Raspberry Pi without a mess of separate boards and wiring.
There are already plenty of motor HATs available, but I wanted something simple that fit what I needed. So I decided to design my own.
4 motor control — Control four motors from the Raspberry Pi using the included Python library. Screw terminals — Secure connections for the motors and power. Compact design — Keeps a low profile while leaving enough room for a cooling fan on the…
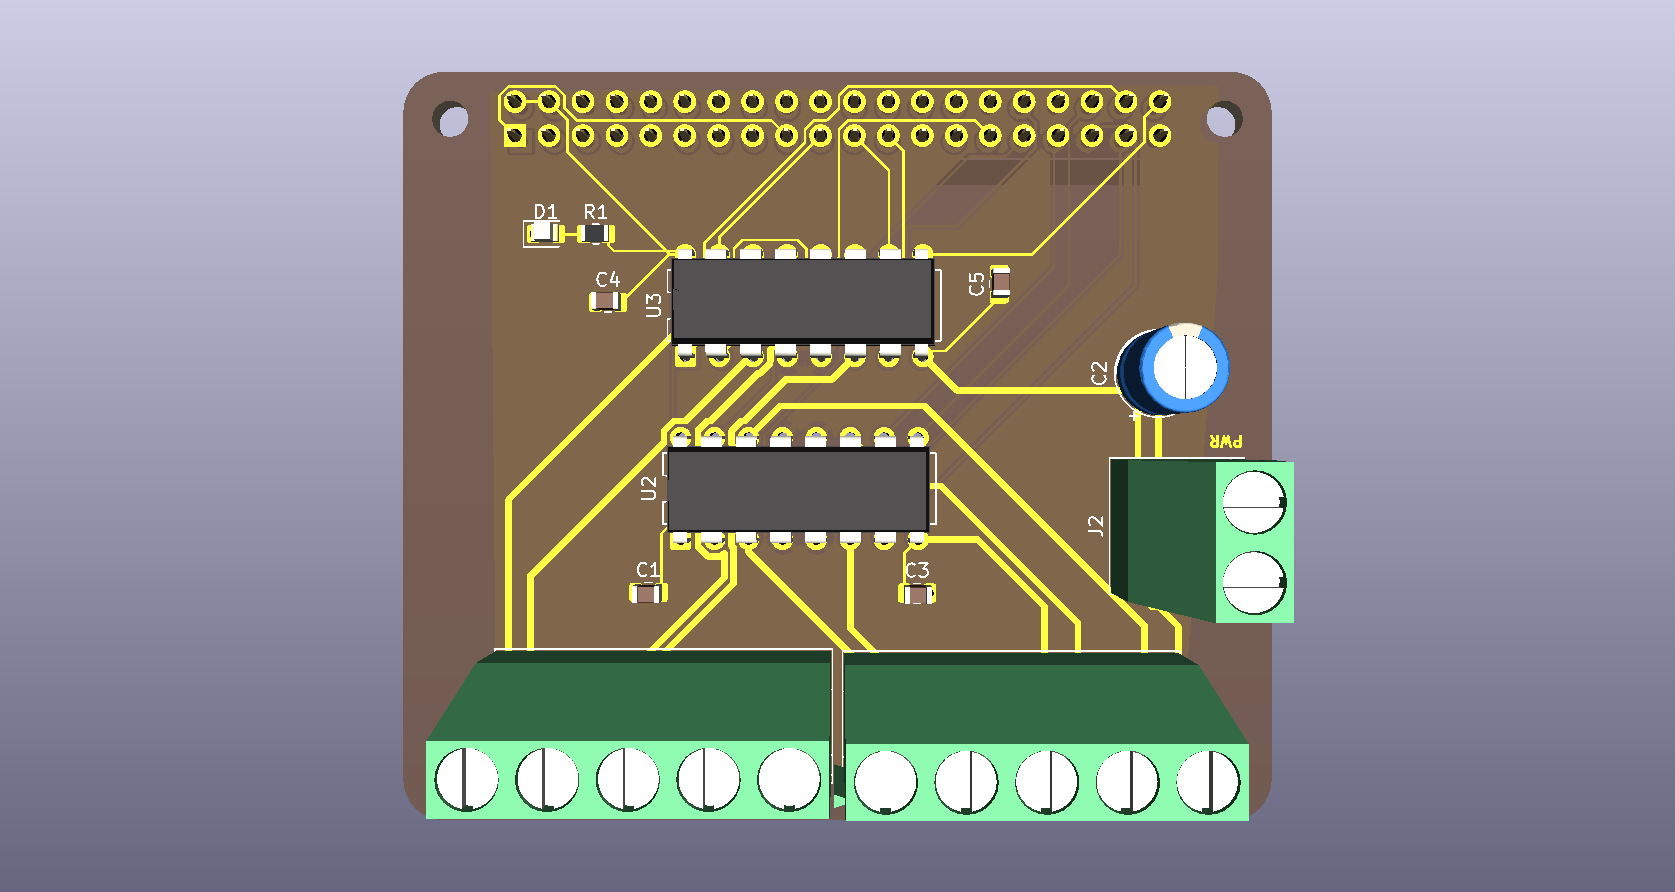
Main components on the QuadMotorHAT
QuadMotorHAT bill of materials (BOM)
13 components, 9 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | L293D | DIP-16_W7.62mm | U2, U3 |
| 1 | GPIO | PinSocket_2x20_P2.54mm_Vertical | J1 |
| 1 | MPWR | TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J2 |
| 1 | M3/GND/M4 | TerminalBlock_Phoenix_MKDS-1,5-5_1x05_P5.00mm_Horizontal | J3 |
| 1 | M1/GND/M2 | TerminalBlock_Phoenix_MKDS-1,5-5_1x05_P5.00mm_Horizontal | J4 |
| 1 | LED | LED_0805_2012Metric | D1 |
| 4 | 0.1UF 0.1uF | C_0805_2012Metric | C1, C3, C4, C5 |
| 1 | 100uF 35V | CP_Radial_D6.3mm_P2.50mm | C2 |
| 1 | 330 | R_0805_2012Metric | R1 |
QuadMotorHAT design files
The KiCad project lives in the itsjeanxx12/QuadMotorHAT repository on GitHub; these links point at the commit this page was built from.
QuadMotorHAT: common questions
How big is the QuadMotorHAT PCB?
The QuadMotorHAT measures 65 × 56 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the QuadMotorHAT?
13 components, from 9 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the QuadMotorHAT design files?
From the itsjeanxx12/QuadMotorHAT repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the QuadMotorHAT design in my own project?
Yes, under the terms of its MIT license, which itsjeanxx12 chose for the repository.
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Breakout 60pin EEC-IV
rusefi
139.7 × 62.2 mm15 parts2LGPL-3.01.2k
134pin 7-967288-1
139.7 × 73.7 mm38 parts2LGPL-3.01.2k
Breakout 112pin Connector
174 × 58 mm39 parts2LGPL-3.01.2k
Eecv breakout
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
88 Pin Vag Breakout
142 × 58 mm91 parts2LGPL-3.01.2k