
Vehicle movement parameters

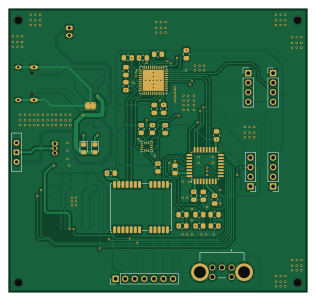
About the Vehicle movement parameters PCB
Vehicle movement parameters is an open source STM32 PCB design by Iverson-45, published on GitHub. It is a 2-layer board measuring 79 × 75 mm, with 54 components from 27 distinct parts.
Its main chip is the STM32F411CEUx, from the STM32 family. Other key parts include the BMI160, NEO-M8N, TP4056-42-ESOP8, MCP1700-3302E and STM32F303K8Tx. By type, the board carries 20 capacitors, 16 resistors, 7 connectors, 6 ICs, 2 switches and 2 diodes.
It belongs with the sensors, power & battery and test & measurement designs in this gallery.
From the project
Academic group project
Vehicle Movement Parameters Meter ------
Authors: Jakub Litwin, Mateusz Prądziński, Adrian Andrószowski, Błażej Szkobel Overview
The goal of this project is to design and build a prototype device capable of measuring, calculating, and displaying real-time vehicle movement parameters. To ensure high data throughput, low latency, and a responsive UI, the system utilizes a Dual-MCU architecture that effectively splits the workload between sensor processing and data logging/display. Calculated & Displayed Parameters:
Main components on the Vehicle movement parameters
Vehicle movement parameters bill of materials (BOM)
54 components, 27 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F411CEUx | QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm | U1 |
| 1 | BMI160 | Bosch_LGA-14_3x2.5mm_P0.5mm | U2 |
| 1 | NEO-M8N | ublox_NEO | U3 |
| 1 | TP4056-42-ESOP8 | SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.41x3.3mm_ThermalVias | U4 |
| 1 | MCP1700-3302E | TO-92_Inline | U5 |
| 1 | STM32F303K8Tx | LQFP-32_7x7mm_P0.8mm | U6 |
| 1 | USB_C_Receptacle_USB2.0_14P | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J1 |
| 1 | UART1 | PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | UART2 | PinHeader_1x04_P2.54mm_Vertical | J3 |
| 1 | Micro_SD_Card_Det1 | microSD_HC_Hirose_DM3AT-SF-PEJM5 | J4 |
| 1 | LCD | PinHeader_1x07_P2.54mm_Vertical | J5 |
| 1 | Programing1 | PinHeader_1x04_P2.54mm_Vertical | J7 |
| 1 | Programing2 | PinHeader_1x04_P2.54mm_Vertical | J8 |
| 1 | Battery_Cell | JST_PH_S2B-PH-K_1x02_P2.00mm_Horizontal | BT1 |
| 1 | SW_Wuerth_450301014042 | SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mm | SW1 |
| 1 | RotaryEncoder_Switch_MP | EC11B15242AE | SW2 |
| 2 | LED | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D1, D2 |
| 3 | 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2, C3 |
| 1 | 4.7uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4 |
| 11 | 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5, C6, C7, C8, C10, C11, C12, C13 +3 |
Show 7 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 100n | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C9, C17 |
| 3 | 10nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C18, C19, C20 |
| 2 | 5.1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2 |
| 1 | 1.1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3 |
| 2 | 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4, R5 |
| 9 | 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6, R10, R15, R16, R17, R18, R19, R21 +1 |
| 2 | 4.7k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R7, R8 |
Vehicle movement parameters design files
The KiCad project lives in the Iverson-45/Vehicle-movement-parameters repository on GitHub; these links point at the commit this page was built from.
Vehicle movement parameters: common questions
What microcontroller does the Vehicle movement parameters use?
The Vehicle movement parameters is built around the STM32F411CEUx, from the STM32 family.
How big is the Vehicle movement parameters PCB?
The Vehicle movement parameters measures 79 × 75 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Vehicle movement parameters?
54 components, from 27 distinct parts. The full bill of materials is listed on this page.
Where can I download the Vehicle movement parameters design files?
From the Iverson-45/Vehicle-movement-parameters repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Vehicle movement parameters design in my own project?
The repository has no license, so all rights stay with Iverson-45. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Vehicle movement parameters without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
LibreVNA
jankae
122 × 98 mm592 parts6LGPL-3.01.6k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k