
Ergodonk

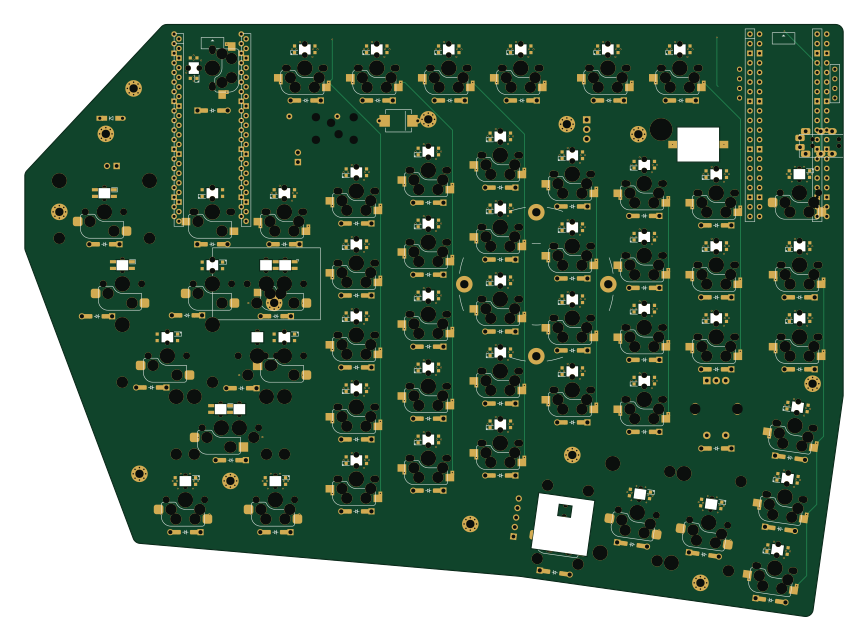
About the Ergodonk PCB
Ergodonk is an open source RP2040/RP2350 PCB design by JellyTitan, published on GitHub under the MIT license. It is a 2-layer board measuring 216.6 × 156.6 mm, with 118 components from 27 distinct parts.
Its main chip is the Pico, from the RP2040/RP2350 family. By type, the board carries 54 diodes, 53 switches, 2 connectors, 1 IC, 1 transistor and 1 jumper.
It belongs with the keyboards designs in this gallery.
From the project
ErgoDox variant using standard SA keycaps, FDM case, and blackpill MCU
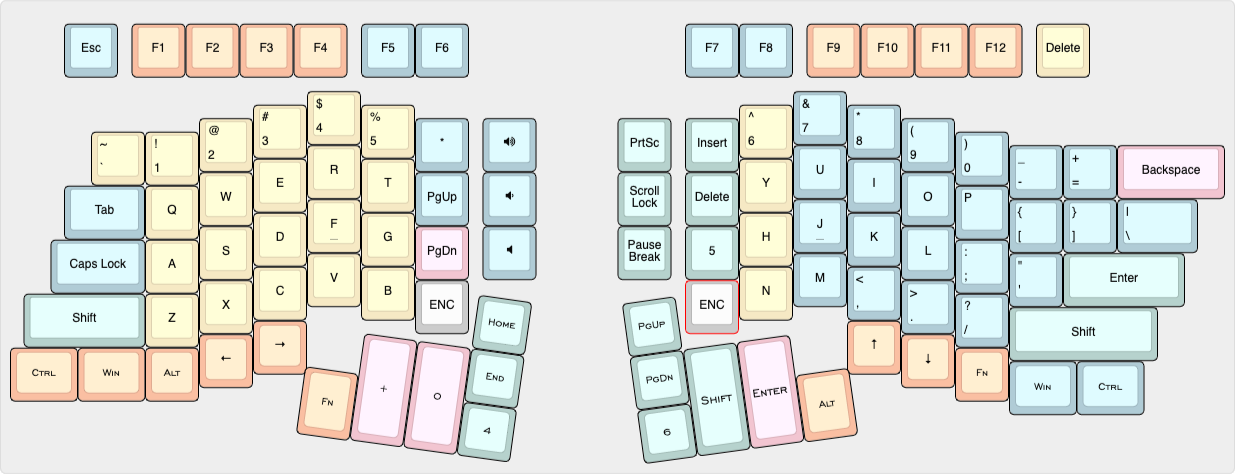
Main components on the Ergodonk
Ergodonk bill of materials (BOM)
118 components, 27 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Pico | RPi_Pico_SMD_TH_DS_Ergodonk_v1 | U11 |
| 1 | TIP120 | Tip 120 with heatsink | Q1 |
| 1 | Pimaroni Trackball | pimoroni_trackball | J10 |
| 1 | 4PIN | MJ-4PP-9_CANTOR_KITCHEN_SINK | J11 |
| 1 | MUR340S | MUR340S_IN4001_TH_HYBRID | D_SOL_1 |
| 1 | LH LED's | PinHeader_1x02_P2.54mm_Vertical | JP3 |
| 1 | Conn_01x02_Female | PinHeader_1x02_P2.54mm_Vertical | J_SOL_1 |
| 1 | AST1109MLTRQ_MAL | AST1109MLTRQ | LS10 |
| 1 | Solenoid | uxcell a14092600ux0438 solenoid | S1 |
| 38 | SW_PUSH_LED | Cherry_MX_DS_Hotswap_miniE_1U_sofle3b | SW1, SW3, SW4, SW5, SW6, SW7, SW10, SW11 +30 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE | SW2 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_2u_RH_ONLY | SW08_RH10 |
| 1 | SW_PUSH_LED | Cherry_MX_DS_Hotswap_miniE_1U_sofle3b_oneside | SW18_RH10 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_1.5u_LH_1u_RH | SW27 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_1.5u_RH_ONLY | SW28_RH10 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_1.75u_LH_1u_RH | SW37 |
| 1 | SW_PUSH_LED | V2_CherryMX_DS_Hotswap_miniE_1U_SEED_RH | SW38_RH10 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_2.25u_LH_2.75u_RH | SW47 |
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_2.25u_RH_ONLY | SW48_RH10 |
| 2 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_2u_Vertical | SW51, SW52 |
Show 7 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_1.25u_Vertical | SW53 |
| 2 | SW_PUSH_LED | V2_CherryMX_DoubleSided_Hotswap_miniE_1.25u | SW57, SW58 |
| 1 | RotaryEncoder_Switch | RotaryEncoder_EC11_ergodonk_variant | SWLH_ROT1 |
| 1 | OLED | OLED SSD1306 128x64 UNVERIFIED | OL10 |
| 53 | D | D_SOD-123_DO-35_Hybrid_DoubleSided | D1, D2, D3, D4, D5, D6, D7, D08_RH10 +45 |
| 1 | D | D3_TH_SMD_v2 | D18 |
| 1 | 1k | R_Axial_DIN0309_L9.0mm_D3.2mm_P12.70mm_Horizontal | R2 |
Ergodonk design files
The KiCad project lives in the JellyTitan/ErgoDonk repository on GitHub; these links point at the commit this page was built from.
Ergodonk: common questions
What microcontroller does the Ergodonk use?
The Ergodonk is built around the Pico, from the RP2040/RP2350 family.
How big is the Ergodonk PCB?
The Ergodonk measures 216.6 × 156.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Ergodonk?
118 components, from 27 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Ergodonk design files?
From the JellyTitan/ErgoDonk repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Ergodonk design in my own project?
Yes, under the terms of its MIT license, which JellyTitan chose for the repository.
Can I test firmware for the Ergodonk without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
More boards in ErgoDonk
 RP2040/RP2350
Ergodonk pico
15 × 15 mm326 parts2LMIT10 RP2040/RP2350
Ergodonk pico 2
15 × 15 mm326 parts2LMIT10 RP2040/RP2350
Ergodonk pico zero
9.3 × 11.3 mm221 parts2LMIT10 RP2040/RP2350
Ergodonk simple zero
216.6 × 155.6 mm146 parts2LMIT10 RP2040/RP2350
Ergodonk simple
216.6 × 155.6 mm144 parts2LMIT10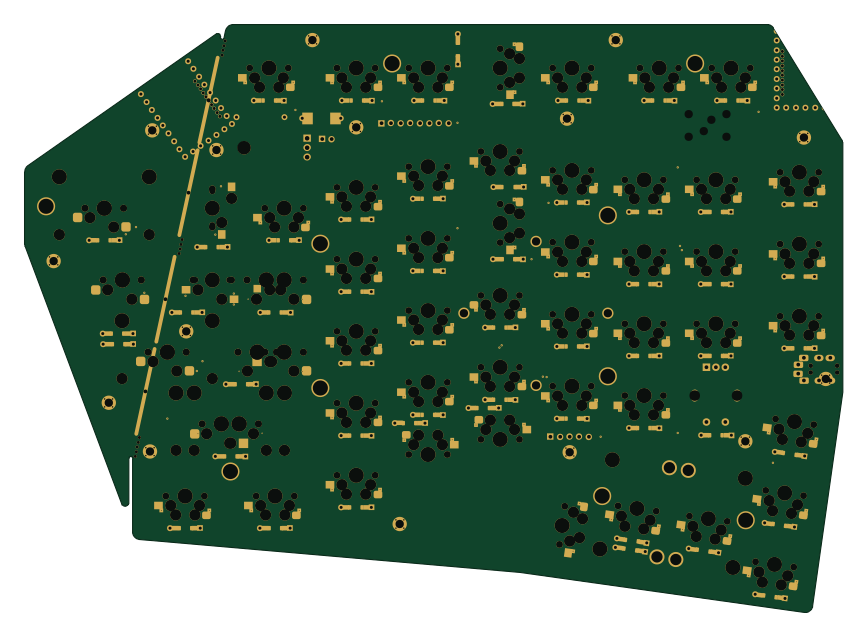 RP2040/RP2350
Ergodonk simple zero 2
216.6 × 155.6 mm143 parts2LMIT10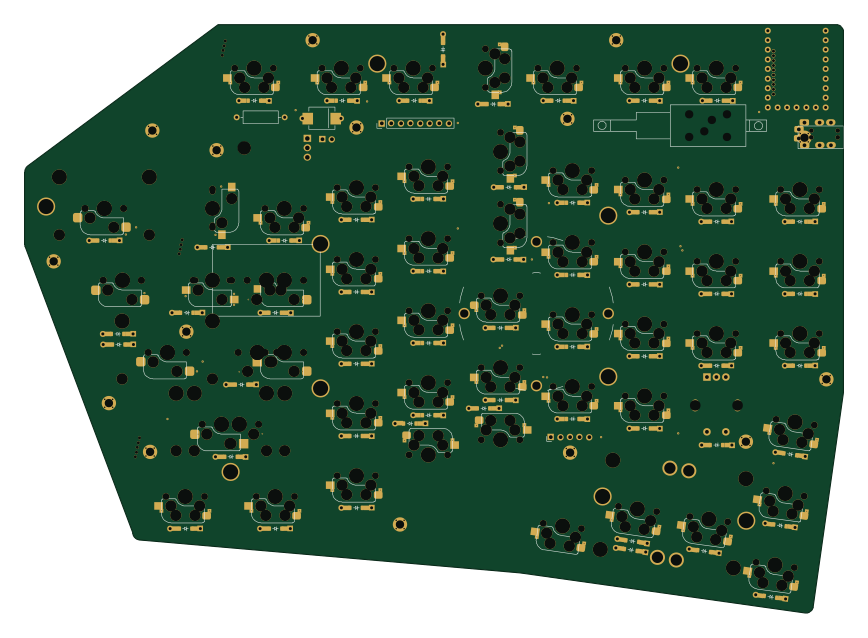 RP2040/RP2350
Ergodonk simple 0
216.6 × 155.7 mm143 parts2LMIT10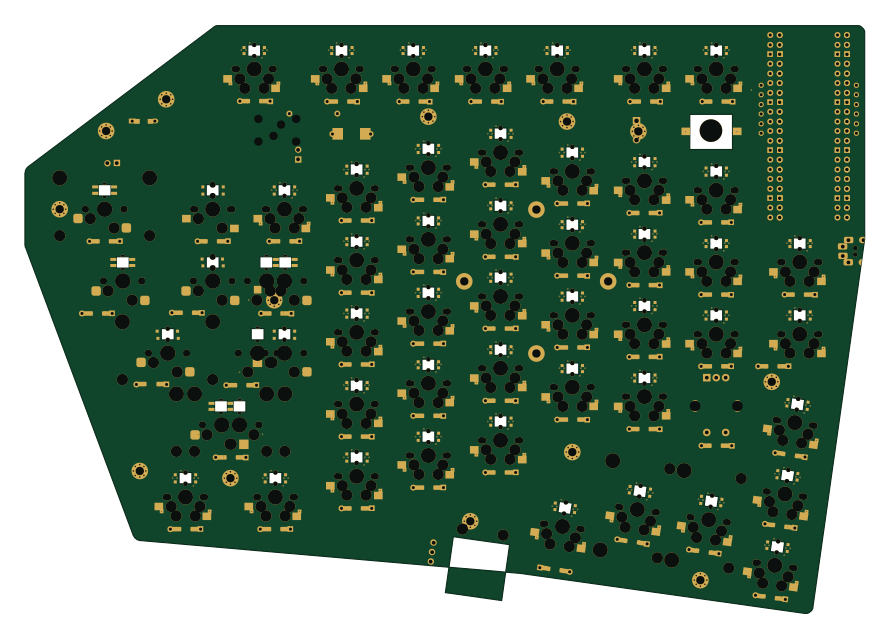 RP2040/RP2350
Ergodonk ds oled
222.3 × 155.6 mm117 parts2LMIT10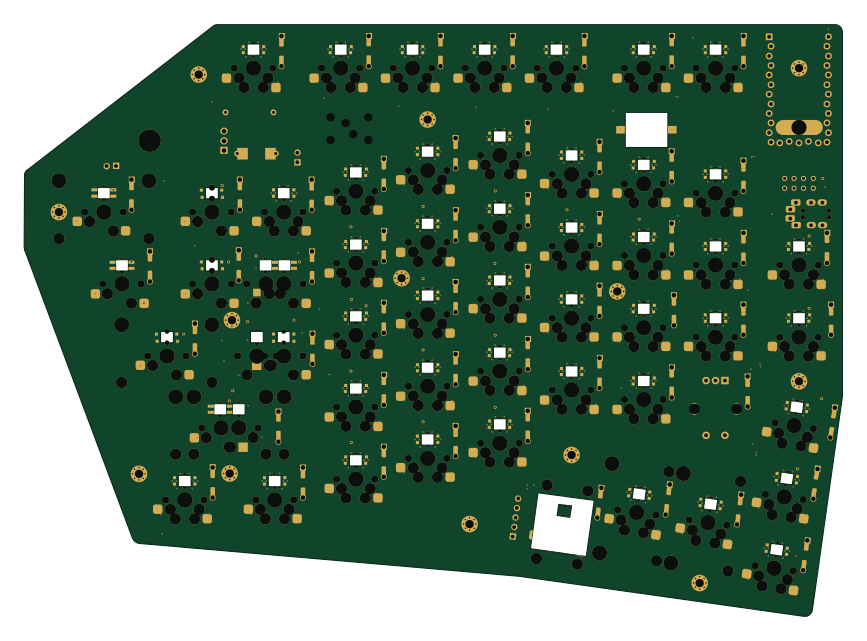
Ergodonk elite c
216.5 × 156.6 mm117 parts2LMIT10 RP2040/RP2350
Test
43 × 65 mm4 parts2LMIT10 RP2040/RP2350
Test 2
43 × 65 mm4 parts2LMIT10
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
LogicAnalyzer
gusmanb
57 × 55.2 mm6 parts2LGPL-3.05.0k RP2040/RP2350
Jitx design
55.5 × 65 mm26 parts4LGPL-3.05.0k RP2040/RP2350
Pro V2
kata0510
290.1 × 130 mm270 parts2LMIT2.3k