
ESP32-Unity-Drone-Controller

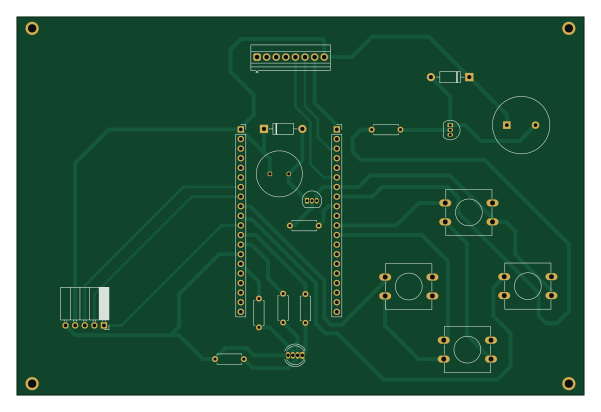
About the ESP32-Unity-Drone-Controller PCB
ESP32-Unity-Drone-Controller is an open source PCB design by jose803196, published on GitHub. It is a 2-layer board measuring 150 × 100 mm, with 21 components from 14 distinct parts.
By type, the board carries 6 resistors, 4 switches, 3 diodes, 2 transistors, 2 connectors and 1 module.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
A complete project for controlling a 3D drone in Unity using a custom physical controller based on ESP32, MPU6050, and a joystick. Includes hardware, firmware, and simulation.
DroneLink Simulator is a comprehensive hardware-in-the-loop project that bridges the gap between physical electronics and virtual simulation. The core idea is to provide an immersive and realistic control experience by flying a 3D drone in a Unity environment using a dedicated hardware controller.
This repository contains everything from the ground up: Hardware Design: Custom schematics and PCB layouts for the controller. Embedded Firmware: Robust C code for the ESP32 to read sensors and communicate data. 3D Simulation: A fully functional Unity project that receives and interprets the…
ESP32-Unity-Drone-Controller bill of materials (BOM)
21 components, 14 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Motor_DC | XDCR_PS1240P02BT | M1 |
| 2 | BC237 | TO-92_Inline | Q1, Q2 |
| 2 | Conn_01x20 | PinSocket_1x20_P2.54mm_Vertical | J2, J3 |
| 1 | Buzzer | Buzzer_15x7.5RM7.6 | BZ1 |
| 1 | Conn_01x05 | PinSocket_1x05_P2.54mm_Horizontal | Joystick1 |
| 1 | Conn_01x08 | TerminalBlock_Xinya_XY308-2.54-8P_1x08_P2.54mm_Horizontal | MPU6050 |
| 1 | Avanzar | SW_PUSH-12mm | SW1 |
| 1 | Retroceder | SW_PUSH-12mm | SW2 |
| 1 | Izquierda | SW_PUSH-12mm | SW3 |
| 1 | Derecha | SW_PUSH-12mm | SW4 |
| 1 | LED_RGBK | LED_D5.0mm-4_RGB | D1 |
| 2 | 1N4007 | D_DO-41_SOD81_P10.16mm_Horizontal | D2, D3 |
| 4 | 200 Ω | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2, R3, R6 |
| 2 | 1 kΩ | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4, R5 |
ESP32-Unity-Drone-Controller design files
The KiCad project lives in the jose803196/ESP32-Unity-Drone-Controller repository on GitHub; these links point at the commit this page was built from.
ESP32-Unity-Drone-Controller: common questions
How big is the ESP32-Unity-Drone-Controller PCB?
The ESP32-Unity-Drone-Controller measures 150 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the ESP32-Unity-Drone-Controller?
21 components, from 14 distinct parts. The full bill of materials is listed on this page.
Where can I download the ESP32-Unity-Drone-Controller design files?
From the jose803196/ESP32-Unity-Drone-Controller repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the ESP32-Unity-Drone-Controller design in my own project?
The repository has no license, so all rights stay with jose803196. Use it as a reference, and ask the author before reusing the design.
Similar boards

Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k