
Robotics-Stepper-Controller

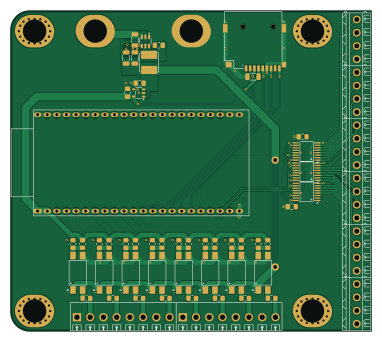
About the Robotics-Stepper-Controller PCB
Robotics-Stepper-Controller is an open source ESP32 PCB design by Jyst7, published on GitHub under the MIT license. It is a 2-layer board measuring 95.3 × 84.7 mm, with 57 components from 19 distinct parts.
Its main chip is the ESP32-S3-DevKitC, from the ESP32 family. Other key parts include the DB125-3.5-4P-GN-S, AP63205WU-7, TLP521GB-S, 74AHCT595T16-13 and DB125-3.5-8P-GN-S. By type, the board carries 24 resistors, 21 ICs, 9 capacitors, 1 transistor and 1 inductor.
It belongs with the robotics & motion and iot & wireless designs in this gallery.
From the project
Stepper motor controller board based on similar CNC controllers. The motors are connected to external motor drivers with wires connected back into the board.
This project is a motor controller board and a cycloidal gearbox. It is designed around the esp32 s3 and can handle up to 6 nema 23's using dm542's.
- ESP32 S3: allows for wifi and bluetooth connectivity aswell as allows programming using arduino ide
- up to 6 motors: allows for using up to 60 motors through the dm542 motor driver
- up to 8 inputs: allows for some electrically isolated inputs for limit switches probes, etc
Main components on the Robotics-Stepper-Controller
Robotics-Stepper-Controller bill of materials (BOM)
57 components, 19 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | DB125-3.5-4P-GN-S DB125-3.5-4P-GN DORABO(地博电气) | CONN-TH_DB125-3.5-4P-GN | U1, U2, U3, U4, U5, U6 |
| 1 | ESP32-S3-DevKitC | ESP32-S3-DevKitC | U7 |
| 1 | AP63205WU-7 DIODES(美台) | TSOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | U8 |
| 8 | TLP521GB-S TLP521GB-S_C20612587 AOTE(奥特) | SMD-4_L6.5-W4.6-P2.54-LS10.2-BL | U10, U11, U13, U15, U17, U19, U21, U22 |
| 3 | 74AHCT595T16-13 DIODES(美台) | TSSOP-16_L5.0-W4.4-P0.65-LS6.4-BL | U12, U16, U20 |
| 2 | DB125-3.5-8P-GN-S DORABO(地博电气) | CONN-TH_8P-P3.50_DORABO_DB125-3.5-8P-GN-S | U14, U18 |
| 1 | XC6220B331MR-G TOREX(特瑞仕) | SOT-25_L3.0-W1.6-P0.95-LS2.8-TL | Q1 |
| 1 | TF PUSH SHOU HAN(首韩) | TF-SMD_TF-PUSH | Card1 |
| 1 | 4.7μH | IND-SMD_L5.0-W5.0 | L1 |
| 1 | 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 1 | 10μF | C_1206_3216Metric | C2 |
| 1 | 10μF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3 |
| 2 | 22μF | C_1206_3216Metric | C4, C5 |
| 1 | 4.7μF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C6 |
| 1 | 100nF | C_1206_3216Metric | C7 |
| 2 | 0.1 μF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8, C85 |
| 8 | 300Ω | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R4, R7, R10, R13, R16, R19, R22 |
| 8 | 1K | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R5, R8, R11, R14, R17, R20, R23 |
| 8 | 10K | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3, R6, R9, R12, R15, R18, R21, R24 |
Robotics-Stepper-Controller design files
The KiCad project lives in the Jyst7/Robotics-Stepper-Controller repository on GitHub; these links point at the commit this page was built from.
Robotics-Stepper-Controller: common questions
What microcontroller does the Robotics-Stepper-Controller use?
The Robotics-Stepper-Controller is built around the ESP32-S3-DevKitC, from the ESP32 family.
How big is the Robotics-Stepper-Controller PCB?
The Robotics-Stepper-Controller measures 95.3 × 84.7 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robotics-Stepper-Controller?
57 components, from 19 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Robotics-Stepper-Controller design files?
From the Jyst7/Robotics-Stepper-Controller repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Robotics-Stepper-Controller design in my own project?
Yes, under the terms of its MIT license, which Jyst7 chose for the repository.
Can I test firmware for the Robotics-Stepper-Controller without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k