
Self balancing robot

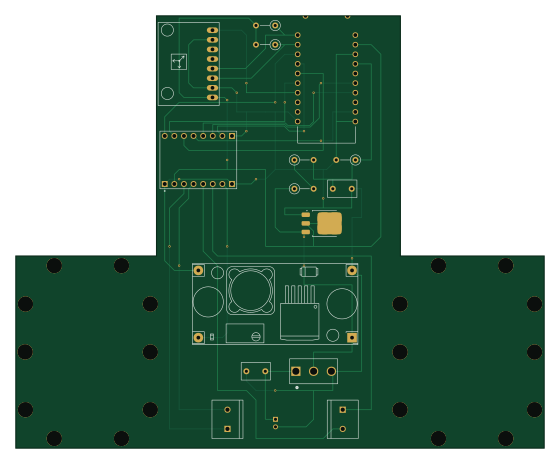
About the Self balancing robot PCB
Self balancing robot is an open source Nordic nRF PCB design by K0nradG, published on GitHub under the Apache-2.0 license. It is a 2-layer board measuring 139.7 × 114.3 mm, with 16 components from 11 distinct parts.
Its main chip is the NRF52840-DONGLE, from the Nordic nRF family. Other key parts include the LM1117DT-3.3 and YAAJ_DCDC_StepDown_LM2596. By type, the board carries 5 resistors, 3 ICs, 3 connectors, 2 capacitors and 1 switch.
It belongs with the iot & wireless, robotics & motion and sensors designs in this gallery.
From the project
Self-balancing robot powered by nRF52840 and Zephyr RTOS, with BLE control, OTA updates, and a Raspberry Pi camera interface designed for future autonomous navigation.
This project is licensed under the CERN Open Hardware Licence Version 2 - Permissive (CERN-OHL-P).
The license covers all design files in this directory, including: Electronics: KiCad schematics, PCB layouts, and libraries. Mechanics: Physical case design (Fusion 360 files in the robot-case directory).
Copyright © 2026 Dymczyk Filip and Konrad Grucel
To generate new Gerber files after making changes to the schematic, follow this guide.
Main components on the Self balancing robot
Self balancing robot bill of materials (BOM)
16 components, 11 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | NRF52840-DONGLE | MODULE_NRF52840-DONGLE | U1 |
| 1 | LM1117DT-3.3 | TO-252-3_TabPin2 | U3 |
| 1 | YAAJ_DCDC_StepDown_LM2596 | YAAJ_DCDC_StepDown_LM2596 | U4 |
| 1 | S2B-PH-K-S_LF__SN_ | JST_S2B-PH-K-S_LF__SN_ | J1 |
| 2 | 282837-2 | TE_282837-2 | P1, P2 |
| 1 | GY-521 | GY-521 | ACC1 |
| 1 | 1101M2S3CQE2 | SW_1101M2S3CQE2 | S1 |
| 1 | POLOLU-713 | SHIELD_POLOLU-713 | TB1 |
| 2 | 100uF | C_Disc_D7.5mm_W4.4mm_P5.00mm | C1, C3 |
| 3 | 100k | R_Axial_DIN0207_L6.3mm_D2.5mm_P5.08mm_Vertical | R1, R2, R3 |
| 2 | 10kR | R_Axial_DIN0207_L6.3mm_D2.5mm_P5.08mm_Vertical | R4, R5 |
Self balancing robot design files
The KiCad project lives in the K0nradG/self-balancing-robot repository on GitHub; these links point at the commit this page was built from.
- LayoutSchematic/Schematic.kicad_pcb
- SchematicSchematic/Schematic.kicad_sch
Self balancing robot: common questions
What microcontroller does the Self balancing robot use?
The Self balancing robot is built around the NRF52840-DONGLE, from the Nordic nRF family.
How big is the Self balancing robot PCB?
The Self balancing robot measures 139.7 × 114.3 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Self balancing robot?
16 components, from 11 distinct parts. The full bill of materials is listed on this page.
Where can I download the Self balancing robot design files?
From the K0nradG/self-balancing-robot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Self balancing robot design in my own project?
Yes, under the terms of its Apache-2.0 license, which K0nradG chose for the repository.
Can I test firmware for the Self balancing robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Nordic nRF firmware against it before you order a PCB.
Similar boards
 Nordic nRF
TOTEM
GEIGEIGEIST
258.8 × 94.4 mm85 parts2LCERN-OHL-P-2.02.0k Nordic nRF
Pixl.js
solosky
40 × 23 mm45 parts4LGPL-2.01.4k Nordic nRF
Board
dennisss
363 × 128 mm420 parts4LApache-2.0381 Nordic nRF
Board hl15-latest
61 × 37 mm14 parts2LApache-2.0381 Nordic nRF
Management
101 × 31.5 mm50 parts2LApache-2.0381 Nordic nRF
Mikoto
zhiayang
18 × 33.3 mm53 parts4LApache-2.0355