
19 open source boards using the YAAJ_DCDC_StepDown_LM2596
Real designs built with the YAAJ_DCDC_StepDown_LM2596, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
 Nordic nRF
Self balancing robot
K0nradG
139.7 × 114.3 mm16 parts2LApache-2.04
K PA Protec
F6ITU
102.5 × 75 mm83 parts2LNo license1
Breakout
akashihi
100 × 100 mm43 parts4LNo license1
Exoskeleton-Glove
ReeyanshShah
65 × 112.9 mm11 parts2LNo license1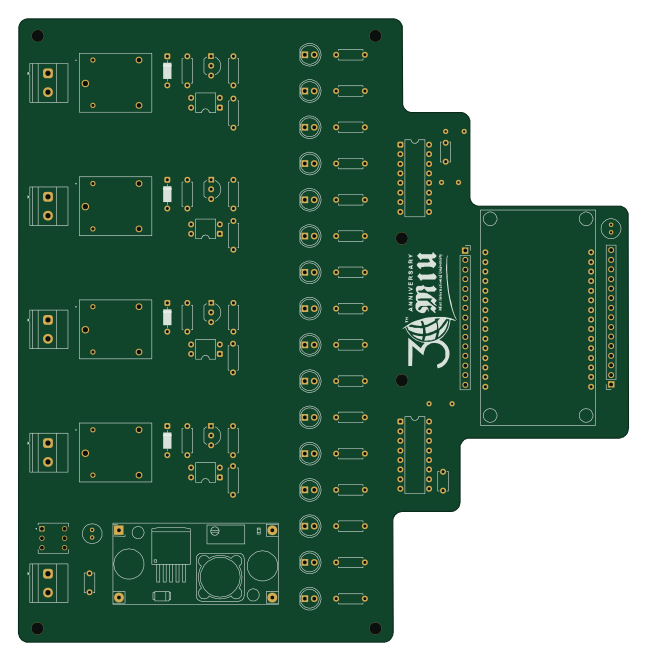 ESP8266
Light
zeyad-hisham-cyper
161.4 × 165.1 mm76 parts2LMIT0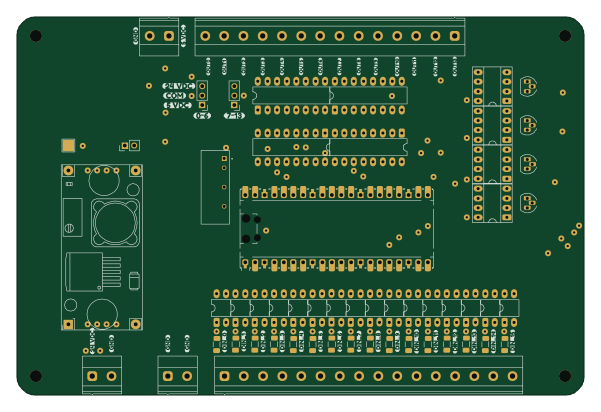 RP2040/RP2350
ALTERNANCIA PI PICO
zen451019
150 × 100 mm71 parts2LNo license0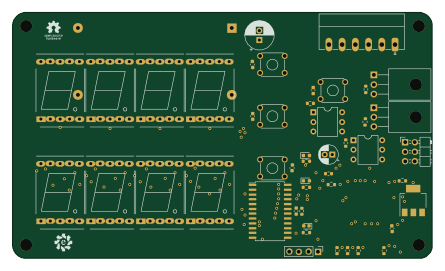 ESP32
Esp23 i3 heat thermostat
i3detroit
111 × 65 mm54 parts2LNo license0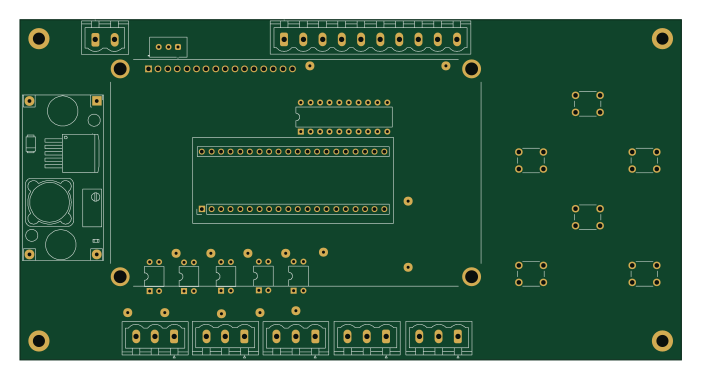
Skaner3d
DamianPodrazaCode
175 × 90 mm52 parts2LNo license0
Connect game
zdenekru
100 × 100 mm31 parts2LMIT0
H bridge dc ac inverter
envergokaycay
83.5 × 105.5 mm26 parts2LNo license0
Exoskeleton-Glove main
Prajwalnayak2506
65 × 112.9 mm11 parts2LNo license0- schematic only · 51 parts
Train-Driver-Hardware
ScottGibb
51 partsNo license0  RP2040/RP2350
Rev2
Churrosoft
95 × 77 mm194 parts4LMIT1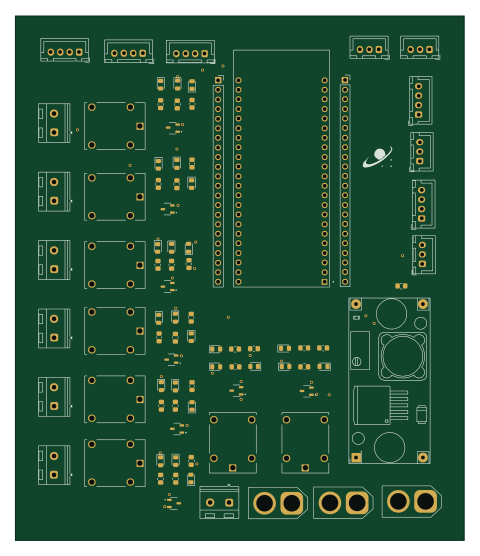 ESP32
Science updated
Sidbit08
118.7 × 138.7 mm88 parts2LNo license1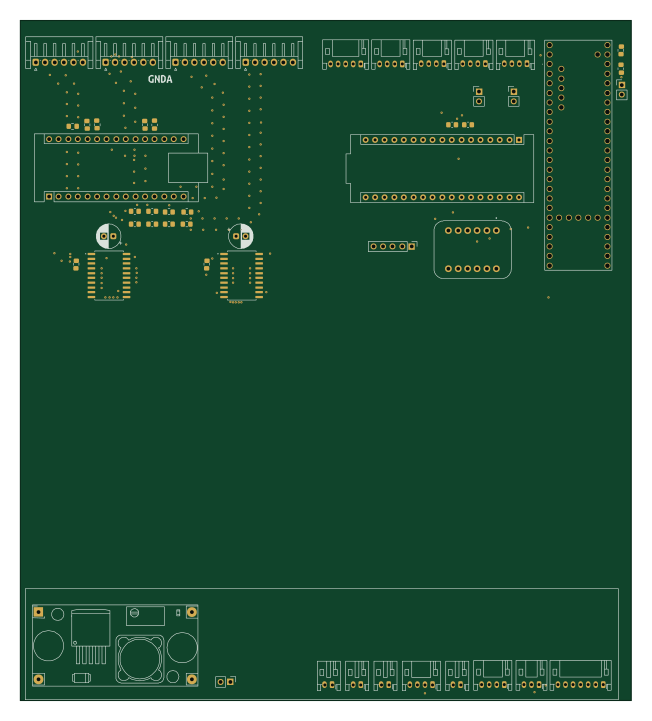 AVR/Arduino
Kicad test redo
maxsterl666
161.8 × 180 mm50 parts4LNo license0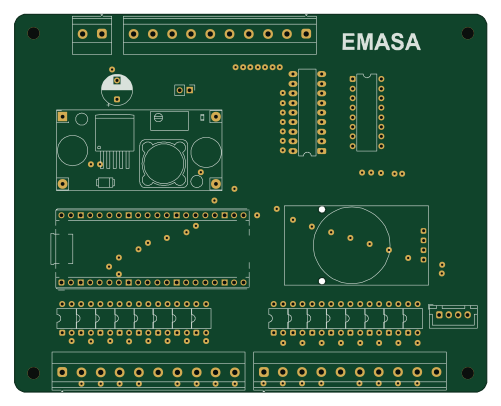 RP2040/RP2350
RTC RELAY
125 × 100 mm51 parts2LNo license0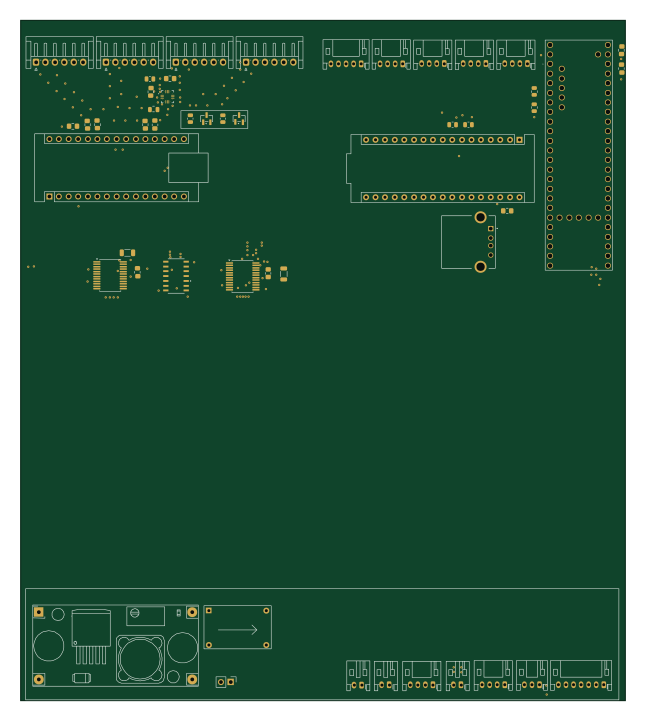
Kicad test redo w MPR121
160 × 180 mm47 parts4LNo license0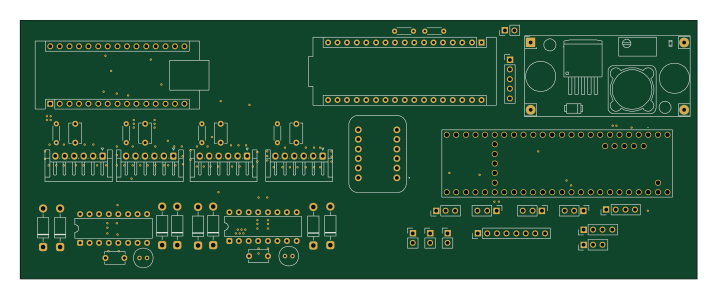 AVR/Arduino
Kicad test
179 × 68.3 mm46 parts4LNo license0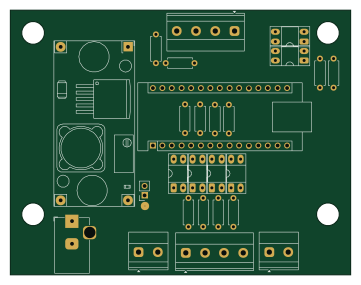 AVR/Arduino
ALTIO PWR12VDC LOG12V NEG INT
90 × 70 mm26 parts2LNo license0
How designs wire the YAAJ_DCDC_StepDown_LM2596
Read from the KiCad layouts of 14 open source designs, one per repository: what each pin of the YAAJ_DCDC_StepDown_LM2596 connects to, and the resistors, capacitors and other passives placed on it.
| Pin | Connected to | Parts on the pin |
|---|---|---|
| VINpin 1 | Connected to: 24V 64% · a signal 36% | — |
| GNDpin 2, 3 | Connected to: GND 89% | — |
1 more pin varies from design to design. Connections count pins, parts count designs; values in brackets are how many parts had that value. Designs read include Self balancing robot by K0nradG, Breakout by akashihi, Rev2 by Churrosoft and K PA Protec by F6ITU.
The YAAJ_DCDC_StepDown_LM2596 in open source designs
The gallery holds 19 open source boards using the YAAJ_DCDC_StepDown_LM2596 from 15 GitHub repositories; a typical one measures about 114.8 × 100 mm and carries around 50 components.
72% are two-layer designs, the rest use four layers or more, and 21% carry an open source license.
The most starred is Self balancing robot by K0nradG.
Parts used alongside the YAAJ_DCDC_StepDown_LM2596
Microcontrollers on boards using the YAAJ_DCDC_StepDown_LM2596
What boards using the YAAJ_DCDC_StepDown_LM2596 are built for
YAAJ_DCDC_StepDown_LM2596: common questions
Where can I find a YAAJ_DCDC_StepDown_LM2596 reference design?
Each of the 19 boards on this page is a real design using the YAAJ_DCDC_StepDown_LM2596. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
What parts are used alongside the YAAJ_DCDC_StepDown_LM2596?
The PC817, 74HC595, Arduino_Nano_v3.x, BOB-09056 and SC0918 appear in the most repositories here.
Which microcontrollers do boards using the YAAJ_DCDC_StepDown_LM2596 use?
Most are built on AVR/Arduino (3), RP2040/RP2350 (3), ESP32 (2) and ESP8266 (1).
How big is a typical board using the YAAJ_DCDC_StepDown_LM2596?
The median is 114.8 × 100 mm, and 72% are two-layer designs.
What is the most popular open source board using the YAAJ_DCDC_StepDown_LM2596?
By GitHub stars, Self balancing robot by K0nradG, with 4 stars.
Can I simulate one of these boards using the YAAJ_DCDC_StepDown_LM2596 before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.