
STM32-Sumo-Robot-Controller

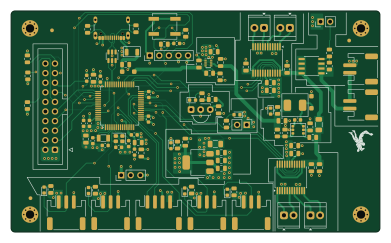
About the STM32-Sumo-Robot-Controller PCB
STM32-Sumo-Robot-Controller is an open source STM32 PCB design by keer-nova74, published on GitHub. It is a 4-layer board measuring 97.7 × 58.5 mm, with 93 components from 43 distinct parts.
Its main chip is the STM32L476RGT6, from the STM32 family. Other key parts include the USBLC6-2SC6, RT8259, AMS1117-3.3, TPS2116DRL and TB6612FNG. By type, the board carries 36 capacitors, 23 resistors, 10 diodes, 8 connectors, 7 ICs and 3 fuses.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
A robotics controller PCB project using an STM32 microcontroller, dual motor drivers, sensor interfaces, and power management, designed using KiCad.
This project focuses on designing a custom Printed Circuit Board (PCB) for an autonomous sumo robot using KiCad. The controller is intended to integrate a microcontroller, motor drivers, sensor interfaces, and power management into a compact robotics hardware platform.
- STM32 microcontroller interface for robot control - Dual DC motor driver circuit - Infrared sensor interfaces for opponent and boundary detection - Battery power input and distribution - Voltage regulation for logic and peripheral circuits - Motor and sensor connectors - Programming and debugging interface - Compact PCB…
Main components on the STM32-Sumo-Robot-Controller
STM32-Sumo-Robot-Controller bill of materials (BOM)
93 components, 43 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | USBLC6-2SC6 | SOT-23-6 | U1 |
| 1 | STM32L476RGT6 | LQFP-64_10x10mm_P0.5mm | U2 |
| 1 | RT8259 | RT8259GE_RT8259GE SOT-23-6 Surface Mount | U3 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U4 |
| 1 | TPS2116DRL | SOT-583-8 | U5 |
| 2 | TB6612FNG | SSOP-24_5.3x8.2mm_P0.65mm | U7, U8 |
| 1 | FDS6681Z | FDS6681Z_Footprint | Q1 |
| 1 | 32KHZ768 32KHz768 | Crystal_SMD_3215-2Pin_3.2x1.5mm | X1 |
| 1 | 16MHZ 16MHz | Crystal_SMD_2520-4Pin_2.5x2.0mm | X2 |
| 1 | BATT1_CONN | JST_PH_S2B-PH-SM4-TB_1x02-1MP_P2.00mm_Horizontal | J1 |
| 1 | USB_C_RECEPTACLE_USB2.0_16P USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J2 |
| 1 | BATT2_CONN | JST_PH_S2B-PH-SM4-TB_1x02-1MP_P2.00mm_Horizontal | J3 |
| 1 | URM09_CONN | JST_PH_S4B-PH-SM4-TB_1x04-1MP_P2.00mm_Horizontal | J7 |
| 1 | C265101 LD_FRONT_LEFT_CONN | JST_PH_S3B-PH-SM4-TB_1x03-1MP_P2.00mm_Horizontal | J10 |
| 1 | C265101 LD_FRONT_RIGHT_CONN | JST_PH_S3B-PH-SM4-TB_1x03-1MP_P2.00mm_Horizontal | J11 |
| 1 | C265101 LD_BACK_LEFT_CONN | JST_PH_S3B-PH-SM4-TB_1x03-1MP_P2.00mm_Horizontal | J12 |
| 1 | C265101 LD_BACK_RIGHT_CONN | JST_PH_S3B-PH-SM4-TB_1x03-1MP_P2.00mm_Horizontal | J13 |
| 2 | 750MA 750mA | Fuse_1206_3216Metric | F1, F2 |
| 1 | 1206L110TH1 | 1206L110THYR_SMT | F3 |
| 1 | SW_Push | SW_SPST_B3SL-1002P | SW2 |
Show 23 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | B5819W | B5819W SOD123 | D1, D2 |
| 7 | C2286 RED_LED | LED_0603_1608Metric | D3, D4, D6, D7, D8, D9, D10 |
| 1 | C2290 WHITE_LED | LED_0603_1608Metric | D5 |
| 1 | 120R | L_0603_1608Metric | FB1 |
| 1 | 6.8UH 6.8uH | MWSA0518S-6R8MT | L1 |
| 4 | 1u | C_0805_2012Metric | C1, C2, C4, C27 |
| 7 | 100N 100n | C_0603_1608Metric | C3, C6, C7, C8, C9, C12, C13 |
| 2 | 10N 10n | C_0603_1608Metric | C5, C21 |
| 2 | 8.2P 8.2p | C_0603_1608Metric | C10, C11 |
| 2 | 15P 15p | C_0603_1608Metric | C14, C15 |
| 1 | 4U7 4u7 | C_0805_2012Metric | C16 |
| 8 | 10U 10u | C_0805_2012Metric | C17, C19, C22, C26, C30, C31, C34, C35 |
| 3 | 22U 22u | C_0805_2012Metric | C18, C24, C25 |
| 7 | 0.1U 0.1u | C_0805_2012Metric | C20, C23, C28, C29, C32, C33, C36 |
| 2 | 100K 100k | R_0805_2012Metric | R1, R10 |
| 6 | 10K | R_0805_2012Metric | R2, R5, R6, R7, R8, R12 |
| 2 | 5K1 | R_0805_2012Metric | R3, R4 |
| 3 | 220R | R_0805_2012Metric | R9, R17, R18 |
| 1 | 33K | R_0805_2012Metric | R11 |
| 1 | 62K 62k | R_0805_2012Metric | R13 |
| 1 | 12K 12k | R_0805_2012Metric | R14 |
| 2 | 1K | R_0805_2012Metric | R15, R16 |
| 5 | 470R | R_0805_2012Metric | R19, R20, R21, R22, R23 |
STM32-Sumo-Robot-Controller design files
The KiCad project lives in the keer-nova74/STM32-Sumo-Robot-Controller-PCB repository on GitHub; these links point at the commit this page was built from.
- Layoutsumobot pcb.kicad_pcb
- Schematicsumobot pcb.kicad_sch
- BOMtsumo_bot_bom_2025-12-25.csv
STM32-Sumo-Robot-Controller: common questions
What microcontroller does the STM32-Sumo-Robot-Controller use?
The STM32-Sumo-Robot-Controller is built around the STM32L476RGT6, from the STM32 family.
How big is the STM32-Sumo-Robot-Controller PCB?
The STM32-Sumo-Robot-Controller measures 97.7 × 58.5 mm, has 4 copper layers and is 1.5842 mm thick.
How many components are on the STM32-Sumo-Robot-Controller?
93 components, from 43 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the STM32-Sumo-Robot-Controller design files?
From the keer-nova74/STM32-Sumo-Robot-Controller-PCB repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the STM32-Sumo-Robot-Controller design in my own project?
The repository has no license, so all rights stay with keer-nova74. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the STM32-Sumo-Robot-Controller without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k