
Kevinbot p2 board

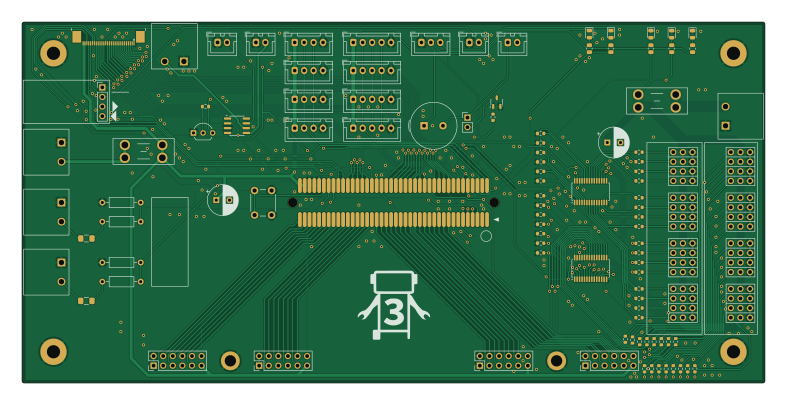
About the Kevinbot p2 board
Kevinbot p2 board is an open source PCB design by Kevinbot-Robotics, published on GitHub under the CERN-OHL-S-2.0 license. It is a 2-layer board measuring 196.5 × 95.4 mm, with 110 components from 34 distinct parts.
Other key parts include the 450-00309, DS18B20+, PCA9685PW and TC4427ACOA713. By type, the board carries 56 resistors, 33 connectors, 5 ICs, 5 diodes, 4 fuses and 2 test points.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
Parallax Propeller 2 Edge robot control system with 32 servo ports
Thanks to PCBWay for providing high-quality PCB prototypes.
I would recommend them for any of your PCB needs. They offer fast turnaround and shipping.
Main components on the Kevinbot p2 board
Kevinbot p2 board bill of materials (BOM)
110 components, 34 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 450-00309 P2_EDGE_MODULE_SOCKET | Card_Edge_SMT_VERT_1.27mm_80p | U1 |
| 1 | DS18B20+ DS18B20 | TO-92_Inline_Wide | U2 |
| 2 | PCA9685PW | TSSOP-28_4.4x9.7mm_P0.65mm | U3, U5 |
| 1 | TC4427ACOA713 TC4427 | SOIC-8_3.9x4.9mm_P1.27mm | U4 |
| 1 | FDN337N | SOT-23-3 | Q2 |
| 5 | 1757242 Screw_Terminal_01x02 | MSTBA-2,5-2-G-5,08 | J1, J3, J4, J5, J9 |
| 1 | B3B-XH-A Conn_01x03_Male | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J2 |
| 4 | G800W590018EU Conn_02x06_Odd_Even | PinHeader_2x06_P2.54mm_Vertical | J6, J8, J12, J16 |
| 4 | B4B-XH-A Conn_01x04 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J7, J10, J13, J15 |
| 1 | 10129379-904002BLF Conn_01x04_Male | PinHeader_1x04_P2.54mm_Vertical | J11 |
| 4 | B2B-XH-A Conn_01x02 | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J14, J21, J31, J32 |
| 8 | N/A Conn_04x03_Servo | ServoHeader_04_P2.54_Vertical | J17, J18, J19, J20, J26, J27, J28, J29 |
| 4 | B5B-XH-A Conn_01x05 | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J22, J23, J24, J25 |
| 1 | G800W306018EU Conn_01x02_Pin | PinHeader_1x02_P2.54mm_Vertical | J30 |
| 1 | Conn_02x14_Odd_Even | TE_2-1734839-8_1x28-1MP_P0.5mm_Horizontal | J33 |
| 1 | PS1240P02BT Buzzer | Buzzer_TDK_PS1240P02BT_D12.2mm_H6.5mm | BZ1 |
| 2 | 3568 Fuse | Fuseholder_Blade_Mini_Keystone_3568 | F1, F4 |
| 2 | 0ZCJ0016FF2E Polyfuse_Small | Fuse_1206_3216Metric_Pad1.42x1.75mm_HandSolder | F2, F3 |
| 1 | 1825910-6 SW_Push | SW_PUSH_6mm | SW1 |
| 2 | TestPoint_Probe | Keystone-1502-2 | TP1, TP2 |
Show 14 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | 150080SS75000 LED | LED_0805_2012Metric | D1, D2, D3, D4 |
| 1 | 150080BS75000 LED | LED_0805_2012Metric | D5 |
| 1 | A758KR477M1AAAE011 470uf | CP_Radial_D8.0mm_P3.50mm | C1 |
| 1 | A750KS158M0JAAE014 1500uf | CP_Radial_D8.0mm_P3.50mm | C2 |
| 1 | RC0805FR-07330RL 330R | R_0805_2012Metric | R1 |
| 2 | RC0805FR-07140RL 140R | R_0805_2012Metric | R2, R24 |
| 1 | RC0805FR-07430RL 430R | R_0805_2012Metric | R3 |
| 2 | YR1B100KCC 100K | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R4, R6 |
| 2 | YR1B10KCC 10K | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5, R7 |
| 1 | RC0603FR-074K7L 4K7 | R_0603_1608Metric | R8 |
| 13 | RC0603FR-0710KL 10K | R_0603_1608Metric | R9, R10, R11, R12, R13, R14, R15, R17 +5 |
| 1 | RC0603FR-07680RL 680R | R_0603_1608Metric | R23 |
| 1 | RC0603FR-0733RL 33R | R_0805_2012Metric | R25 |
| 32 | RC0603FR-07220RL 220R | R_0603_1608Metric | R27, R28, R29, R30, R31, R32, R33, R34 +24 |
Kevinbot p2 board design files
The KiCad project lives in the Kevinbot-Robotics/kevinbot_p2_board repository on GitHub; these links point at the commit this page was built from.
- LayoutP2 Kevinbot Board.kicad_pcb
- SchematicP2 Kevinbot Board.kicad_sch
Kevinbot p2 board: common questions
How big is the Kevinbot p2 board?
The Kevinbot p2 board measures 196.5 × 95.4 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Kevinbot p2 board?
110 components, from 34 distinct parts. The full bill of materials is listed on this page.
Where can I download the Kevinbot p2 board design files?
From the Kevinbot-Robotics/kevinbot_p2_board repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Kevinbot p2 board design in my own project?
Yes, under the terms of its CERN-OHL-S-2.0 license, which Kevinbot-Robotics chose for the repository.
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Breakout 60pin EEC-IV
rusefi
139.7 × 62.2 mm15 parts2LGPL-3.01.2k
134pin 7-967288-1
139.7 × 73.7 mm38 parts2LGPL-3.01.2k
Breakout 112pin Connector
174 × 58 mm39 parts2LGPL-3.01.2k
Eecv breakout
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
88 Pin Vag Breakout
142 × 58 mm91 parts2LGPL-3.01.2k