
Roamer bot

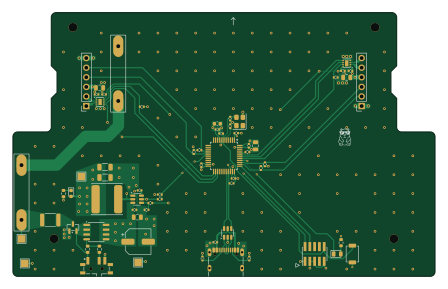
About the Roamer bot PCB
Roamer bot is an open source STM32 PCB design by kylestew, published on GitHub. It is a 4-layer board measuring 111.8 × 69.8 mm, with 61 components from 35 distinct parts.
Its main chip is the STM32F103CBT6, from the STM32 family. Other key parts include the USBLC6-2SC6, DRV8838 and LMR51430XDDCR. By type, the board carries 23 capacitors, 18 resistors, 5 ICs, 4 connectors, 2 transistors and 2 battery holders.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
A small SLAM capable robot built on the Pololu Romi chassis
Status: Rev A was ordered from JLCPCB on 2026-07-18 and is in production; fabrication and bring-up verification remain.
This is the single source of truth for the custom Romi motor-controller hardware. If this document disagrees with the KiCad design, the schematic, PCB, and generated BOM are authoritative and this document must be corrected.
Rev A replaces the Pololu Romi controller for the minimum useful rover loop:
Main components on the Roamer bot
Roamer bot bill of materials (BOM)
61 components, 35 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F103CBT6 | LQFP-48_7x7mm_P0.5mm | U1 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U2 |
| 2 | DRV8838 | WSON-8-1EP_2x2mm_P0.5mm_EP0.9x1.6mm | U3, U4 |
| 1 | LMR51430XDDCR | SOT-23-6 | U5 |
| 1 | AO3401A | SOT-23 | Q1 |
| 1 | AO4407A | AO4407A_SO-8_GSD | Q2 |
| 1 | 16MHZ 16Mhz | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | CONN_ARM_JTAG_SWD_10 Conn_ARM_JTAG_SWD_10 | PinHeader_2x05_P1.27mm_Vertical_SMD | J1 |
| 1 | USB_C_RECEPTACLE_USB2.0_16P USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_G-Switch_GT-USB-7010ASV | J2 |
| 1 | CONN_MOTOR_R | PinSocket_1x06_P2.54mm_Vertical | J3 |
| 1 | CONN_MOTOR_L | PinSocket_1x06_P2.54mm_Vertical | J4 |
| 1 | BATT (4xAA) | Romi_Chassis_BatteryContactPair_2Slot_14_50mm | BT1 |
| 1 | BATT (2xAA) | Romi_Chassis_BatteryContactPair_2Slot_14_50mm | BT2 |
| 1 | PTC_2.6A_16V | Fuse_1812_4532Metric | F1 |
| 1 | SW_Push | SW_SPST_TS-1088-xR020 | SW1 |
| 1 | SK-3296S-01-L2 | SW_SPDT_RightAngle_XKB_SK-3296S-01-L2 | SW2 |
| 1 | PWR_ON_LED | LED_0603_1608Metric | D1 |
| 1 | STATUS | LED_0805_2012Metric | D2 |
| 1 | 5.6U 5.6u | L_APV_ANR8065 | L1 |
| 2 | 10P 10p | C_0402_1005Metric | C1, C2 |
Show 15 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 12 | 100N 100n | C_0402_1005Metric | C3, C4, C5, C6, C7, C9, C11, C12 +4 |
| 4 | 10U 10u | C_0805_2012Metric | C8, C10, C13, C17 |
| 1 | 220U 220u | CP_Elec_6.3x7.7 | C16 |
| 2 | 22U 22u | C_1206_3216Metric | C20, C21 |
| 1 | 10N 10n | C_0402_1005Metric | C22 |
| 1 | 1u | C_0603_1608Metric | C23 |
| 1 | 0603WAF1002T5E 10k UNI-ROYAL | R_0402_1005Metric | R1 |
| 1 | 1K5 1k5 | R_0402_1005Metric | R5 |
| 2 | 5K1 5k1 | R_0402_1005Metric | R6, R7 |
| 4 | 10K 10k | R_0402_1005Metric | R10, R11, R14, R15 |
| 4 | 100K 100k | R_0402_1005Metric | R12, R13, R16, R18 |
| 1 | 33K 33k | R_0402_1005Metric | R17 |
| 1 | 22.1K 22.1k | R_0402_1005Metric | R19 |
| 3 | 1k | R_0603_1608Metric | R20, R21, R23 |
| 1 | 100K 100k | R_0603_1608Metric | R22 |
Roamer bot design files
The KiCad project lives in the kylestew/roamer-bot repository on GitHub; these links point at the commit this page was built from.
Roamer bot: common questions
What microcontroller does the Roamer bot use?
The Roamer bot is built around the STM32F103CBT6, from the STM32 family.
How big is the Roamer bot PCB?
The Roamer bot measures 111.8 × 69.8 mm, has 4 copper layers and is 1.59 mm thick.
How many components are on the Roamer bot?
61 components, from 35 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Roamer bot design files?
From the kylestew/roamer-bot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Roamer bot design in my own project?
The repository has no license, so all rights stay with kylestew. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Roamer bot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k