
AirHockeyRobot

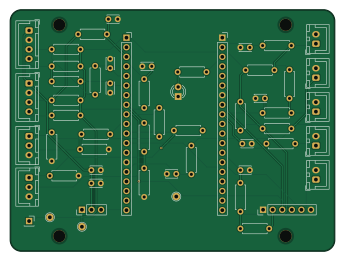
About the AirHockeyRobot PCB
AirHockeyRobot is an open source ESP32 PCB design by Lew-Alex, published on GitHub. It is a 2-layer board measuring 86 × 64 mm, with 50 components from 22 distinct parts.
Its main chip is the ESP32 DevKitC L, from the ESP32 family. By type, the board carries 13 connectors, 1 jumper and 1 diode.
It belongs with the dev boards & breakouts and robotics & motion designs in this gallery.
From the project
A robotic air-hockey table. A camera tracks the puck, a policy trained in simulation decides where the mallet should go, and an ESP32 drives two brushed DC motors through off-board motor drivers.
A robotic air-hockey table. A camera tracks the puck, a policy trained in simulation decides where the mallet should go, and an ESP32 drives two brushed DC motors through off-board motor drivers.
This is a personal project in progress. The status table below separates what exists in this repository from what is only planned.
The Mac is meant to run perception and the trained policy. The ESP32 handles the low-level motor interface through the breakout PCB. See docs/architecture.md.
AirHockeyRobot bill of materials (BOM)
50 components, 22 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32 DevKitC L | PinSocket_1x19_P2.54mm_Vertical | J1 |
| 1 | ESP32 DevKitC R | PinSocket_1x19_P2.54mm_Vertical | J2 |
| 1 | ENC1 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J3 |
| 1 | ENC2 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J4 |
| 1 | MOTOR1 | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J5 |
| 1 | MOTOR2 | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J6 |
| 1 | LIM1 | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J7 |
| 1 | LIM2 | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J8 |
| 1 | LIM3 | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J9 |
| 1 | LIM4 | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J10 |
| 1 | ESTOP | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J11 |
| 1 | C37208 SPARE | PinHeader_1x06_P2.54mm_Vertical | J12 |
| 1 | DRV_5V | PinSocket_1x01_P2.54mm_Vertical | J13 |
| 4 | 100nF | C_Disc_D3.0mm_W2.0mm_P2.50mm | CD_LIM1, CD_LIM2, CD_LIM3, CD_LIM4 |
| 2 | 100NF 100nF | C_Disc_D3.0mm_W2.0mm_P2.50mm | CE1, CE2 |
| 4 | 330pF | C_Disc_D3.0mm_W2.0mm_P2.50mm | CF_E1A, CF_E1B, CF_E2A, CF_E2B |
| 1 | C49257 ENC_VCC | PinHeader_1x03_P2.54mm_Vertical | JP1 |
| 9 | 1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | RF_E1A, RF_E1B, RF_E2A, RF_E2B, RL1, RS_LIM1, RS_LIM2, RS_LIM3 +1 |
| 8 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | RP_DIR1, RP_DIR2, RP_PWM1, RP_PWM2, RU_LIM1, RU_LIM2, RU_LIM3, RU_LIM4 |
| 4 | 220 | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | RS_DIR1, RS_DIR2, RS_PWM1, RS_PWM2 |
Show 2 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | 4.7k | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | RU_E1A, RU_E1B, RU_E2A, RU_E2B |
| 1 | GREEN | LED_D3.0mm | D1 |
AirHockeyRobot design files
The KiCad project lives in the Lew-Alex/AirHockeyRobot repository on GitHub; these links point at the commit this page was built from.
AirHockeyRobot: common questions
What microcontroller does the AirHockeyRobot use?
The AirHockeyRobot is built around the ESP32 DevKitC L, from the ESP32 family.
How big is the AirHockeyRobot PCB?
The AirHockeyRobot measures 86 × 64 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the AirHockeyRobot?
50 components, from 22 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the AirHockeyRobot design files?
From the Lew-Alex/AirHockeyRobot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the AirHockeyRobot design in my own project?
The repository has no license, so all rights stay with Lew-Alex. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the AirHockeyRobot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k