
Robot hexapode

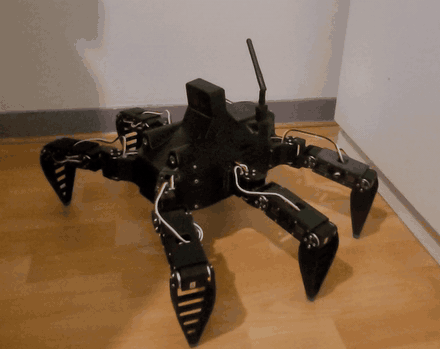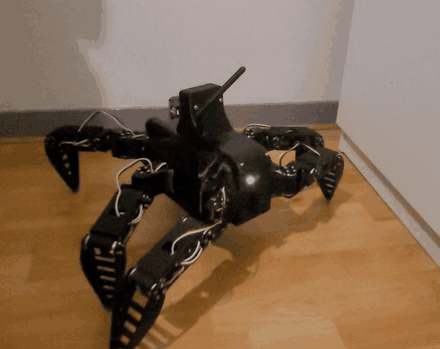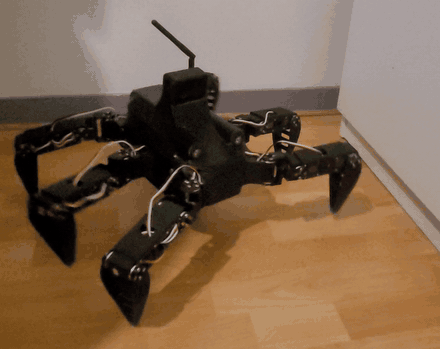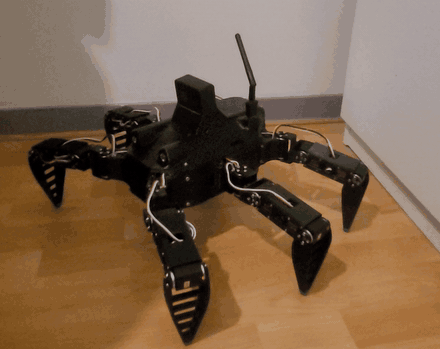
About the Robot hexapode PCB
Robot hexapode is an open source Raspberry Pi PCB design by lucas-minaberry, published on GitHub under the Custom license license. It is a board, with 50 components from 37 distinct parts.
Its main chip is the Raspberry Pi 5, from the Raspberry Pi family. Other key parts include the Buck 12V-5V 10A, Digispark, ADS1115 (0x48), FE-URT-2 and PT4115. By type, the board carries 12 resistors, 9 connectors, 9 capacitors, 8 ICs, 5 diodes and 4 transistors.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
Antares, robot hexapode à 18 degrés de liberté : conception mécanique, électronique, logiciel embarqué ROS 2 et essais
Robot marcheur à six pattes et 18 degrés de liberté, conçu comme base d'un robot de secours en zone difficile. Conçu, fabriqué et programmé par Lucas Minaberry, élève ingénieur en mécatronique à l'ESILV (depuis juin 2026).
1. Cahier des charges et dimensionnement : couples articulaires, longueurs des segments, bilan de masse, choix des actionneurs. 2. Conception mécanique : CAO SolidWorks, conception orientée fabrication et assemblage, choix des matériaux. 3. Électronique : distribution de puissance, commutation des 18 servomoteurs, mesure de la batterie, séquences de marche et d'arrêt…
Main components on the Robot hexapode
Robot hexapode bill of materials (BOM)
50 components, 37 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Buck 12V-5V 10A | U1 | |
| 1 | Digispark | U2 | |
| 1 | Raspberry Pi 5 | U3 | |
| 1 | ADS1115 (0x48) | U4 | |
| 1 | FE-URT-2 | U5 | |
| 1 | PT4115 | U6 | |
| 1 | ReSpeaker 2-Mics | U7 | |
| 1 | Pi 5 : ports USB | U8 | |
| 2 | IRF4905 | TO-220-3_Vertical | Q1, Q3 |
| 2 | 2N2222 | TO-92_Inline | Q2, Q4 |
| 1 | USB-C Pi 5 | J1 | |
| 1 | Patte 1 | J2 | |
| 1 | Patte 2 | J3 | |
| 1 | Patte 3 | J4 | |
| 1 | Patte 4 | J5 | |
| 1 | Patte 5 | J6 | |
| 1 | Patte 6 | J7 | |
| 1 | OAK-D SR (IMU BNO086) | J8 | |
| 1 | Clé WiFi USB | J9 | |
| 1 | LiPo 3S 5200mAh | BT1 |
Show 17 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 30A | F1 | |
| 1 | ON/OFF | SW1 | |
| 2 | 1.5KE18A | D_DO-201AE_P15.24mm_Horizontal | D1, D2 |
| 1 | LED RGB | D3 | |
| 2 | LED 1W | D4, D5 | |
| 7 | 1000uF | C1, C4, C5, C6, C7, C8, C9 | |
| 1 | 1uF | C2 | |
| 1 | 10uF | C3 | |
| 1 | 100k | R1 | |
| 1 | 22k | R2 | |
| 2 | 10k | R3, R5 | |
| 3 | 1k | R4, R6, R9 | |
| 1 | 47k | R7 | |
| 1 | 4.7k | R8 | |
| 1 | 120R | R10 | |
| 1 | 10R | R11 | |
| 1 | 47R | R12 |
Robot hexapode design files
The KiCad project lives in the lucas-minaberry/robot-hexapode repository on GitHub; these links point at the commit this page was built from.
- Schematicelectronique/antares.kicad_sch
Robot hexapode: common questions
What microcontroller does the Robot hexapode use?
The Robot hexapode is built around the Raspberry Pi 5, from the Raspberry Pi family.
How many components are on the Robot hexapode?
50 components, from 37 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot hexapode design files?
From the lucas-minaberry/robot-hexapode repository on GitHub, which has the schematic; the links under Design files point to each one.
Can I use the Robot hexapode design in my own project?
It is published under Custom license, which limits how it may be reused; read the license before building on it.
Can I test firmware for the Robot hexapode without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
Similar boards
 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k Raspberry Pi
Iot
dotnet
56 × 65 mm24 parts2LMIT2.4k Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license672 Raspberry Pi
Phased
Neumi
75 × 100 mm71 parts2LNo license507