
MotionControl

About the MotionControl PCB
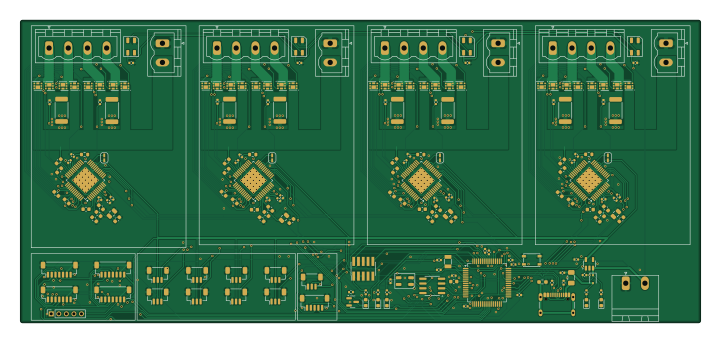
MotionControl is an open source Microchip SAM PCB design by meowmeowahr, published on GitHub. It is a 2-layer board measuring 180 × 80 mm, with 191 components from 46 distinct parts.
Its main chip is the ATSAMD21J18A-A, from the Microchip SAM family. Other key parts include the AP2112K-3.3, TMC5160A-TA and TC4427. By type, the board carries 68 capacitors, 37 resistors, 33 transistors, 26 connectors, 11 diodes and 7 ICs.
It belongs with the robotics & motion designs in this gallery.
From the project
Multi-purpose SAMD21-based stepper controller and extras
Main components on the MotionControl
MotionControl bill of materials (BOM)
191 components, 46 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ATSAMD21J18A-A | TQFP-64_10x10mm_P0.5mm | U1 |
| 1 | AP2112K-3.3 | SOT-23-5 | U2 |
| 4 | TMC5160A-TA | TQFP-48-1EP_7x7mm_P0.5mm_EP5x5mm_ThermalVias_0.3 | U3, U4, U5, U6 |
| 1 | TC4427 | SOIC-8_3.9x4.9mm_P1.27mm | U7 |
| 1 | 2N7002 | SOT-23 | Q1 |
| 32 | Q_NMOS_DGS | Diodes_DMT6016LFDF | Q2, Q3, Q4, Q5, Q6, Q7, Q8, Q9 +24 |
| 1 | 32.768kHz | Crystal_SMD_3215-2Pin_3.2x1.5mm | Y1 |
| 1 | 1757242 Screw_Terminal_01x02 | PhoenixContact_MSTBA_2,5_2-G-5,08_1x02_P5.08mm_Horizontal | J1 |
| 1 | Conn_ARM_JTAG_SWD_10 | PinHeader_2x05_P1.27mm_Vertical_SMD | J2 |
| 4 | Screw_Terminal_01x04 | PhoenixContact_MSTBVA_2,5_4-G-5,08_1x04_P5.08mm_Vertical | J3, J5, J6, J7 |
| 4 | Conn_01x07_MountingPin | JST_SH_BM07B-SRSS-TB_1x07-1MP_P1.00mm_Vertical | J4, J12, J13, J14 |
| 4 | Screw_Terminal_01x02 | PhoenixContact_MSTBVA_2,5_2-G-5,08_1x02_P5.08mm_Vertical | J8, J9, J10, J11 |
| 1 | Conn_01x05_Pin | PinSocket_1x05_P2.00mm_Vertical | J15 |
| 9 | Conn_01x03_MountingPin | JST_SH_BM03B-SRSS-TB_1x03-1MP_P1.00mm_Vertical | J16, J17, J19, J20, J22, J23, J25, J26 +1 |
| 1 | Conn_01x04_MountingPin | JST_SH_BM05B-SRSS-TB_1x05-1MP_P1.00mm_Vertical | J28 |
| 1 | USB_C_Plug_USB2.0 | USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | P1 |
| 1 | 500mA | Fuse_1206_3216Metric | F1 |
| 1 | Jumper_2_Bridged | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | JP1 |
| 4 | Jumper_2 | SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | JP2, JP7, JP10, JP13 |
| 1 | SW_Push | SW_SPST_PTS810 | SW1 |
Show 26 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | LED | LED_0603_1608Metric | D1, D2 |
| 1 | CUS10S30 | D_SOD-323 | D3 |
| 1 | Blue | LED_0603_1608Metric | D4 |
| 1 | Green | LED_0603_1608Metric | D5 |
| 1 | Yellow | LED_0603_1608Metric | D6 |
| 5 | WS2812B-2020 | LED_WS2812B-Mini_PLCC4_3.5x3.5mm | D7, D8, D9, D10, D11 |
| 1 | 220R | L_0603_1608Metric | FB1 |
| 2 | 2.2uF | C_0402_1005Metric | C1, C3 |
| 2 | 1uF | C_0402_1005Metric | C2, C11 |
| 2 | 15pF | C_0402_1005Metric | C4, C5 |
| 10 | 0.1uF | C_0402_1005Metric | C6, C7, C8, C9, C10, C21, C35, C49 +2 |
| 4 | 10uF 50V | C_0805_2012Metric | C12, C26, C40, C54 |
| 4 | 22nF 50V | C_0402_1005Metric | C13, C27, C41, C55 |
| 32 | 100nF 50V | C_0603_1608Metric | C14, C15, C19, C20, C22, C23, C24, C25 +24 |
| 4 | 470nF 10V | C_0402_1005Metric | C16, C30, C44, C58 |
| 4 | 4.7uF 6.3V | C_0402_1005Metric | C17, C31, C45, C59 |
| 4 | 2.2uF 25V | C_0603_1608Metric | C18, C32, C46, C60 |
| 1 | 10K | R_0402_1005Metric | R1 |
| 1 | 10R | R_0402_1005Metric | R2 |
| 2 | 5.1K | R_0402_1005Metric | R3, R4 |
| 1 | 100K | R_0402_1005Metric | R5 |
| 2 | 300R | R_0402_1005Metric | R6, R7 |
| 2 | 165R | R_0402_1005Metric | R8, R9 |
| 4 | 2R | R_0603_1608Metric | R10, R17, R24, R31 |
| 16 | 47R | R_0402_1005Metric | R11, R12, R14, R15, R18, R19, R21, R22 +8 |
| 8 | 50mR | R_2512_6332Metric | R13, R16, R20, R23, R27, R30, R34, R37 |
MotionControl design files
The KiCad project lives in the meowmeowahr/KevinbotV3-MotionControlHardware repository on GitHub; these links point at the commit this page was built from.
- LayoutMotionControl.kicad_pcb
- SchematicMotionControl.kicad_sch
MotionControl: common questions
What microcontroller does the MotionControl use?
The MotionControl is built around the ATSAMD21J18A-A, from the Microchip SAM family.
How big is the MotionControl PCB?
The MotionControl measures 180 × 80 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the MotionControl?
191 components, from 46 distinct parts. The full bill of materials is listed on this page.
Where can I download the MotionControl design files?
From the meowmeowahr/KevinbotV3-MotionControlHardware repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the MotionControl design in my own project?
The repository has no license, so all rights stay with meowmeowahr. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the MotionControl without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Microchip SAM firmware against it before you order a PCB.
More boards in KevinbotV3-MotionControlHardware
Similar boards
 Microchip SAM
Fpgaboy
Wren6991
50 × 50 mm89 parts4LNo license508 Microchip SAM
Kira
kiibohd
366.9 × 114.3 mm400 partsCERN-OHL-1.2415 Microchip SAM
DSKY driver
benkrasnow
43 × 92.3 mm44 partsMIT258 Microchip SAM
Duet 2 Maestro
Duet3D
100 × 123 mm336 partsCERN-OHL-1.2257 Microchip SAM
Makennbot
idlehandsdev
60 × 75 mm53 parts2LNo license175 Microchip SAM
Oxidized flash
blakesmith
61 × 21.6 mm19 parts2LNo license167