
Bench robotics controller 5eab0a5d

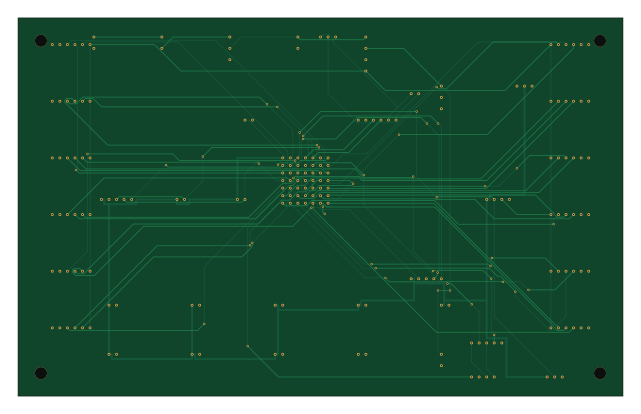
About the Bench robotics controller 5eab0a5d PCB
Bench robotics controller 5eab0a5d is an open source STM32 PCB design by mrcha033, published on GitHub under the Apache-2.0 license. It is a 4-layer board measuring 160 × 100 mm, with 42 components from 34 distinct parts.
Its main chip is the STM32H743VIT6, from the STM32 family. Other key parts include the ICM-42688-P, TPS26630RGET, LM76005RNPR, TPS62133RGTR and TCAN1042HGVDRQ1. By type, the board carries 17 connectors, 10 capacitors, 6 ICs, 4 resistors, 2 transistors and 2 diodes.
It belongs with the robotics & motion and wearables designs in this gallery.
From the project
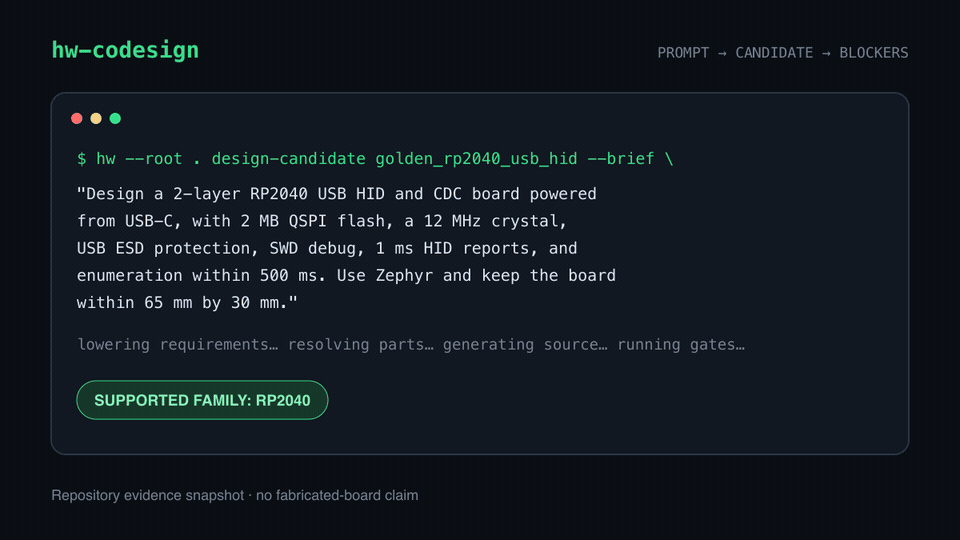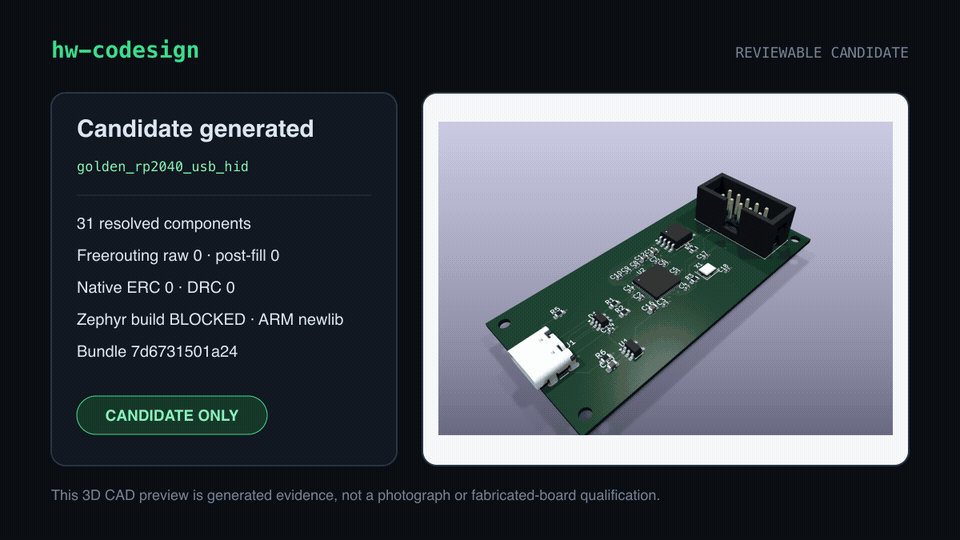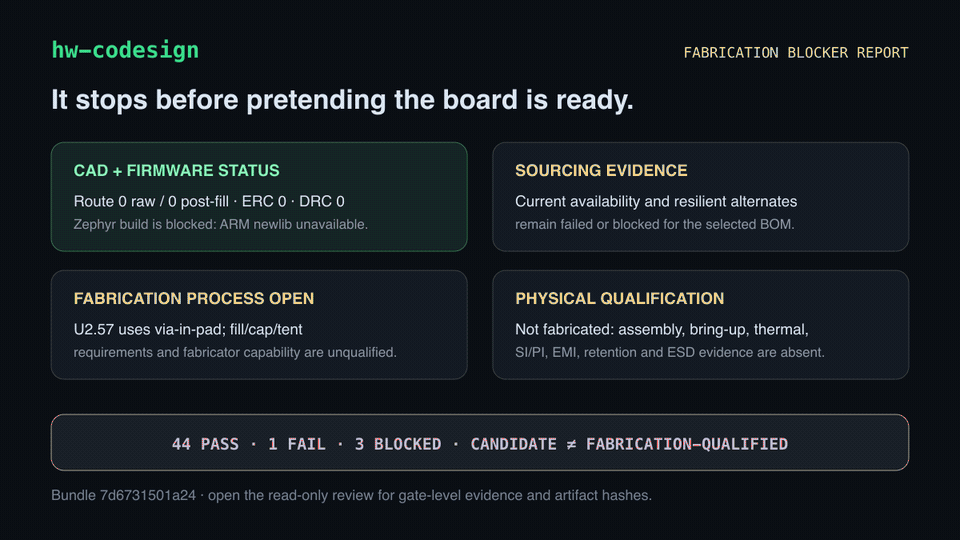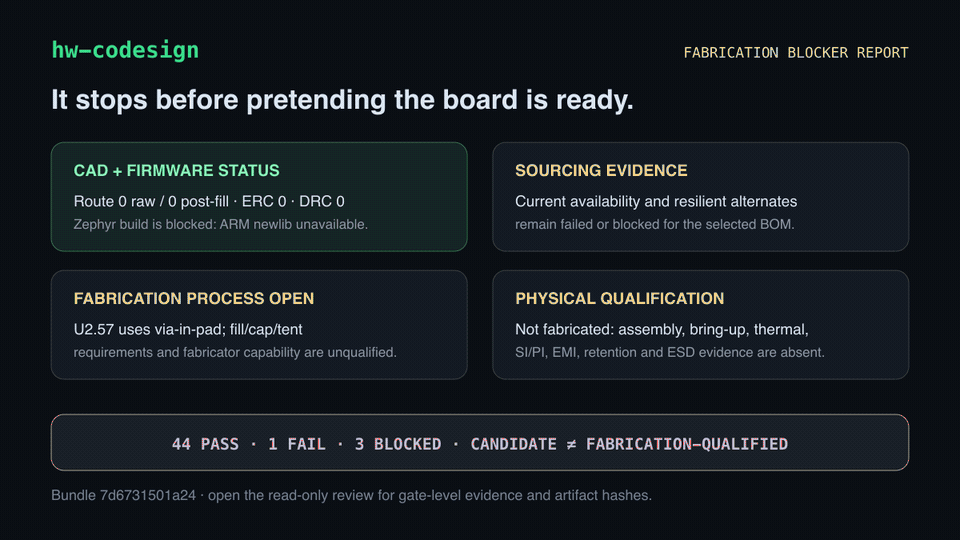
Agentic hardware co-design: brief to KiCad, firmware, 3D review, and explicit fabrication blockers.
Give an AI agent a hardware brief. Get KiCad, firmware, a 3D assembly, and an explicit fabrication-blocker report.
Agentic hardware co-design from brief to KiCad, firmware, 3D review, and explicit fabrication blockers. For 13 supported board families, hw-codesign turns a prompt into a reviewable candidate while keeping missing sourcing, toolchain, manufacturing, and physical evidence visible instead of silently treating it as success.
Main components on the Bench robotics controller 5eab0a5d
Bench robotics controller 5eab0a5d bill of materials (BOM)
42 components, 34 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32H743VIT6 STM32H743 STMicroelectronics | LQFP-100_14x14mm_P0.5mm | U1 |
| 1 | ICM-42688-P TDK InvenSense | LGA-14 | U2 |
| 1 | TPS26630RGET eFuse Texas Instruments | VQFN-24-1EP | U3 |
| 1 | LM76005RNPR 5V Buck Texas Instruments | WQFN-30 | U4 |
| 1 | TPS62133RGTR 3V3 Buck Texas Instruments | VQFN-16 | U5 |
| 1 | TCAN1042HGVDRQ1 CAN PHY Texas Instruments | SOIC-8_3.9x4.9mm_P1.27mm | U6 |
| 1 | LM74700QDBVRQ1 IDEAL DIODE Texas Instruments | SOT-23-6 | Q1 |
| 1 | SN74LVC1G97DBVR E-STOP GATE Texas Instruments | SOT-23-6 | Q2 |
| 1 | Molex-42820-2212 24V INPUT Molex | MicroFit_2Pin | J1 |
| 1 | Phoenix-1935161 E-STOP Phoenix Contact | Phoenix_3Pin | J2 |
| 1 | Molex-43650-0300 CAN Molex | MicroFit_3Pin | J3 |
| 1 | Samtec-FTSH-105-01-L-DV-K SWD Samtec | FTSH-105 | J4 |
| 1 | USB4105-GF-A USB-C GCT | USB_C_GCT_USB4105 | J5 |
| 1 | Molex-43045-0800 MOTOR_IO_1 Molex | MicroFit_8Pin | J11 |
| 1 | Molex-43045-0800 MOTOR_IO_2 Molex | MicroFit_8Pin | J12 |
| 1 | Molex-43045-0800 MOTOR_IO_3 Molex | MicroFit_8Pin | J13 |
| 1 | Molex-43045-0800 MOTOR_IO_4 Molex | MicroFit_8Pin | J14 |
| 1 | Molex-43045-0800 MOTOR_IO_5 Molex | MicroFit_8Pin | J15 |
| 1 | Molex-43045-0800 MOTOR_IO_6 Molex | MicroFit_8Pin | J16 |
| 1 | Molex-43045-0800 MOTOR_IO_7 Molex | MicroFit_8Pin | J17 |
Show 14 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Molex-43045-0800 MOTOR_IO_8 Molex | MicroFit_8Pin | J18 |
| 1 | Molex-43045-0800 MOTOR_IO_9 Molex | MicroFit_8Pin | J19 |
| 1 | Molex-43045-0800 MOTOR_IO_10 Molex | MicroFit_8Pin | J20 |
| 1 | Molex-43045-0800 MOTOR_IO_11 Molex | MicroFit_8Pin | J21 |
| 1 | Molex-43045-0800 MOTOR_IO_12 Molex | MicroFit_8Pin | J22 |
| 1 | Littelfuse-0498080.M 80A SERVICE FUSE Littelfuse | MIDI_Fuse | F1 |
| 1 | SMCJ33A 33V TVS Littelfuse | D_SMC | D1 |
| 1 | USBLC6-2SC6 USB ESD STMicroelectronics | SOT-23-6 | D2 |
| 8 | GRM188R71C104KA01D 100nF Murata | C_0603_1608Metric | C1, C2, C3, C4, C5, C6, C7, C8 |
| 1 | GRM31CR61E226ME15L 22uF Murata | C_1206_3216Metric | C9 |
| 1 | GRM32ER71H106KA12L 10uF 50V Murata | C_1210_3225Metric | C10 |
| 1 | RC0603FR-07120RL 120R Yageo | R_0603_1608Metric | R1 |
| 2 | RC0603FR-074K7L 4K7 Yageo | R_0603_1608Metric | R2, R3 |
| 1 | RC0603FR-07100KL 100K Yageo | R_0603_1608Metric | R4 |
Bench robotics controller 5eab0a5d design files
The KiCad project lives in the mrcha033/hw-codesign repository on GitHub; these links point at the commit this page was built from.
- Layoutprojects/bench_robotics_controller_5eab0a5d/electronics/generated/kicad/bench_robotics_controller_5eab0a5d.kicad_pcb
- Schematicprojects/bench_robotics_controller_5eab0a5d/electronics/generated/kicad/bench_robotics_controller_5eab0a5d.kicad_sch
- BOMprojects/bench_robotics_controller_5eab0a5d/electronics/generated/bom.csv
Bench robotics controller 5eab0a5d: common questions
What microcontroller does the Bench robotics controller 5eab0a5d use?
The Bench robotics controller 5eab0a5d is built around the STM32H743VIT6, from the STM32 family.
How big is the Bench robotics controller 5eab0a5d PCB?
The Bench robotics controller 5eab0a5d measures 160 × 100 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Bench robotics controller 5eab0a5d?
42 components, from 34 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Bench robotics controller 5eab0a5d design files?
From the mrcha033/hw-codesign repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Bench robotics controller 5eab0a5d design in my own project?
Yes, under the terms of its Apache-2.0 license, which mrcha033 chose for the repository.
Can I test firmware for the Bench robotics controller 5eab0a5d without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in hw-codesign
 STM32
Bench robotics controller b204035a
160 × 100 mm42 parts4LApache-2.02 STM32
Quadruped robot controller
160 × 100 mm42 parts4LApache-2.02 Microchip SAM
Mini biped robot
50 × 30 mm32 parts2LApache-2.02 RP2040/RP2350
Golden rp2040 usb hid
65 × 30 mm31 parts2LApache-2.02 Nordic nRF
Bench ble lipo sensor b204035a
50 × 35 mm19 parts2LApache-2.02 Nordic nRF
Bench ble lipo sensor 5eab0a5d
50 × 35 mm19 parts2LApache-2.02 ESP32
Sensor data logger
70 × 50 mm16 parts2LApache-2.02 ESP32
Bench sensor logger usb 5eab0a5d
70 × 50 mm14 parts2LApache-2.02 ESP32
Bench sensor logger usb b204035a
70 × 50 mm14 parts2LApache-2.02 RP2040/RP2350
Bench rp2040 usb hid 5eab0a5d
51 × 21 mm11 parts2LApache-2.02 RP2040/RP2350
Bench rp2040 usb hid b204035a
51 × 21 mm11 parts2LApache-2.02
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
Module 16S
stuartpittaway
71.1 × 89.6 mm113 parts4LCC-BY-NC-4.01.1k STM32
Djinn
tzarc
192.3 × 150.5 mm216 parts2LCERN-OHL-S-2.0988