
Main board

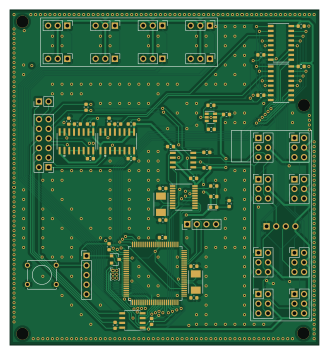
About the Main board
Main board is an open source AVR/Arduino PCB design by MST-Robotics, published on GitHub. It is a 2-layer board measuring 81.6 × 88.6 mm, with 67 components from 42 distinct parts.
Its main chip is the ATmega2560-16AU | Main Proc, from the AVR/Arduino family. Other key parts include the MCP2515-EST, ATA6560, MC14051B, MAX490E and LTC1983ES6-5-TRPBF. By type, the board carries 22 connectors, 20 capacitors, 11 resistors, 9 ICs, 2 crystals and 2 diodes.
From the project
This repository holds the electrical schematics and board layouts for the ROV (TITAN II) being built by the Missouri University of Science and Technology Underwater Robotics Design Team.
Main components on the Main board
Main board bill of materials (BOM)
67 components, 42 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MCP2515-EST | TSSOP-20_4.4x6.5mm_P0.65mm | U1 |
| 1 | ATA6560 | SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | ATmega2560-16AU | Main Proc | TQFP-100_14x14mm_P0.5mm | U3 |
| 2 | MC14051B | SOIC-16_3.9x9.9mm_P1.27mm | U4, U5 |
| 1 | MAX490E | SOIC-8_3.9x4.9mm_P1.27mm | U6 |
| 1 | LTC1983ES6-5-TRPBF | SOT-23-6 | U7 |
| 2 | MAX4449ESE+ | MAX4449ESE&plus_ | U8, U10 |
| 2 | 20MHz | Crystal_SMD_Abracon_ABM7-2Pin_6.0x3.5mm | Y1, Y2 |
| 1 | MOTOR0 | PinHeader_1x03_P2.54mm_Vertical | J1 |
| 1 | MOTOR1 | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | MOTOR2 | PinHeader_1x03_P2.54mm_Vertical | J3 |
| 1 | MOTOR3 | PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | TETHER INTERFACE | PinHeader_2x06_P2.54mm_Vertical | J5 |
| 1 | MOTOR4 | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | MOTOR5 | PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | MOTOR6 | PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | MOTOR7 | PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | PROGRAMMER | PinHeader_1x05_P2.54mm_Vertical | J10 |
| 1 | CAM0 | PinHeader_2x03_P2.54mm_Vertical | J11 |
| 1 | CAM1 | PinHeader_2x03_P2.54mm_Vertical | J12 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | CAM2 | PinHeader_2x03_P2.54mm_Vertical | J13 |
| 1 | CAM3 | PinHeader_2x03_P2.54mm_Vertical | J14 |
| 1 | CAM4 | PinHeader_2x03_P2.54mm_Vertical | J15 |
| 1 | CAM5 | PinHeader_2x03_P2.54mm_Vertical | J16 |
| 1 | CAM6 | PinHeader_2x03_P2.54mm_Vertical | J17 |
| 1 | CAM7 | PinHeader_2x03_P2.54mm_Vertical | J18 |
| 1 | PowerBoard Interface | PinSocket_1x04_P2.54mm_Vertical | J19 |
| 1 | IMU Breakout | PinHeader_1x04_P2.54mm_Vertical | J20 |
| 1 | ICSP (DO NOT POPULATE) | PinHeader_2x03_P1.00mm_Vertical | J21 |
| 1 | PLAN (US)B PINS | PinHeader_1x02_P2.54mm_Vertical | J22 |
| 1 | SW_SPST | SW_Tactile_Straight_KSA0Axx1LFTR | SW1 |
| 1 | D_Small | D_0603_1608Metric | D1 |
| 1 | D_x2_KCom_AAK | SOT-23 | D3 |
| 2 | 15p | C_0603_1608Metric | C1, C2 |
| 2 | 22pF | C_0603_1608Metric | C3, C4 |
| 2 | 1uF | C_0603_1608Metric | C5, C9 |
| 13 | 100nF | C_0603_1608Metric | C6, C7, C10, C11, C12, C13, C14, C15 +5 |
| 1 | 10uF | C_0603_1608Metric | C8 |
| 3 | 100k | R_0603_1608Metric | R2, R3, R4 |
| 2 | 120 | R_0603_1608Metric | R5, R8 |
| 2 | 10k | R_0603_1608Metric | R6, R7 |
| 4 | 75 | R_0603_1608Metric | R15, R16, R17, R18 |
Main board design files
The KiCad project lives in the MST-Robotics/TITAN-Electrical repository on GitHub; these links point at the commit this page was built from.
Main board: common questions
What microcontroller does the Main board use?
The Main board is built around the ATmega2560-16AU | Main Proc, from the AVR/Arduino family.
How big is the Main board?
The Main board measures 81.6 × 88.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Main board?
67 components, from 42 distinct parts. The full bill of materials is listed on this page.
Where can I download the Main board design files?
From the MST-Robotics/TITAN-Electrical repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Main board design in my own project?
The repository has no license, so all rights stay with MST-Robotics. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Main board without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
More boards in TITAN-Electrical
 AVR/Arduino
Power board
171.8 × 117.7 mm80 parts2LNo license0
Control station board
68.6 × 43.8 mm41 parts2LNo license0 AVR/Arduino
ProofOfConceptBoardV1
86 × 45.2 mm40 parts2LNo license0 AVR/Arduino
Module tester board
69.1 × 53.3 mm29 parts2LNo license0 AVR/Arduino
Gimble Goblin
44.5 × 36.6 mm28 parts2LNo license0
ProgrammerBoard
27.4 × 25.4 mm11 parts2LNo license0
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
ModuleV450
stuartpittaway
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
V4
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k