
6-DOF-Robotics-Arm-Dynamixel

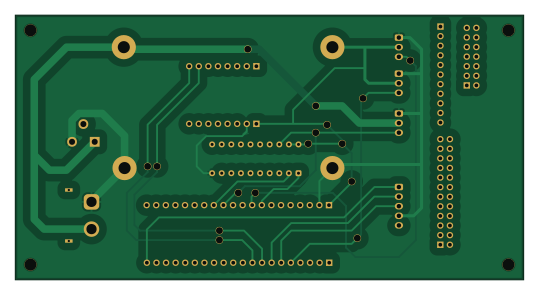
About the 6-DOF-Robotics-Arm-Dynamixel PCB
6-DOF-Robotics-Arm-Dynamixel is an open source ESP32 PCB design by Ramahabir, published on GitHub under the MIT license. It is a 2-layer board measuring 134.5 × 70 mm, with 13 components from 13 distinct parts.
Its main chip is the ESP32 C3 SUPERMINI, from the ESP32 family. Other key parts include the 74LS241. By type, the board carries 11 connectors and 2 ICs.
It belongs with the robotics & motion, iot & wireless and usb & debug tools designs in this gallery.
From the project
Open-source 6-DOF robot arm controller using STM32F411, Dynamixel servos, custom KiCad PCB, PWM gripper control, data logging, and planned ESP32-C3 wireless communication.
Firmware for a 6-degree-of-freedom robot arm based on an STM32F411CEU6 (Black Pill). The controller is designed to operate four Dynamixel joints over a half-duplex serial bus and two conventional PWM servos for the end effector.
The project uses STM32Cube HAL with PlatformIO and is uploaded/debugged through ST-Link.
- 4 × Dynamixel joints — controlled through USART2 using Dynamixel Protocol 1.0 - 1 × wrist/gripper rotation servo — PWM output on PA8 - 1 × gripper servo — PWM output on PA6 - USB-to-TTL data logger — connected through USART1 - ESP32-C3 Super Mini — planned wireless interface…
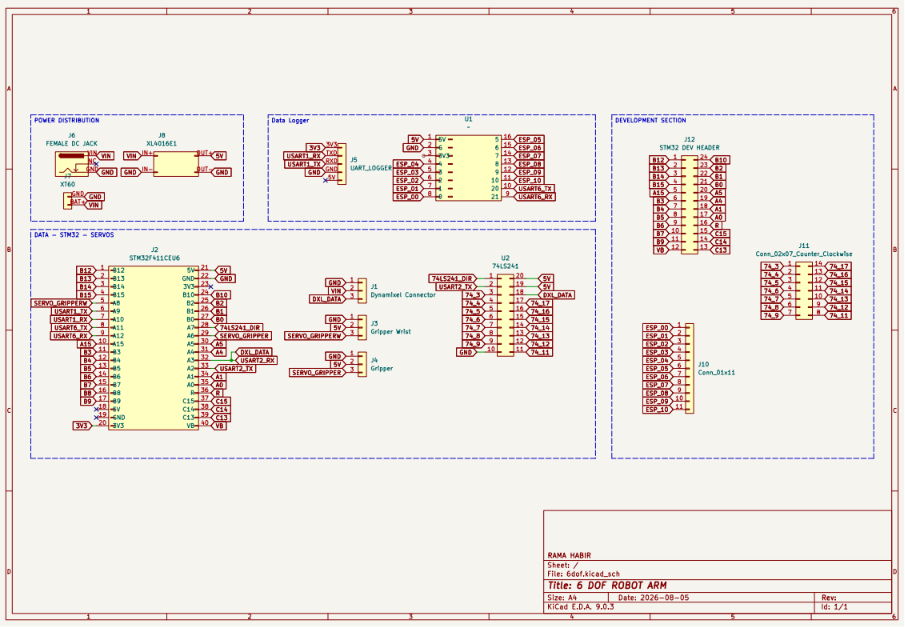
Main components on the 6-DOF-Robotics-Arm-Dynamixel
6-DOF-Robotics-Arm-Dynamixel bill of materials (BOM)
13 components, 13 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ~ | ESP32 C3 SUPERMINI | U1 |
| 1 | 74LS241 | DIP-20_W7.62mm | U2 |
| 1 | Dynamixel Connector | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J1 |
| 1 | STM32F411CEU6 | STM32F411CEU6 | J2 |
| 1 | Gripper Wrist | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J3 |
| 1 | Gripper | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J4 |
| 1 | UART_LOGGER | Molex_KK-254_AE-6410-05A_1x05_P2.54mm_Vertical | J5 |
| 1 | FEMALE DC JACK | BarrelJack_CUI_PJ-102AH_Horizontal | J6 |
| 1 | XT60 | AMASS_XT60PW-M_1x02_P7.20mm_Horizontal | J7 |
| 1 | XL4016E1 | XL4016E1 | J8 |
| 1 | Conn_01x11 | PinHeader_1x11_P2.54mm_Vertical | J10 |
| 1 | Conn_02x07_Counter_Clockwise | PinHeader_2x07_P2.54mm_Vertical | J11 |
| 1 | STM32 DEV HEADER | PinHeader_2x12_P2.54mm_Vertical | J12 |
6-DOF-Robotics-Arm-Dynamixel design files
The KiCad project lives in the Ramahabir/6-DOF-Robotics-Arm-Dynamixel repository on GitHub; these links point at the commit this page was built from.
- Layoutpcb/6dof.kicad_pcb
- Schematicpcb/6dof.kicad_sch
6-DOF-Robotics-Arm-Dynamixel: common questions
What microcontroller does the 6-DOF-Robotics-Arm-Dynamixel use?
The 6-DOF-Robotics-Arm-Dynamixel is built around the ESP32 C3 SUPERMINI, from the ESP32 family.
How big is the 6-DOF-Robotics-Arm-Dynamixel PCB?
The 6-DOF-Robotics-Arm-Dynamixel measures 134.5 × 70 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the 6-DOF-Robotics-Arm-Dynamixel?
13 components, from 13 distinct parts. The full bill of materials is listed on this page.
Where can I download the 6-DOF-Robotics-Arm-Dynamixel design files?
From the Ramahabir/6-DOF-Robotics-Arm-Dynamixel repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the 6-DOF-Robotics-Arm-Dynamixel design in my own project?
Yes, under the terms of its MIT license, which Ramahabir chose for the repository.
Can I test firmware for the 6-DOF-Robotics-Arm-Dynamixel without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k