
Roboracing micromouse

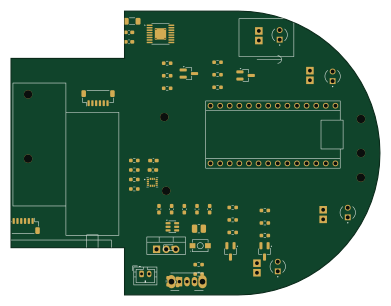
About the Roboracing micromouse PCB
Roboracing micromouse is an open source NXP PCB design by RoboJackets, published on GitHub. It is a 4-layer board measuring 97.5 × 75 mm, with 57 components from 29 distinct parts.
Its main chip is the TEENSY_4.0, from the NXP family. Other key parts include the AP63205WU, LSM6DSV16XTR and DRV8833PW. By type, the board carries 20 resistors, 10 capacitors, 9 transistors, 5 diodes, 3 ICs and 3 test points.
It belongs with the robotics & motion designs in this gallery.
From the project
This year, we are making Ratatouillii! 🐭🔥
This year, we are making Ratatouillii! 🐭🔥
The KiCad project is at pcb/micromouse-pcb.kicadpro. Its original component libraries are retained under pcb/libraries/` and registered through project-specific library tables—no absolute paths or per-user library installation required.
See docs/kicad-library-guide.md for first-time setup and the required workflow for adding or changing symbols, footprints, and 3D models.

Main components on the Roboracing micromouse
Roboracing micromouse bill of materials (BOM)
57 components, 29 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AP63205WU | TSOT-23-6 | U2 |
| 1 | LSM6DSV16XTR | XDCR_LSM6DSV16XTR | U3 |
| 1 | DRV8833PW | TSSOP-16-1EP_4.4x5mm_P0.65mm_EP3x3mm_ThermalVias | U4 |
| 1 | TEENSY_4.0 | TEENSY_SHORT | A2 |
| 1 | FQP27P06 | TO-220-3_Vertical | Q1 |
| 4 | AO3400A | SOT-23_Handsoldering | Q2, Q3, Q4, Q5 |
| 4 | TEFT4300 | XDCR_TEFT4300 | Q11, Q13, Q15, Q17 |
| 2 | Conn_01x06 | JST_SH_BM06B-SRSS-TB_1x06-1MP_P1.00mm_Vertical | J1_MotorEncoder1, J2_MotorEncoder1 |
| 1 | Battery | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | 7.4_LiPo1 |
| 1 | SW_SPDT | SW_Slide_SPDT_Angled_CK_OS102011MA1Q | SW3 |
| 1 | SW_Push | SW-SMD_L4.0-W2.9-LS5.0 | SW6 |
| 3 | TestPoint | TestPoint_THTPad_D2.0mm_Drill1.0mm | TP1, TP2, TP5 |
| 1 | LED | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D2 |
| 4 | SFH_4545 | DIO_SFH_4545 | D6, D7, D8, D9 |
| 1 | L 4.7μH | L_1008_2520Metric_Pad1.43x2.20mm_HandSolder | L1 |
| 2 | 100nF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1, C2 |
| 2 | C 22uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C3, C4 |
| 1 | C 10uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C5 |
| 2 | C 100nF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C6, C7 |
| 1 | C 2.2uF 6.3V | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C8 |
Show 9 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | C 47uF >10V | C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C9 |
| 1 | 0.01uF >16V | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C10 |
| 2 | 1M | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R2, R9 |
| 5 | 100 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R5, R20, R23, R26, R29 |
| 1 | 2M | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R8 |
| 3 | 4.7k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10, R11, R12 |
| 1 | 10k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R13 |
| 4 | 36 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R21, R24, R27, R30 |
| 4 | 800 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R22, R25, R28, R31 |
Roboracing micromouse design files
The KiCad project lives in the RoboJackets/roboracing-micromouse-pcb repository on GitHub; these links point at the commit this page was built from.
- Layoutpcb/micromouse-pcb.kicad_pcb
- Schematicpcb/micromouse-pcb.kicad_sch
Roboracing micromouse: common questions
What microcontroller does the Roboracing micromouse use?
The Roboracing micromouse is built around the TEENSY_4.0, from the NXP family.
How big is the Roboracing micromouse PCB?
The Roboracing micromouse measures 97.5 × 75 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Roboracing micromouse?
57 components, from 29 distinct parts. The full bill of materials is listed on this page.
Where can I download the Roboracing micromouse design files?
From the RoboJackets/roboracing-micromouse-pcb repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Roboracing micromouse design in my own project?
The repository has no license, so all rights stay with RoboJackets. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Roboracing micromouse without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug NXP firmware against it before you order a PCB.
Similar boards
 NXP
32Bit shift register
MaltWhiskey
100 × 54 mm56 parts4LNo license763 NXP
Mega-Cube-Board
200 × 54 mm100 parts4LNo license763 NXP
MCL6809
MicroCoreLabs
32.3 × 61 mm7 parts4LNo license532 NXP
MCL68
31.6 × 84.1 mm13 parts4LNo license532 NXP
MCL65+
72.6 × 64.1 mm6 parts2LNo license532 NXP
MCLZ8
37.1 × 61.5 mm6 parts4LNo license532