
Robot

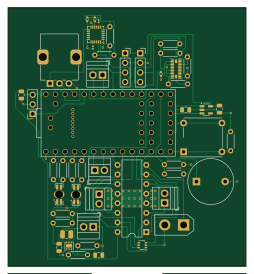
About the Robot PCB
Robot is an open source NXP PCB design by sidstuff, published on GitHub under the MIT license. It is a 2-layer board measuring 63 × 68.5 mm, with 71 components from 35 distinct parts.
Its main chip is the Teensy4.0, from the NXP family. Other key parts include the ADXL343, TPS610997DRV, MPU-6050, Inverter_Schmitt_Dual and L293D. By type, the board carries 29 resistors, 12 capacitors, 11 connectors, 9 ICs, 4 transistors and 2 diodes.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
A KiCad PCB for an obstacle avoiding robot.
A common type is the micromouse, a small robot which tries to solve a maze. I.e., it tries to reach the center of a maze made up of a 16×16 grid of cells, each 180 mm square with walls 50 mm high.
While picking parts, ensure that the voltage/current/power ratings of componenets are not exceeded. Also, lithium cells have a nominal voltage of 3.7V (although it can go up to 4.2V when fully charged, and can be discharged until 3V), so their batteries are going to be multiples of the same.
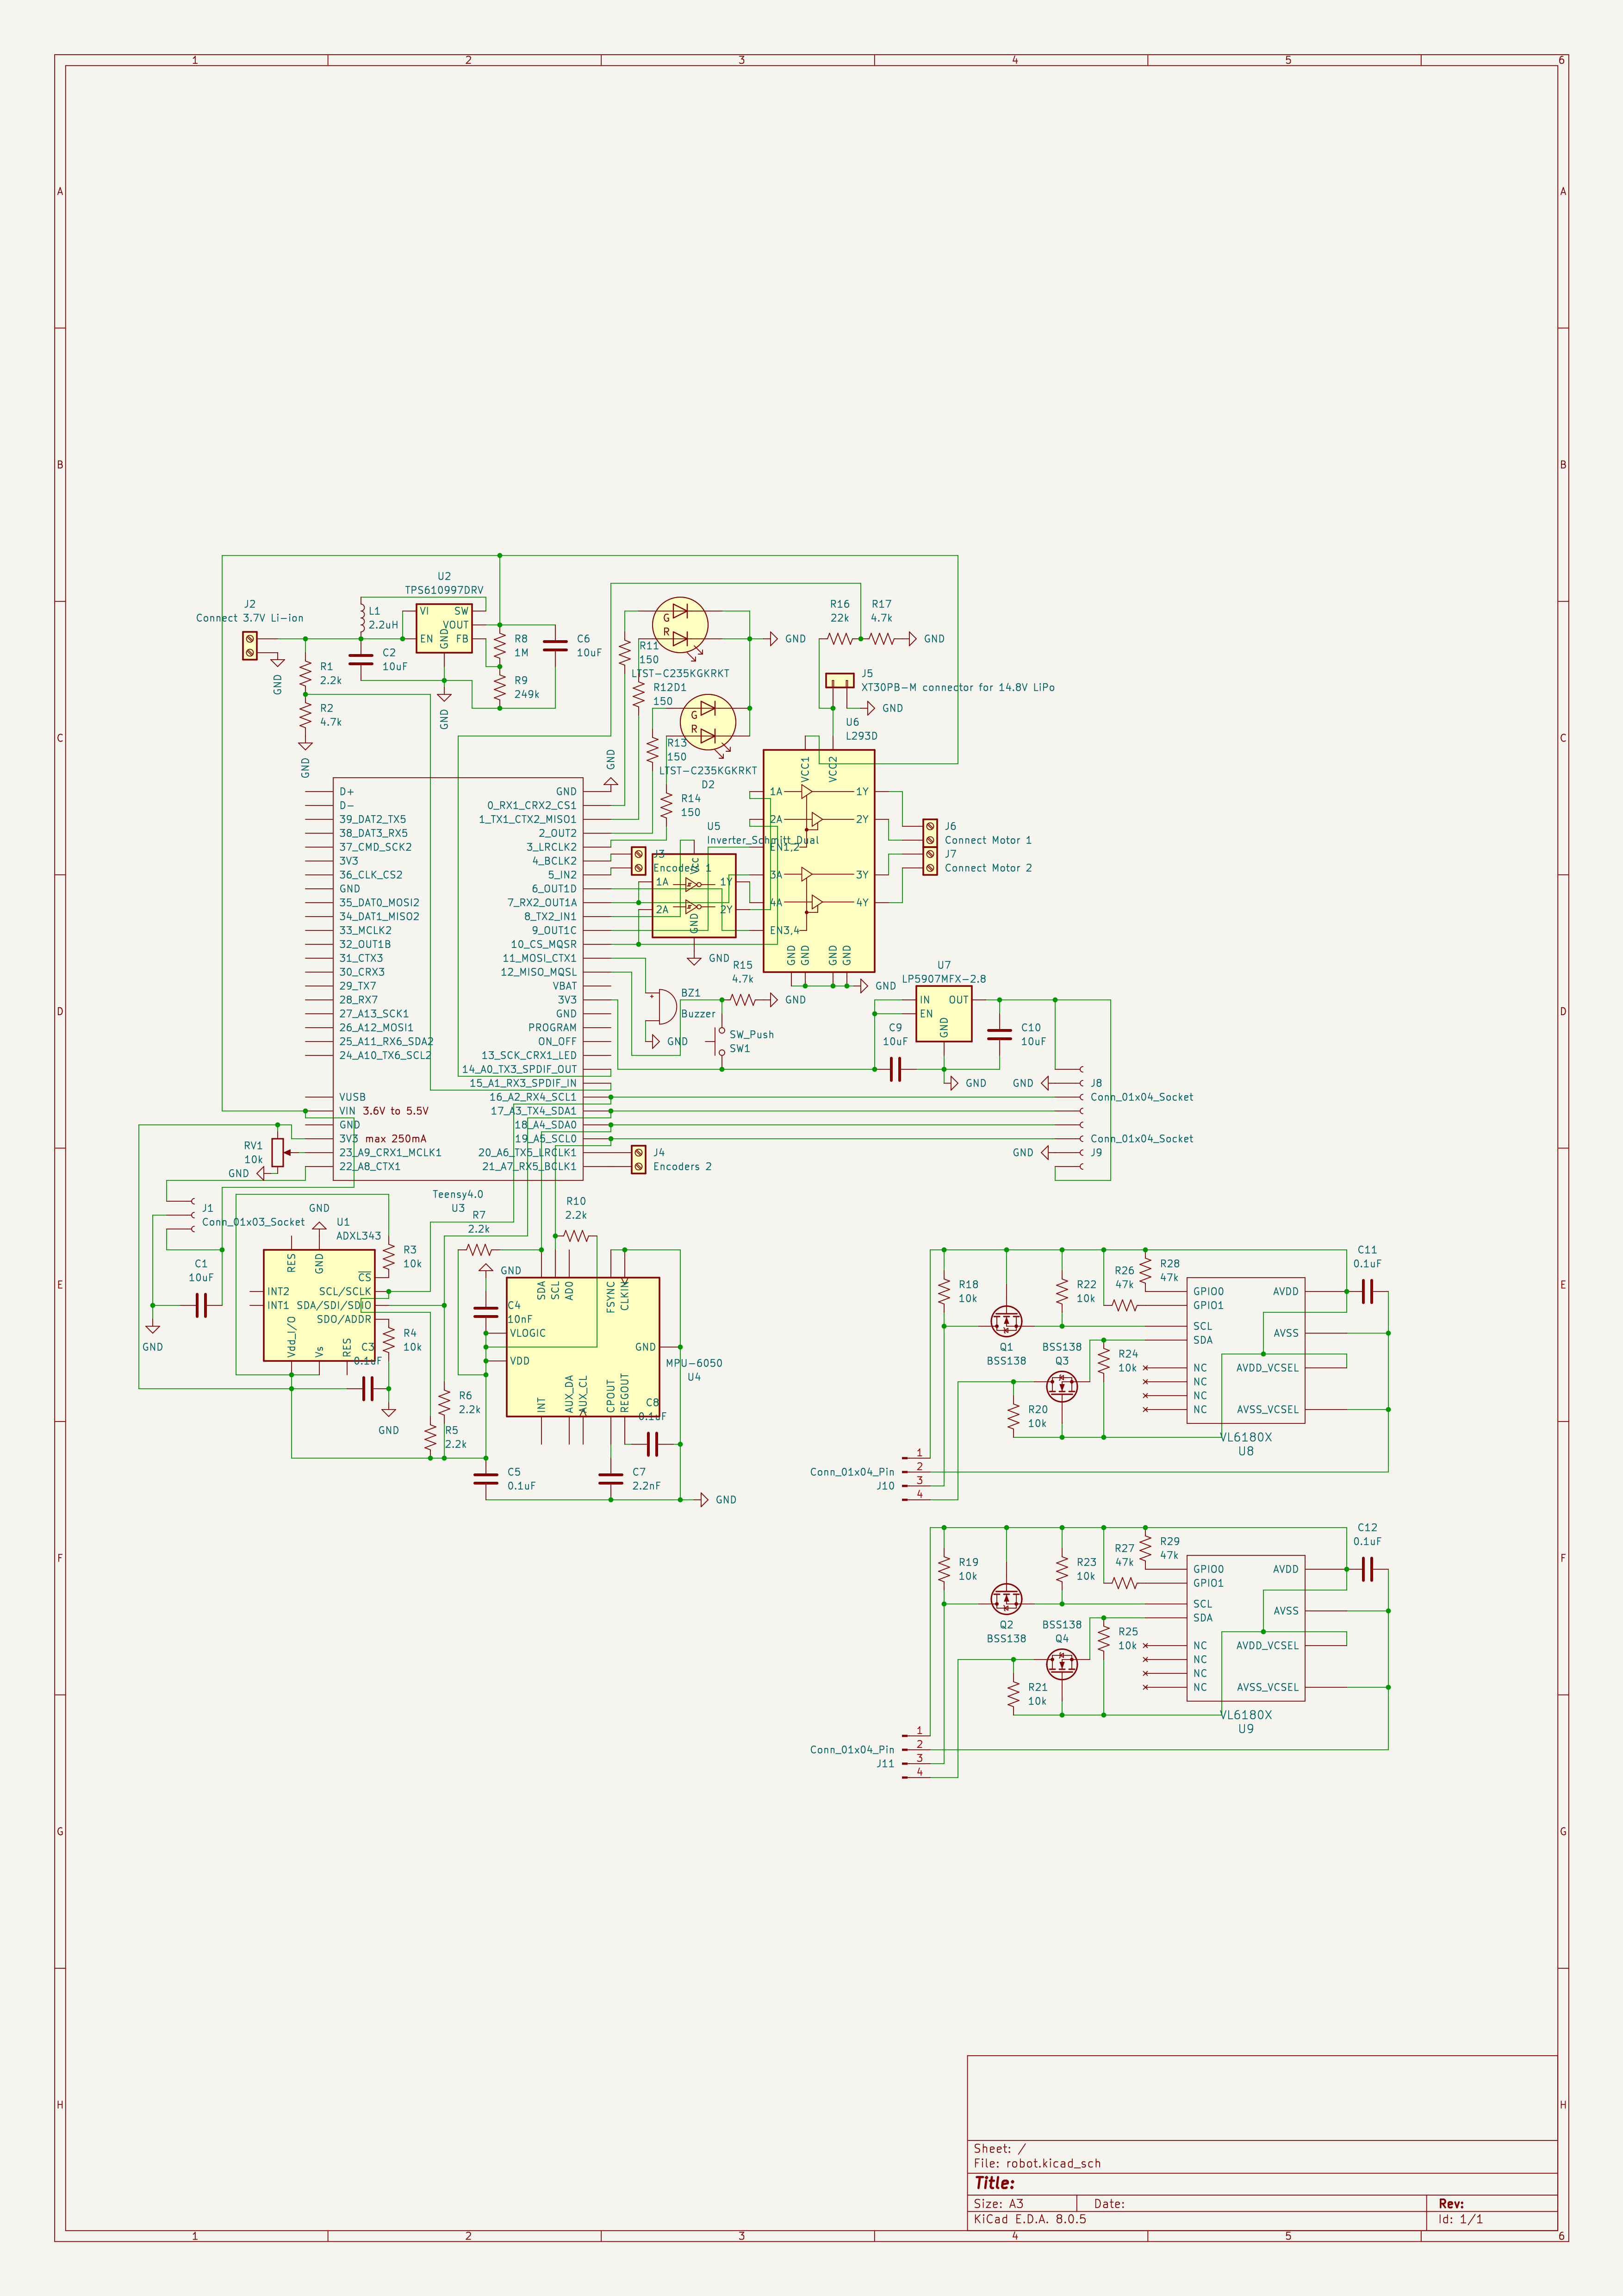
Main components on the Robot
Robot bill of materials (BOM)
71 components, 35 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ADXL343 | LGA-14_3x5mm_P0.8mm_LayoutBorder1x6y | U1 |
| 1 | TPS610997DRV | WSON-6-1EP_2x2mm_P0.65mm_EP1x1.6mm | U2 |
| 1 | Teensy4.0 | Teensy40_SMT | U3 |
| 1 | MPU-6050 | InvenSense_QFN-24_4x4mm_P0.5mm | U4 |
| 1 | Inverter_Schmitt_Dual | SOT-363_SC-70-6 | U5 |
| 1 | L293D | DIP-16_W7.62mm | U6 |
| 1 | LP5907MFX-2.8 | SOT-23-5 | U7 |
| 2 | VL6180X | VL6180X | U8, U9 |
| 4 | BSS138 | SOT-23 | Q1, Q2, Q3, Q4 |
| 1 | Conn_01x03_Socket | PinSocket_1x03_P2.54mm_Vertical | J1 |
| 1 | Connect 3.7V Li-ion | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J2 |
| 1 | Encoders 1 | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J3 |
| 1 | Encoders 2 | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J4 |
| 1 | XT30PB-M connector for 14.8V LiPo | AMASS_XT30UPB-M_1x02_P5.0mm_Vertical | J5 |
| 1 | Connect Motor 1 | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J6 |
| 1 | Connect Motor 2 | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J7 |
| 2 | Conn_01x04_Socket | PinSocket_1x04_P2.54mm_Vertical | J8, J9 |
| 2 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Horizontal | J10, J11 |
| 1 | Buzzer | Buzzer_12x9.5RM7.6 | BZ1 |
| 1 | 10k | Potentiometer_Alps_RK09K_Single_Vertical | RV1 |
Show 15 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SW_Push | SW_MEC_5GTH9 | SW1 |
| 2 | LTST-C235KGKRKT | LED_LiteOn_LTST-C235KGKRKT | D1, D2 |
| 1 | 2.2uH | L_1008_2520Metric | L1 |
| 5 | 10uF | C_0805_2012Metric | C1, C2, C6, C9, C10 |
| 5 | 0.1uF | C_0402_1005Metric | C3, C5, C8, C11, C12 |
| 1 | 10nF | C_0201_0603Metric | C4 |
| 1 | 2.2nF | C_0201_0603Metric | C7 |
| 5 | 2.2k | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R1, R5, R6, R7, R10 |
| 3 | 4.7k | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R2, R15, R17 |
| 10 | 10k | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R3, R4, R18, R19, R20, R21, R22, R23 +2 |
| 1 | 1M | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R8 |
| 1 | 249k | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R9 |
| 4 | 150 | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R11, R12, R13, R14 |
| 1 | 22k | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R16 |
| 4 | 47k | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R26, R27, R28, R29 |
Robot design files
The KiCad project lives in the sidstuff/robot repository on GitHub; these links point at the commit this page was built from.
- Layoutrobot.kicad_pcb
- Schematicrobot.kicad_sch
Robot: common questions
What microcontroller does the Robot use?
The Robot is built around the Teensy4.0, from the NXP family.
How big is the Robot PCB?
The Robot measures 63 × 68.5 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot?
71 components, from 35 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot design files?
From the sidstuff/robot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robot design in my own project?
Yes, under the terms of its MIT license, which sidstuff chose for the repository.
Can I test firmware for the Robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug NXP firmware against it before you order a PCB.
Similar boards
 NXP
32Bit shift register
MaltWhiskey
100 × 54 mm56 parts4LNo license763 NXP
Mega-Cube-Board
200 × 54 mm100 parts4LNo license763 NXP
MCL64
MicroCoreLabs
39.3 × 61.8 mm9 parts4LNo license532 NXP
ROM Emulator
21.5 × 37.1 mm5 parts2LNo license532 NXP
MCLZ8
37.1 × 61.5 mm6 parts4LNo license532 NXP
XTMAX
81 × 46 mm14 parts4LNo license532