
PCB LoRa 32

About the PCB LoRa 32
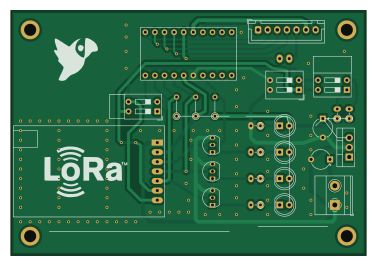
PCB LoRa 32 is an open source PCB design by steger123, published on GitHub. It is a 2-layer board measuring 94 × 64.8 mm, with 26 components from 16 distinct parts.
Other key parts include the LM7803_TO220 and LoRa_E32. By type, the board carries 7 resistors, 4 diodes, 3 transistors, 3 switches, 2 connectors and 2 capacitors.
It belongs with the rf & radio, robotics & motion and sensors designs in this gallery.
From the project
This project is an Open Source initiative to make a fully autonomous robot for grass cutting. Later much bigger stuff.
Create a general, affordable, computational platform, which can be used for small & medium size robots.
The navivation can be: fully maunal, semi and full autonomouse. The mechanical side not restricted. As the project progressing and evolving You can learn more and more, and of course, have the designs and codes for free.
AI: Python (Jetson NANO) https://github.com/steger123/Lawn-mower-robot/tree/master/03Software%20codes/03PythonAIJetson%20Nano/01_myOpenCV
Main components on the PCB LoRa 32
PCB LoRa 32 bill of materials (BOM)
26 components, 16 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LM7803_TO220 | TO-220-3_Vertical | U1 |
| 1 | LoRa_E32 | LoRa_E32 | A1 |
| 3 | 2N3906 | TO-92_Inline | Q1, Q2, Q3 |
| 1 | HEADER_5 | JST_XH_B7B-XH-A_1x07_P2.50mm_Vertical | J3 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J4 |
| 2 | 8k | R_Axial_DIN0204_L3.6mm_D1.6mm_P2.54mm_Vertical | 8k1, 8k2 |
| 1 | Logic_lev_shift_8ch | Logic_lev_shift_8ch | LL1 |
| 3 | SW_DIP_x02 | SW_DIP_SPSTx02_Slide_9.78x7.26mm_W7.62mm_P2.54mm | SW1, SW2, SW3 |
| 1 | Rx | LED_D5.0mm | D1 |
| 1 | Tx | LED_D5.0mm | D2 |
| 1 | Aux | LED_D5.0mm | D3 |
| 1 | Power | LED_D5.0mm | D4 |
| 2 | 100n | CP_Radial_Tantal_D5.0mm_P5.00mm | C100n1, C100n2 |
| 1 | 1k | R_Axial_DIN0204_L3.6mm_D1.6mm_P2.54mm_Vertical | R1k1 |
| 3 | 4k7 | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Vertical | R4k1, R4k2, R4k7 |
| 3 | 100 | R_Axial_DIN0204_L3.6mm_D1.6mm_P2.54mm_Vertical | R100, R100_1, R100_2 |
PCB LoRa 32 design files
The KiCad project lives in the steger123/Lawn-mower-robot repository on GitHub; these links point at the commit this page was built from.
PCB LoRa 32: common questions
How big is the PCB LoRa 32?
The PCB LoRa 32 measures 94 × 64.8 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the PCB LoRa 32?
26 components, from 16 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the PCB LoRa 32 design files?
From the steger123/Lawn-mower-robot repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the PCB LoRa 32 design in my own project?
The repository has no license, so all rights stay with steger123. Use it as a reference, and ask the author before reusing the design.
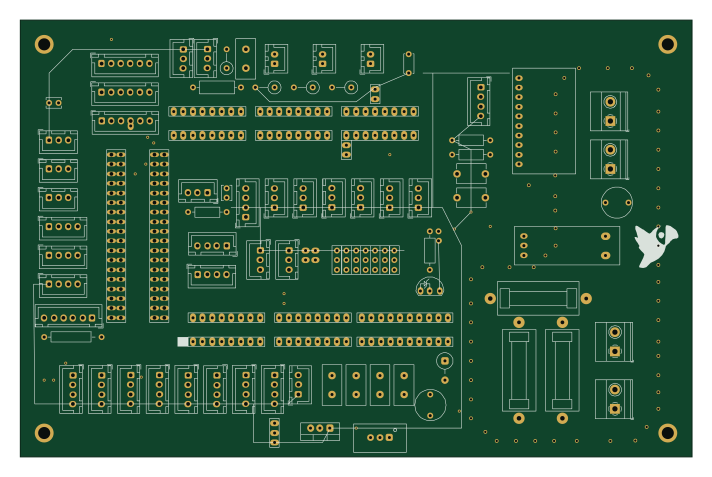
More boards in Lawn-mower-robot
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k