
Control ROV

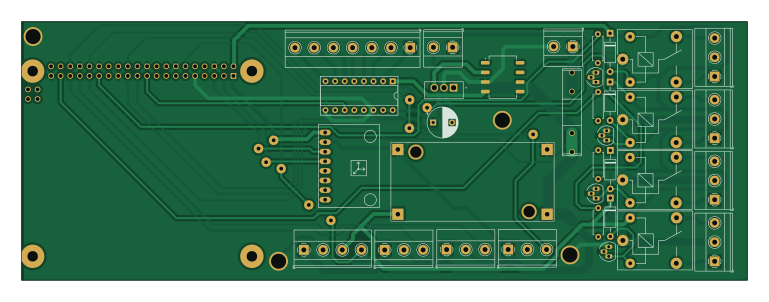
About the Control ROV PCB
Control ROV is an open source Raspberry Pi PCB design by tdominguezmasciale, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 191.9 × 68.4 mm, with 35 components from 17 distinct parts.
Its main chip is the MODULE_RASPBERRY_PI_4B_4GB, from the Raspberry Pi family. Other key parts include the MCP3208, TRI1-2413, L7805 and MPXA6115A. By type, the board carries 11 connectors, 4 ICs, 4 transistors, 4 relays, 4 diodes and 4 resistors.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
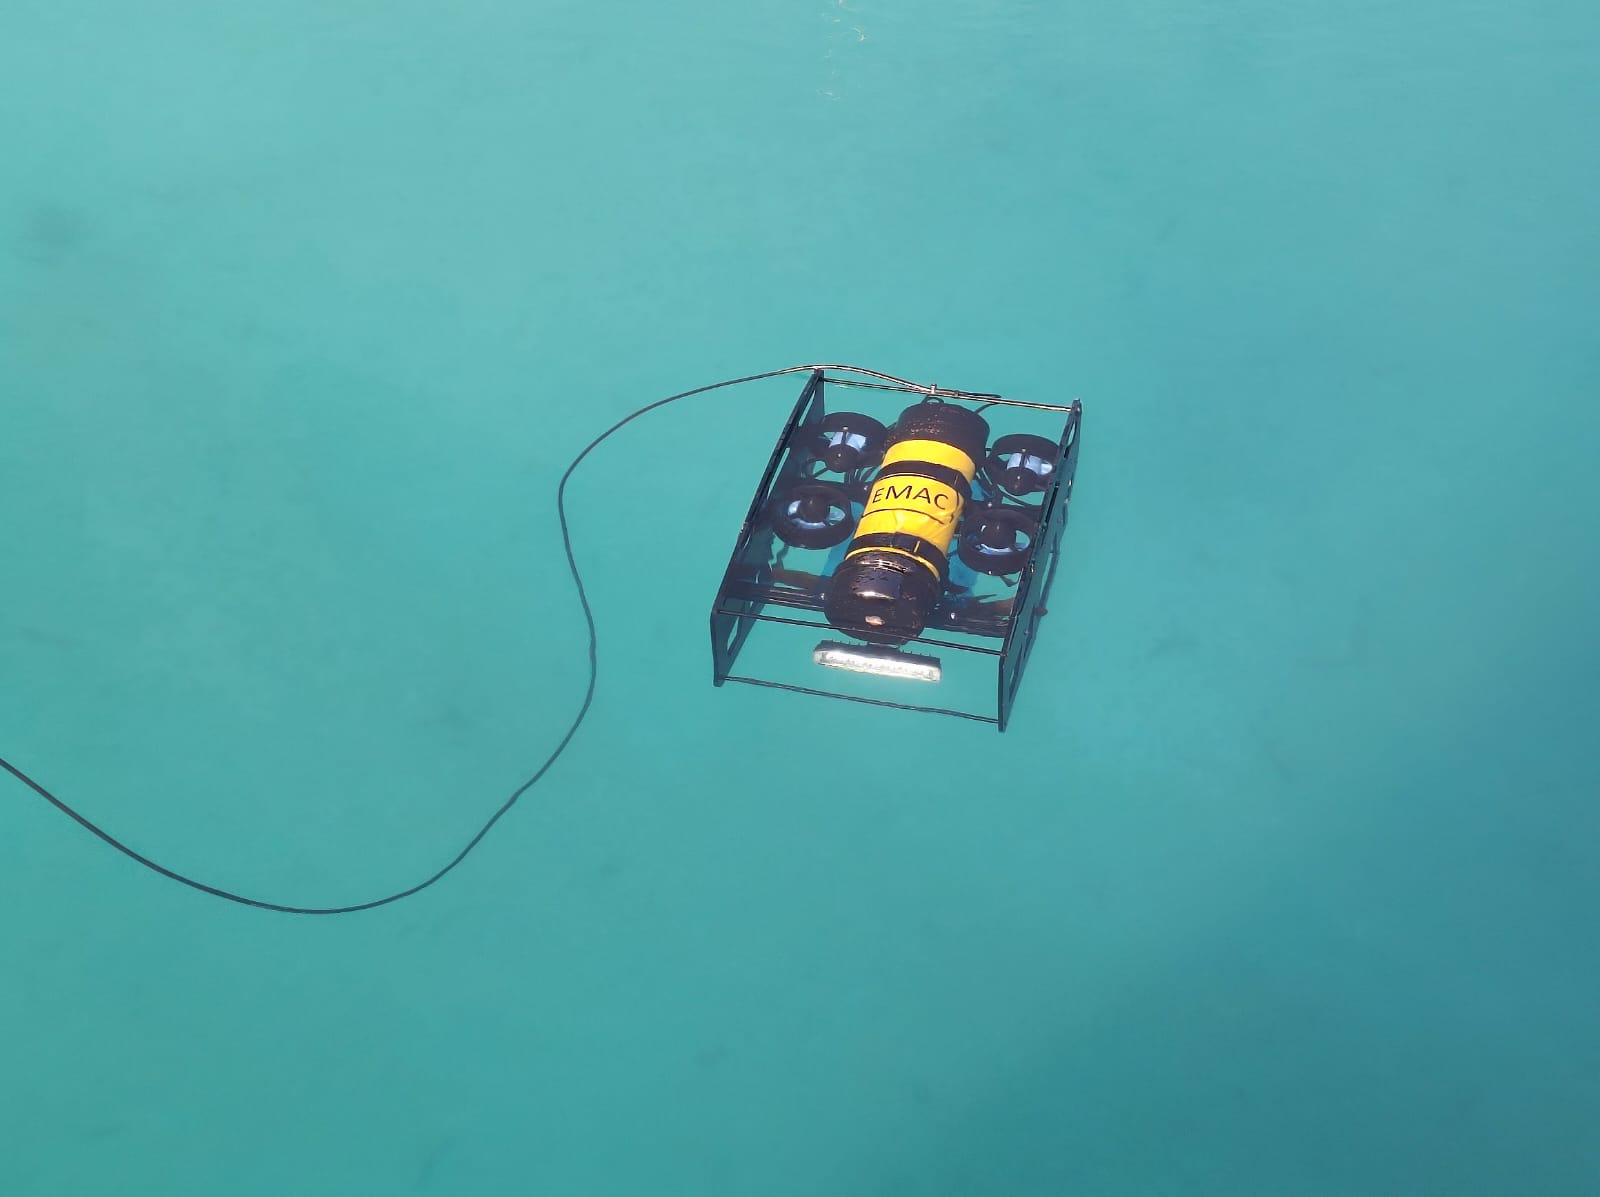
A Flask-based control system for a Raspberry Pi 4 ROV, featuring real-time video streaming, PID depth stabilization, and a web-based telemetry dashboard.
This project implements a local network-controlled ROV system. It features a web-based control interface, real-time video streaming, depth control via PID, and inertial measurement capabilities. The system is built around a Raspberry Pi 4B as the central processing unit. This project can be run without hardware connections for testing purposes.
1. Update System bash sudo apt install python3-full -y sudo apt-get install python3-flask bash sudo apt install build-essential libjpeg-dev imagemagick libv4l-dev git cmake uvcdynctrl -y cd ~ git clone https://github.com/jacksonliam/mjpg-streamer.git…
Main components on the Control ROV
Control ROV bill of materials (BOM)
35 components, 17 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MCP3208 | DIP-16_W7.62mm_Socket | U1 |
| 1 | TRI1-2413 | XL4005_DC-DC | U2 |
| 1 | L7805 | TO255P1020X450X2000-3 | U3 |
| 1 | MPXA6115A | CFSensor_XGZP6897x | U4 |
| 4 | NPN | TO-92L_HandSolder | Q1, Q2, Q3, Q4 |
| 1 | Conn_02x20_Odd_Even | MODULE_RASPBERRY_PI_4B_4GB | J1 |
| 7 | Conn_01x03_Pin | TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J2, J4, J5, J6, J13, J14, J16 |
| 1 | Conn_01x02_Pin | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J3 |
| 1 | Conn_01x04_Pin | TerminalBlock_Phoenix_MKDS-1,5-4-5.08_1x04_P5.08mm_Horizontal | J7 |
| 1 | Conn_01x07_Pin | TerminalBlock_Phoenix_MKDS-1,5-7-5.08_1x07_P5.08mm_Horizontal | J15 |
| 1 | GY-521 | GY-521 | ACC1 |
| 1 | Fuse | Fuse_20x5 | F1 |
| 4 | SANYOU_SRD_Form_C | Relay_SPDT_SANYOU_SRD_Series_Form_C | K1, K4, K5, K6 |
| 1 | 1 | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | V1 |
| 4 | D | D_A-405_P10.16mm_Horizontal | D1, D4, D5, D6 |
| 1 | C_Polarized | CP_Radial_D8.0mm_P5.00mm | C1 |
| 4 | R | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2, R3, R4 |
Control ROV design files
The KiCad project lives in the tdominguezmasciale/Control_ROV repository on GitHub; these links point at the commit this page was built from.
- LayoutPCB/PCB.kicad_pcb
- SchematicPCB/PCB.kicad_sch
Control ROV: common questions
What microcontroller does the Control ROV use?
The Control ROV is built around the MODULE_RASPBERRY_PI_4B_4GB, from the Raspberry Pi family.
How big is the Control ROV PCB?
The Control ROV measures 191.9 × 68.4 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Control ROV?
35 components, from 17 distinct parts. The full bill of materials is listed on this page.
Where can I download the Control ROV design files?
From the tdominguezmasciale/Control_ROV repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Control ROV design in my own project?
Yes, under the terms of its GPL-3.0 license, which tdominguezmasciale chose for the repository.
Can I test firmware for the Control ROV without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
Similar boards
 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k Raspberry Pi
Iot
dotnet
56 × 65 mm24 parts2LMIT2.4k Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license673 Raspberry Pi
Phased
Neumi
75 × 100 mm71 parts2LNo license507