
Roboterarm1

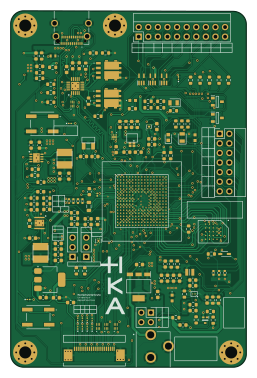
About the Roboterarm1 PCB
Roboterarm1 is an open source STM32 PCB design by tobiasbaas, published on GitHub. It is a 4-layer board measuring 62.4 × 94.3 mm, with 216 components from 82 distinct parts.
Its main chip is the STM32N657X0H3Q, from the STM32 family. Other key parts include the TCPP03-M20, ESDALC6V1W5, MX25UM51245GXDI00-TR, LD56100DPU18R and ST1S31PUR. By type, the board carries 96 capacitors, 60 resistors, 14 ICs, 13 diodes, 8 connectors and 6 LEDs.
It belongs with the robotics & motion designs in this gallery.
From the project
Herzlich willkommen zum Repo des Robotersarmes der Arbeitsgruppe. Bitte beachtet, dass es sich hierbei handelt um eine Erweiterung bereits vorhandener Infrastruktur. Für mehr Infos siehe das bisherige Github Repo: - (https://github.com/mama1120/rpiroscan_module.git)
Herzlich willkommen zum Repo des Robotersarmes der Arbeitsgruppe. Bitte beachtet, dass es sich hierbei handelt um eine Erweiterung bereits vorhandener Infrastruktur. Für mehr Infos siehe das bisherige Github Repo: - (https://github.com/mama1120/rpiroscan_module.git)
Sowie als auch das offiziele Wiki zu den vergangegen Projekten im Ilias: - (https://ilias.h-ka.de/goto.php?target=wiki787531#ilmheadtfocus)
Main components on the Roboterarm1
Roboterarm1 bill of materials (BOM)
216 components, 82 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TCPP03-M20 | QFN50P400X400X80-21N-D | IC2 |
| 3 | ESDALC6V1W5 | SOT65P210X110-5N | IC3, IC6, IC13 |
| 1 | MX25UM51245GXDI00-TR | BGA24C100P5X5_600X800X120 | IC5 |
| 1 | LD56100DPU18R | LD56100DPU18R | IC7 |
| 2 | ST1S31PUR | SON65P300X300X100-9N-D | IC8, IC9 |
| 1 | TPS62088YFPT | BGA6C40P2X3_80X120X50 | IC10 |
| 1 | LD1117S50TR | SOT230P700X190-4N | IC11 |
| 1 | LD39020ADTPU33R | OnSemi_XDFN4-1EP_1.0x1.0mm_EP0.52x0.52mm | U1 |
| 1 | LD39020ADTPU18R | OnSemi_XDFN4-1EP_1.0x1.0mm_EP0.52x0.52mm | U2 |
| 1 | LD1117S33TR | SOT-223-3_TabPin2 | U3 |
| 1 | STM32N657X0H3Q | BGA264C80P17X17_1400X1400X100 | U4 |
| 1 | SI1062X-T1-GE3 | SOTFL50P160X80-3N | Q1 |
| 2 | STL40DN3LLH5 | STL40DN3LLH5 | Q2, Q5 |
| 2 | BSR14 | SOT95P240X120-3N | Q3, Q4 |
| 1 | ABM12W-48.0000MHZ-7-D1X-T3 | ABM12W300000MHZ6B1UT3 | Y2 |
| 1 | CM7V-T1A-32.768KHZ-6PF-20PPM-TA-QC | CM7V32768TBQA020 | Y3 |
| 1 | CONN_02X07_ODD_EVEN Conn_02x07_Odd_Even | PinHeader_2x07_P2.54mm_Vertical | J1 |
| 1 | CONN_02X10_ODD_EVEN Conn_02x10_Odd_Even | PinHeader_2x10_P2.54mm_Vertical | J2 |
| 1 | CONN_02X02_ODD_EVEN Conn_02x02_Odd_Even | PinHeader_2x02_P2.54mm_Vertical | J3 |
| 1 | 12401826E412A | 12401826E412A | J4 |
Show 62 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | CONN_01X03 Conn_01x03 | PinHeader_1x03_P2.54mm_Vertical | J5, J6 |
| 1 | 2-1734592-2 | 217345922 | J7 |
| 1 | PJ-102B | PJ102B | J8 |
| 4 | ECMF2-40A100N6 | ECMF240A100N6 | FL1, FL2, FL3, FL4 |
| 2 | KSC721J LFS KSC721J_LFS | KSC721JLFS | S1, S2 |
| 3 | KG EELP41.22-PHRH-35-A8J8-20-R18 KG_EELP41.22-PHRH-35-A8J8-20-R18 | KGEELP4122PHRH35A8J820R18 | LED1, LED2, LED6 |
| 2 | LS R976-NR-1 LS_R976-NR-1 | LEDC2012X40N | LED3, LED5 |
| 1 | LB Q39G-L2OO-35-1 LB_Q39G-L2OO-35-1 | LEDC1608X40N | LED4 |
| 1 | BAT60JFILM | SOD2513X117N | D1 |
| 1 | ESDA25P35-1U1M | ESDA25P351U1M | D2 |
| 11 | ESDALC6V1-1U2 | ESDALC6V11U2 | D3, D4, D5, D6, D7, D8, D9, D10 +3 |
| 1 | FBMJ1608HM180NTR | L_0603_1608Metric | L1 |
| 1 | 74479276168 | L_0805_2012Metric | L2 |
| 1 | LQW18AN2N2D10D | L_0603_1608Metric | L3 |
| 2 | 74404043022A | INDPM4040X250N | L4, L5 |
| 1 | DFE201612P-R24M=P2 | 1286ASH1R0MP2 | L6 |
| 4 | 100N 100n | C_0603_1608Metric | C1, C2, C5, C68 |
| 3 | 4.7U 4.7u | C_0603_1608Metric | C3, C4, C6 |
| 24 | 100N 100n | C_0201_0603Metric | C7, C11, C12, C13, C14, C15, C16, C17 +16 |
| 1 | 4.7U 4.7u | C_0201_0603Metric | C8 |
| 1 | 2.2N 2.2n | C_0201_0603Metric | C9 |
| 12 | 1u | C_0201_0603Metric | C10, C28, C32, C33, C34, C35, C36, C37 +4 |
| 5 | 22U 22u | C_0402_1005Metric | C30, C31, C42, C43, C44 |
| 15 | 22U 22u | C_0603_1608Metric | C51, C52, C53, C54, C55, C56, C59, C100 +7 |
| 1 | 10 | C_0603_1608Metric | C57 |
| 9 | 10U 10u | C_0603_1608Metric | C58, C71, C72, C89, C90, C98, C99, C104 +1 |
| 1 | 220U 220u | C_0603_1608Metric | C60 |
| 2 | 2.2P 2.2p | C_0603_1608Metric | C61, C62 |
| 2 | 8.2P 8.2p | C_0603_1608Metric | C63, C64 |
| 1 | 2.2U 2.2u | C_0603_1608Metric | C65 |
| 2 | 330P 330p | C_0603_1608Metric | C66, C67 |
| 1 | 10P 10p | C_0603_1608Metric | C69 |
| 1 | 10N 10n | C_0603_1608Metric | C70 |
| 9 | 1u | C_0603_1608Metric | C73, C91, C92, C93, C95, C96, C97, C103 +1 |
| 1 | ^22u | C_0603_1608Metric | C94 |
| 1 | 22P 22p | C_0603_1608Metric | C105 |
| 8 | 10K 10k | R_0603_1608Metric | R1, R2, R5, R20, R27, R32, R41, R42 |
| 1 | 0 | R_0402_1005Metric | R3 |
| 13 | 0 | R_0603_1608Metric | R6, R9, R45, R47, R48, R58, R60, R61 +5 |
| 1 | 50M 50m | R_0402_1005Metric | R7 |
| 1 | 160K 160k | R_0603_1608Metric | R10 |
| 1 | 422K 422k | R_0603_1608Metric | R11 |
| 1 | 150K 150k | R_0603_1608Metric | R12 |
| 1 | 1M | R_0603_1608Metric | R13 |
| 2 | 50M 50m | R_0603_1608Metric | R14, R15 |
| 2 | 330M 330m | R_0603_1608Metric | R16, R50 |
| 1 | 820 | R_0603_1608Metric | R17 |
| 2 | 1.5K 1.5k | R_0603_1608Metric | R18, R19 |
| 3 | 100K 100k | R_0603_1608Metric | R21, R26, R35 |
| 3 | 24K 24k | R_0603_1608Metric | R22, R52, R55 |
| 2 | 1.3M | R_0603_1608Metric | R23, R25 |
| 2 | 22M 22m | R_0603_1608Metric | R24, R33 |
| 2 | 47K 47k | R_0603_1608Metric | R28, R34 |
| 1 | 22K 22k | R_0603_1608Metric | R29 |
| 1 | 270 | R_0603_1608Metric | R30 |
| 1 | 140K 140k | R_0603_1608Metric | R31 |
| 2 | 200 | R_0603_1608Metric | R36, R37 |
| 5 | 330 | R_0603_1608Metric | R38, R39, R40, R56, R57 |
| 1 | 750M 750m | R_0603_1608Metric | R49 |
| 1 | 75K 75k | R_0603_1608Metric | R51 |
| 1 | 560 | R_0603_1608Metric | R53 |
| 1 | 30K 30k | R_0603_1608Metric | R54 |
Roboterarm1 design files
The KiCad project lives in the tobiasbaas/Roboterarm1 repository on GitHub; these links point at the commit this page was built from.
Roboterarm1: common questions
What microcontroller does the Roboterarm1 use?
The Roboterarm1 is built around the STM32N657X0H3Q, from the STM32 family.
How big is the Roboterarm1 PCB?
The Roboterarm1 measures 62.4 × 94.3 mm, has 4 copper layers and is 1.579 mm thick.
How many components are on the Roboterarm1?
216 components, from 82 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Roboterarm1 design files?
From the tobiasbaas/Roboterarm1 repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Roboterarm1 design in my own project?
The repository has no license, so all rights stay with tobiasbaas. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Roboterarm1 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
LibreVNA
jankae
122 × 98 mm592 parts6LGPL-3.01.6k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k