
Robosub Power

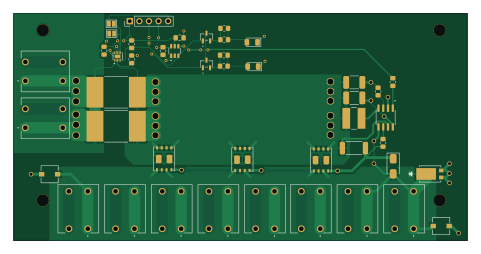
About the Robosub Power PCB
Robosub Power is an open source PCB design by valex2, published on GitHub. It is a 2-layer board measuring 120 × 60 mm, with 45 components from 23 distinct parts.
Other key parts include the INA300AIDSQT, SN74LVC1G97DBVR, AUIR3241STR, BSC0702LSATMA1 and NVTR01P02LT1G. By type, the board carries 11 connectors, 11 resistors, 8 ICs, 6 capacitors, 3 diodes and 2 jumpers.
From the project
Stanford Robosub Electrical Repository
DO NOT RUN FOR MORE THAN 10 SECONDS WHILE OUTSIDE OF WATER
Use serial library in Python, and write as follows: > portName.write(b"thrusternumber delayvalue")
Main components on the Robosub Power
Robosub Power bill of materials (BOM)
45 components, 23 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | INA300AIDSQT Texas Instruments | SON40P200X200X80-11N | U1 |
| 1 | SN74LVC1G97DBVR Texas Instruments | SOT95P280X145-6N | U2 |
| 1 | AUIR3241STR Infineon Technologies | SOIC127P600X175-8N_AUIR3241STR | U3 |
| 3 | BSC0702LSATMA1 Infineon Technologies | BSC0702LSATMA1 | U4, U5, U6 |
| 2 | NVTR01P02LT1G onsemi | SOT-23-3_1P4X3P040_ONS | U7, U8 |
| 10 | 1135333 Pheonix Contact | PHOENIX_1135333 | J1, J2, J3, J4, J5, J6, J7, J8 +2 |
| 1 | Conn_01x05_Pin | PinHeader_1x05_P2.54mm_Vertical | J11 |
| 1 | SBRT15U50SP5-13 Diodes Incorporated | POWERDI5_DIO | CR1 |
| 2 | SOLDERJUMPER_2_OPEN SolderJumper_2_Open | SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP4, JP5 |
| 2 | 2mOhm Vishay Dale | RES_WSLP5931_.002OHM_VIS | WSLP59312L000FEA_1, WSLP59312L000FEA_2 |
| 1 | 1SMA5931BT3 onsemi | D_SMA | D1 |
| 2 | IR26-21C_L110_TR8 Everlight Electronics Co Ltd | LED_1206_3216Metric | D2, D3 |
| 1 | 74477420 Würth Elektronik | IND_5848-WE-PD2_WRE | L1 |
| 2 | 0.1U 0.1u YAGEO | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2 |
| 2 | 1UF 1uF Knowles Syfer | C_1812_4532Metric_Pad1.57x3.40mm_HandSolder | C3, C4 |
| 2 | 1u (electrolytic) Nichicon | UCB1V0R1MCL1GS | C5, C6 |
| 3 | 10K 10k YAGEO | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R3, R4 |
| 1 | 3k TE Connectivity Passive Product | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2 |
| 1 | 10 YAGEO | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5 |
| 1 | 100 YAGEO | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6 |
Show 3 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 100 110 Susumu | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R7, R8 |
| 1 | 0 (100A) Bourns Inc. | R_2512_6332Metric_Pad1.40x3.35mm_HandSolder | R9 |
| 2 | 110 Susumu | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R10, R11 |
Robosub Power design files
The KiCad project lives in the valex2/poseidon repository on GitHub; these links point at the commit this page was built from.
Robosub Power: common questions
How big is the Robosub Power PCB?
The Robosub Power measures 120 × 60 mm, has 2 copper layers and is 1.64592 mm thick.
How many components are on the Robosub Power?
45 components, from 23 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Robosub Power design files?
From the valex2/poseidon repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Robosub Power design in my own project?
The repository has no license, so all rights stay with valex2. Use it as a reference, and ask the author before reusing the design.
More boards in poseidon
 NXP
MLU BreakoutV2
129.3 × 99 mm138 parts4LNo license1
Power ManagementV2
111 × 110.5 mm129 parts2LNo license1
Power Distribution
130 × 61 mm68 parts2LNo license1 NXP
Robosub teensy
120 × 64 mm27 parts4LNo license1
Battery hot swap
34.4 × 88 mm13 parts2LNo license1
Battery hot swap top
35 × 44 mm8 parts2LNo license1