
24RF Remote Control

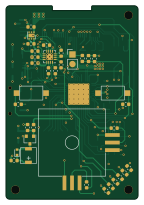
About the 24RF Remote Control PCB
24RF Remote Control is an open source STM32 PCB design by Yongxin-Lu, published on GitHub. It is a 4-layer board measuring 34.9 × 51.2 mm, with 71 components from 40 distinct parts.
Its main chip is the STM32F103CBUx, from the STM32 family. Other key parts include the BQ24075, LP5912, TPD4S012, MPU6050-Sensor_Motion and W25Q128JVS. By type, the board carries 26 capacitors, 23 resistors, 7 ICs, 5 connectors, 4 diodes and 3 switches.
From the project
a stm32 self-balancing car. include pcb board, program and model.
Main components on the 24RF Remote Control
24RF Remote Control bill of materials (BOM)
71 components, 40 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | BQ24075 | QFN-16-1EP_3x3mm_P0.5mm_EP1.7x1.7mm_ThermalVias | U1 |
| 1 | LP5912 | WSON-6-1EP_2x2mm_P0.65mm_EP1x1.6mm | U2 |
| 1 | TPD4S012 | TPD4S012DRYR | U3 |
| 1 | STM32F103CBUx | QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm_ThermalVias | U4 |
| 1 | MPU6050-Sensor_Motion | QFN-24-1EP_4x4mm_P0.5mm_EP2.7x2.7mm | U5 |
| 1 | W25Q128JVS | W25Q128BVEIG | U7 |
| 1 | FJ08K-Joystick | FJ08K | U8 |
| 1 | S8050-Transistor_BJT | SOT-23 | Q1 |
| 1 | 8MHz | Resonator_SMD_muRata_CSTxExxV-3Pin_3.0x1.1mm | Y2 |
| 1 | USB_B_Micro | USB_Micro-B_Molex_47346-0001 | J1 |
| 1 | SWD | JST_SH_BM05B-SRSS-TB_1x05-1MP_P1.00mm_Vertical | J2 |
| 1 | 24RF | ai-thinker_2.4G_NF03_1.27mm | J3 |
| 1 | Conn_01x30 | Hirose_FH12-30S-0.5SH_1x30-1MP_P0.50mm_Horizontal | J4 |
| 1 | BATT_CON | PinHeader_1x02_P2.54mm_Vertical | J5 |
| 1 | Buzzer | MLT-4020 | BZ1 |
| 1 | EG1218 | SW_SPDT_CK-JS102011SAQN | S1 |
| 1 | LEFT | SW_SPST_CK_RS282G05A3 | SW1 |
| 1 | RIGHT | SW_SPST_CK_RS282G05A3 | SW2 |
| 1 | USER | C_0603_1608Metric | D1 |
| 1 | CHG | C_0603_1608Metric | D2 |
Show 20 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | POWER | C_0603_1608Metric | D4 |
| 1 | 1N4148WT | D_SOD-523 | D6 |
| 8 | 1uF | C_0603_1608Metric | C1, C4, C5, C12, C13, C14, C18, C33 |
| 3 | 4.7uF | C_0603_1608Metric | C2, C3, C15 |
| 1 | 10nF | C_0603_1608Metric | C7 |
| 8 | 0.1uF | C_0603_1608Metric | C8, C10, C11, C24, C27, C29, C31, C32 |
| 1 | 2.2nF | C_0603_1608Metric | C9 |
| 1 | 2.2uF | C_0603_1608Metric | C16 |
| 1 | 100uF | CP_EIA-3528-21_Kemet-B | C17 |
| 3 | 100nF | C_0603_1608Metric | C19, C20, C21 |
| 6 | 10k | C_0603_1608Metric | R1, R18, R20, R21, R22, R25 |
| 1 | 15k | C_0603_1608Metric | R2 |
| 2 | 1.5k | C_0603_1608Metric | R3, R8 |
| 1 | 3k | C_0603_1608Metric | R4 |
| 4 | 5.1k | C_0603_1608Metric | R5, R6, R7, R23 |
| 3 | 10R | C_0603_1608Metric | R9, R10, R26 |
| 2 | 4.7k | C_0603_1608Metric | R11, R13 |
| 2 | 10k | R_0603_1608Metric | R12, R14 |
| 1 | 1k | C_0603_1608Metric | R17 |
| 1 | 910K | C_0603_1608Metric | R19 |
24RF Remote Control design files
The KiCad project lives in the Yongxin-Lu/self_balancing_car repository on GitHub; these links point at the commit this page was built from.
24RF Remote Control: common questions
What microcontroller does the 24RF Remote Control use?
The 24RF Remote Control is built around the STM32F103CBUx, from the STM32 family.
How big is the 24RF Remote Control PCB?
The 24RF Remote Control measures 34.9 × 51.2 mm, has 4 copper layers and is 1.2 mm thick.
How many components are on the 24RF Remote Control?
71 components, from 40 distinct parts. The full bill of materials is listed on this page.
Where can I download the 24RF Remote Control design files?
From the Yongxin-Lu/self_balancing_car repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the 24RF Remote Control design in my own project?
The repository has no license, so all rights stay with Yongxin-Lu. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the 24RF Remote Control without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in self_balancing_car
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k