
Smartrover

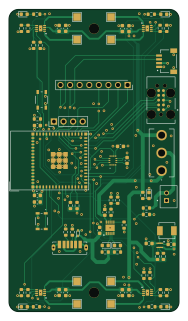
About the Smartrover PCB
Smartrover is an open source ESP32 PCB design by arounamounchili, published on GitHub under the MIT license. It is a 4-layer board measuring 45 × 80 mm, with 74 components from 31 distinct parts.
Its main chip is the ESP32-S3-MINI-1-N8, from the ESP32 family. Other key parts include the MCP73833T-AMI/MF, MP2153GQFU-33-P, A3908EEETR-T and BMI323. By type, the board carries 31 resistors, 17 capacitors, 8 ICs, 8 diodes, 5 connectors and 3 switches.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
ESP32-S3 no_std async Rust (Embassy) teleoperated 4WD mobile robot with embedded FPV web cockpit, 4-layer KiCad PCB, and build123d 3D-printable chassis
4-layer 1.6 mm FR4 carrier board (45 × 80 mm) designed in KiCad 9.0+.
- Schematics (PDF): schematics.pdf - KiCad Project: SmartRover.kicadpro, SmartRover.kicadpcb, and SmartRover.kicadsch linking: - PowerSupply.kicadsch — MCP73833 LiPo charger (IC101), MP2153 3.3 V buck (IC102), USB-C power input (J101), JST-PH battery (J102), SPDT charge/run switch (S101). - Microcontroller.kicadsch — ESP32-S3-MINI-1-N8 (U201), UART header (J201), Tag-Connect JTAG (J202), RESET/BOOT buttons (S201/S202), status LEDs. - SensorActuator.kicadsch — 4× A3908 motor drivers (IC301–IC304), BMI323 IMU (IC305)…
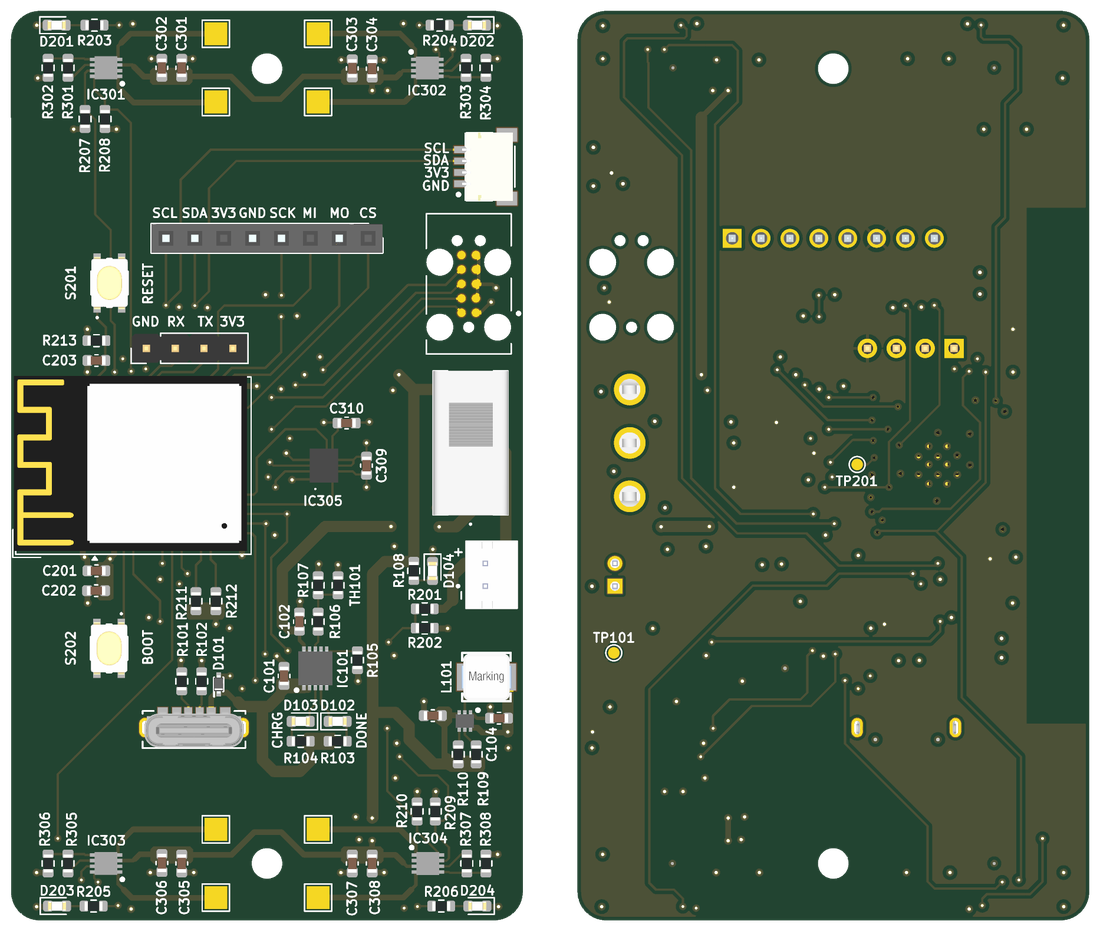
Main components on the Smartrover
Smartrover bill of materials (BOM)
74 components, 31 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MCP73833T-AMI/MF MCP73833T-AMI_MF Microchip Technology | SON50P300X300X100-11N-D | IC101 |
| 1 | MP2153GQFU-33-P Monolithic Power Systems | MP2153GQFU-33-P | IC102 |
| 4 | A3908EEETR-T Allegro MicroSystems | SON50P200X200X60-9N-D | IC301, IC302, IC303, IC304 |
| 1 | BMI323 Bosch Sensortec | BMI323 | IC305 |
| 1 | ESP32-S3-MINI-1-N8 ESP32-S3-MINI-1 Espressif Systems | ESP32-S2-MINI-1 | U201 |
| 1 | 2171780001 Molex | MOLEX_2171780001 | J101 |
| 1 | B2B-PH-K-S JST BATT JST Sales America Inc. | JST_B2B-PH-K-S | J102 |
| 1 | 61300411121 UART Würth Elektronik | PinHeader_1x04_P2.54mm_Vertical | J201 |
| 1 | SLW-108-01-G-S Samtec | SLW-108-01-G-S | J309 |
| 1 | SM04B-SRSS-TB(LF)(SN) SM04B-SRSS-TB_LF__SN_ JST Sales America Inc. | JST_SM04B-SRSS-TB_LF__SN_ | J310 |
| 1 | 500SSP1S1M2QEA E-Switch | 500SSP1S1M2QEA | S101 |
| 2 | PTS810SJK250SMTR LFS PTS810SJK250SMTR_LFS C&K | PTS810SJK250SMTRLFS | S201, S202 |
| 1 | NTCG163JF103HT1 10k TDK Corporation | R_0603_1608Metric | TH101 |
| 1 | TPD1E10B06DYAR Texas Instruments | SODFL1608X77N | D101 |
| 1 | 150060GS75000 Green LED Würth Elektronik | LED_0603_1608Metric | D102 |
| 4 | 150060RS75000 Red LED Würth Elektronik | LED_0603_1608Metric | D103, D104, D203, D204 |
| 2 | IN-S63AT5UW White LED Inolux | LED_0603_1608Metric | D201, D202 |
| 1 | 74437324010 1uH Würth Elektronik | WE-LHMI_4020 | L101 |
| 7 | CL10A106MA8NRNC 10µF,25V Samsung Electro-Mechanics | C_0603_1608Metric | C101, C102, C201, C301, C303, C305, C307 |
| 2 | CL10A226MO7JZNC 22µF,16V Samsung Electro-Mechanics | C_0603_1608Metric | C103, C104 |
Show 11 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 7 | CL10B104KA8WPNC 0.1µF,25V Samsung Electro-Mechanics | C_0603_1608Metric | C202, C302, C304, C306, C308, C309, C310 |
| 1 | CL10B105KO8VPNC 1µF,16V Samsung Electro-Mechanics | C_0603_1608Metric | C203 |
| 2 | ERJ-3EKF5101V 5k1 Panasonic Electronic Components | R_0603_1608Metric | R101, R102 |
| 3 | RC0603FR-07150RL 150 YAGEO | R_0603_1608Metric | R103, R104, R108 |
| 2 | ERA-3AEB132V 1k3 Panasonic Electronic Components | R_0603_1608Metric | R105, R106 |
| 1 | ERJ-PB3B7502V 75k Panasonic Electronic Components | R_0603_1608Metric | R107 |
| 2 | ERJ-3EKF1003V 100k Panasonic Electronic Components | R_0603_1608Metric | R109, R110 |
| 11 | RC1608F103CS 10k Samsung Electro-Mechanics | R_0603_1608Metric | R201, R202, R207, R208, R209, R210, R213, R302 +3 |
| 4 | RC0603FR-07100RL 100 YAGEO | R_0603_1608Metric | R203, R204, R205, R206 |
| 2 | RC1608F222CS 2k2 Samsung Electro-Mechanics | R_0603_1608Metric | R211, R212 |
| 4 | AT0603BRD077K5L 7k5 YAGEO | R_0603_1608Metric | R301, R303, R305, R307 |
Smartrover design files
The KiCad project lives in the arounamounchili/smartrover repository on GitHub; these links point at the commit this page was built from.
Smartrover: common questions
What microcontroller does the Smartrover use?
The Smartrover is built around the ESP32-S3-MINI-1-N8, from the ESP32 family.
How big is the Smartrover PCB?
The Smartrover measures 45 × 80 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Smartrover?
74 components, from 31 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Smartrover design files?
From the arounamounchili/smartrover repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Smartrover design in my own project?
Yes, under the terms of its MIT license, which arounamounchili chose for the repository.
Can I test firmware for the Smartrover without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k