
LSwarm-Anchor

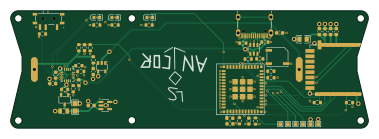
About the LSwarm-Anchor PCB
LSwarm-Anchor is an open source ESP32 PCB design by DerpyDoggo11, published on GitHub. It is a 4-layer board measuring 94.5 × 31 mm, with 52 components from 28 distinct parts.
Its main chip is the ESP32-C3-MINI-1U-N4, from the ESP32 family. Other key parts include the BQ24075RGTR, BU03, DW03C and AP2112K-3.3. By type, the board carries 21 resistors, 16 capacitors, 5 ICs, 3 LEDs, 1 transistor and 1 battery holder.
It belongs with the robotics & motion, rf & radio and iot & wireless designs in this gallery.
From the project
I have not physically tested this device yet, but typically UWB modules can have a range of up to 100 meters or around 300 feet, which is more than enough for many applications. Also, UWB frequenceis can work through walls, but it may be less accurate or cause desyncing with the
I have not physically tested this device yet, but typically UWB modules can have a range of up to 100 meters or around 300 feet, which is more than enough for many applications. Also, UWB frequenceis can work through walls, but it may be less accurate or cause desyncing with the drone.
Note: These anchors do not actively run the computations to position the drones, you must also have a dedicated ground station with wifi such as a Raspbbery PI Zero 2 W for computing.
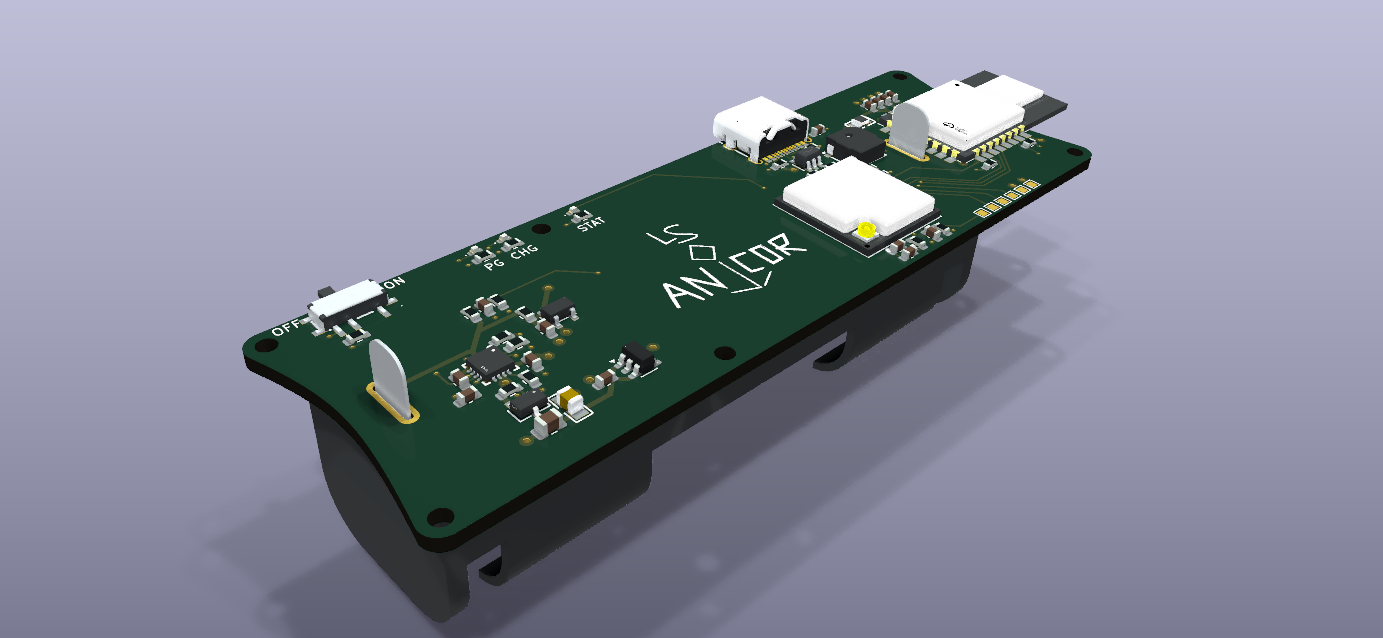
Main components on the LSwarm-Anchor
LSwarm-Anchor bill of materials (BOM)
52 components, 28 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | BQ24075RGTR TI(德州仪器) | QFN-16_L3.0-W3.0-P0.50-TL-EP1.7 | U1 |
| 1 | BU03 Ai-Thinker(安信可) | WIRELM-SMD_BU03 | U2 |
| 1 | DW03C DW03C_C41367942 PJSEMI(平晶微) | SOT-23-5_L2.9-W1.6-P0.95-LS2.9-BL | U4 |
| 1 | ESP32-C3-MINI-1U-N4 ESPRESSIF(乐鑫) | WIFIM-SMD_61P-L13.2-W12.5-P0.80 | U6 |
| 1 | AP2112K-3.3 | SOT-23-5 | U12 |
| 1 | AO3407A AOS | SOT-23-3_L2.9-W1.6-P1.90-LS2.8-BR | Q7 |
| 1 | BH-18650-A1AJ006 MYOUNG(美阳) | BAT-TH_BH-18650-A1AJ006 | BT1 |
| 1 | MLT-5020 华能 | BUZ-SMD_L5.0-W5.5-P4.60 | BUZZER2 |
| 1 | MSK12C02 SHOU HAN(首韩) | SW-TH_MSK12C02 | SW1 |
| 1 | USB-TYPE-C-018 DEALON(德艺隆) | USB-C_SMD-TYPE-C-31-M-12 | USB1 |
| 3 | KT-0603R KENTO | LED-SMD_L1.6-W0.8-R-RD | LED4, LED5, LED6 |
| 1 | USBLC6-2SC6 USBLC6-2SC6_C2687116 UMW(友台半导体) | SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | D5 |
| 1 | MPZ2012S601AT000 TDK | L0805 | L1 |
| 1 | CL21A226MAQNNNE SAMSUNG(三星) | C0805 | C1 |
| 1 | 10NF 10nF | C_0603_1608Metric | C27 |
| 5 | 1UF 1uF | C_0603_1608Metric | C31, C32, C41, C52, C65 |
| 3 | 10UF 10uF | C_0603_1608Metric | C40, C55, C62 |
| 5 | 100NF 100nf | C_0603_1608Metric | C56, C58, C59, C61, C71 |
| 1 | 10uF | C_0805_2012Metric | C71C1 |
| 4 | 1k | R_0603_1608Metric | R9, R21, R24, R29 |
Show 8 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 1.5k | R_0603_1608Metric | R11 |
| 6 | 10k | R_0603_1608Metric | R12, R18, R23, R32, R33, R39 |
| 1 | 470 | R_0603_1608Metric | R16 |
| 2 | 220k | R_0603_1608Metric | R25, R26 |
| 1 | 100 | R_0603_1608Metric | R27 |
| 2 | 100k | R_0603_1608Metric | R28, R40 |
| 2 | 5.1k | R_0603_1608Metric | R34, R37 |
| 2 | 27 | R_0603_1608Metric | R35, R36 |
LSwarm-Anchor design files
The KiCad project lives in the DerpyDoggo11/LSwarm-Anchor repository on GitHub; these links point at the commit this page was built from.
LSwarm-Anchor: common questions
What microcontroller does the LSwarm-Anchor use?
The LSwarm-Anchor is built around the ESP32-C3-MINI-1U-N4, from the ESP32 family.
How big is the LSwarm-Anchor PCB?
The LSwarm-Anchor measures 94.5 × 31 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the LSwarm-Anchor?
52 components, from 28 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the LSwarm-Anchor design files?
From the DerpyDoggo11/LSwarm-Anchor repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the LSwarm-Anchor design in my own project?
The repository has no license, so all rights stay with DerpyDoggo11. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the LSwarm-Anchor without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k