
ROBarm

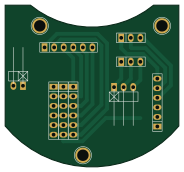
About the ROBarm PCB
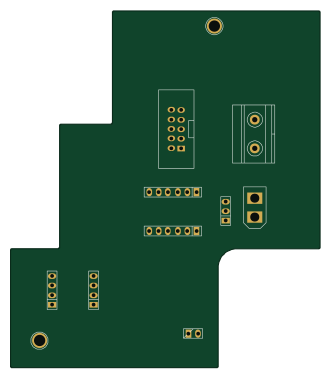
ROBarm is an open source PCB design by dodotronix, published on GitHub. It is a 2-layer board measuring 46 × 42.8 mm, with 11 components from 6 distinct parts.
By type, the board carries 6 connectors, 3 relays, 1 diode and 1 resistor.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
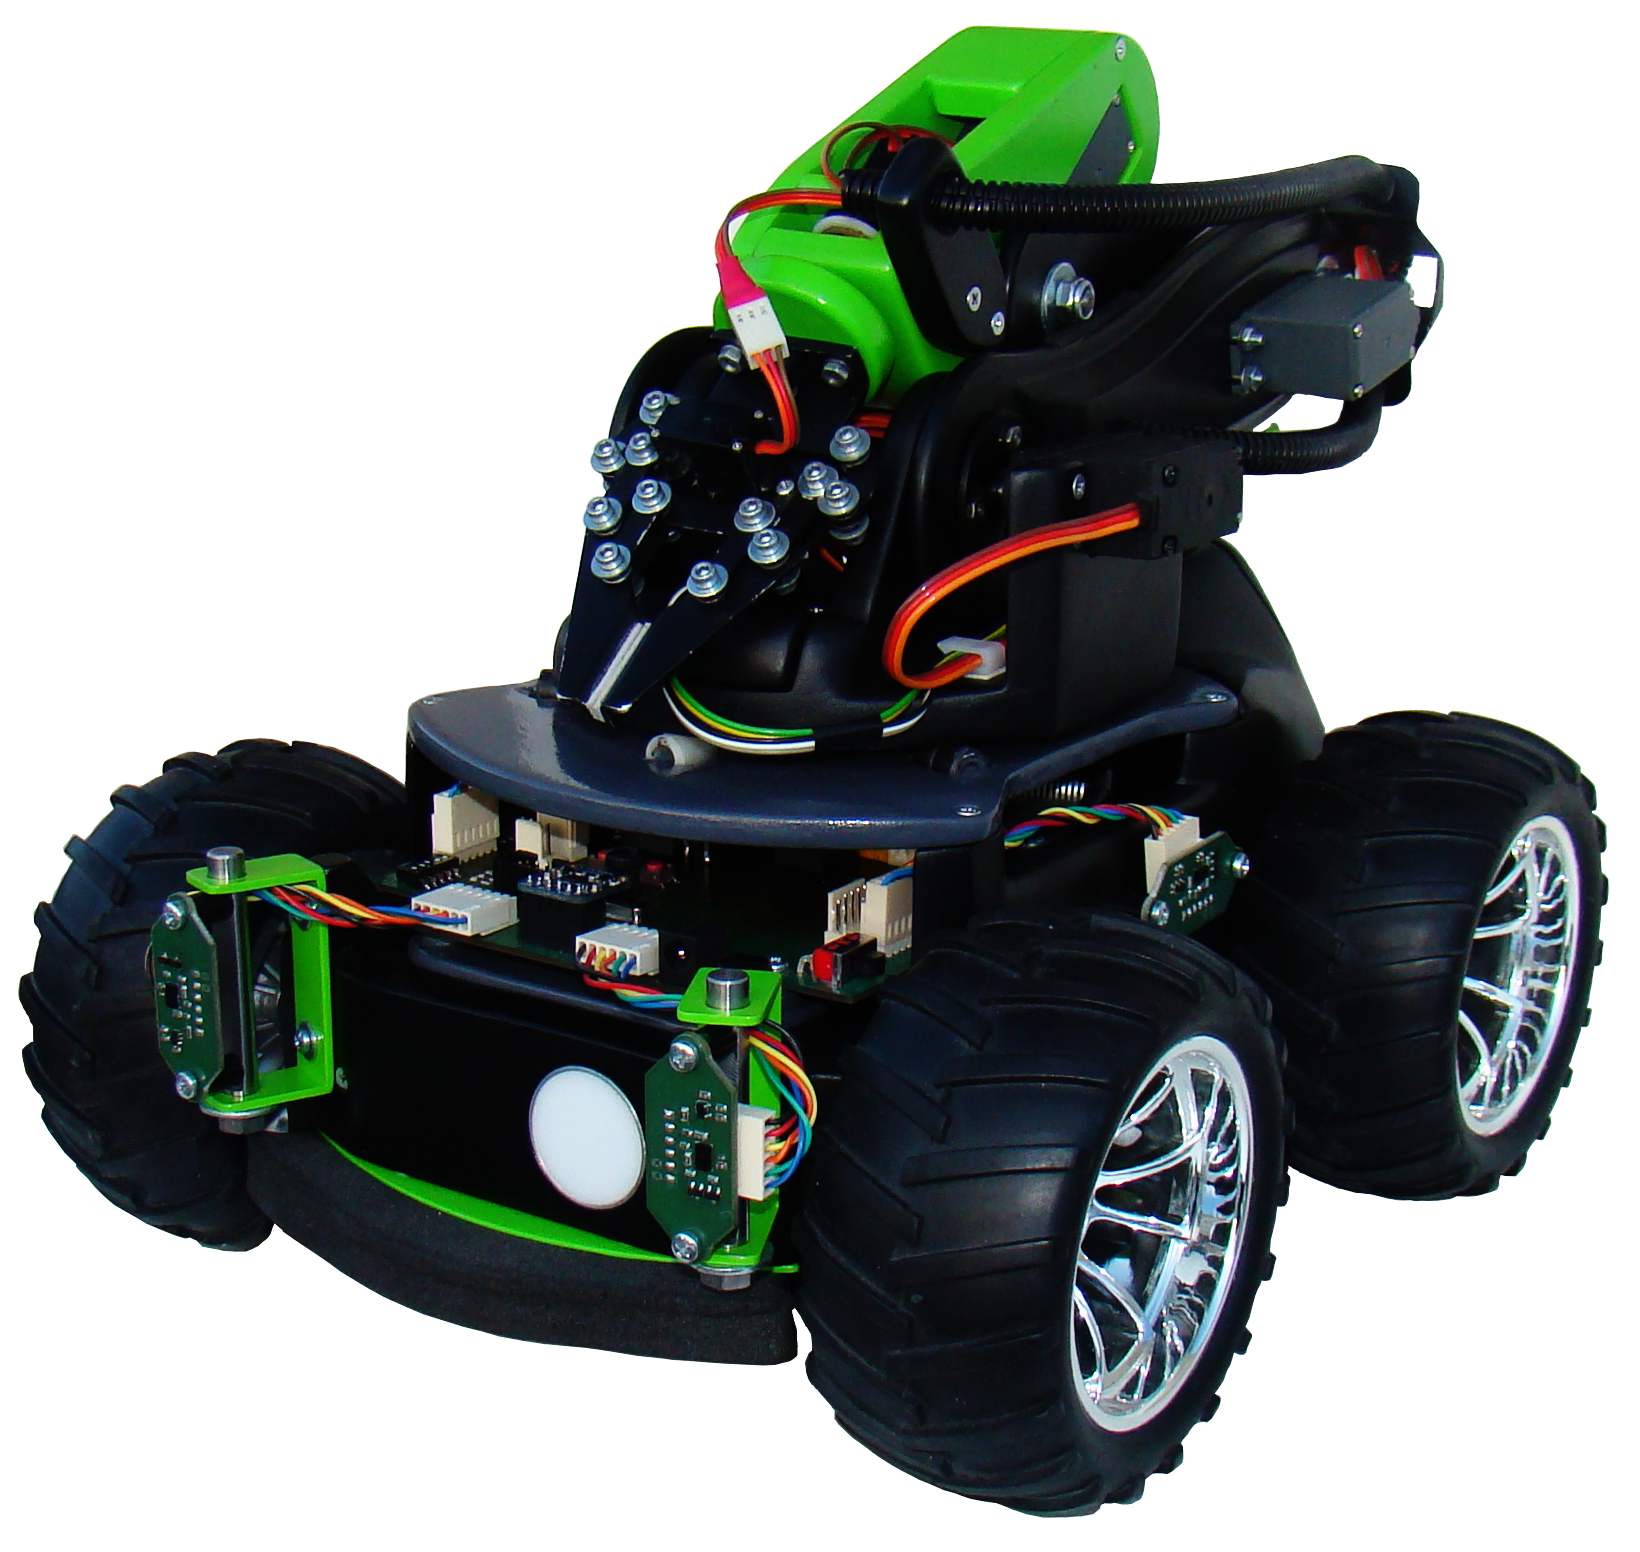
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features
ROBarm bill of materials (BOM)
11 components, 6 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | CONN_2 | pin_strip_2-90 | P1 |
| 5 | CONN_6 | pin_strip_6 | P2, P3, P4, P5, P6 |
| 1 | CONN_3 | pin_strip_3-90 | K1 |
| 2 | CONN_3 | pin_strip_3 | K2, K3 |
| 1 | LED | Led_0603 | D1 |
| 1 | R | SM0805 | R1 |
ROBarm design files
The KiCad project lives in the dodotronix/RobotClaire repository on GitHub; these links point at the commit this page was built from.
ROBarm: common questions
How big is the ROBarm PCB?
The ROBarm measures 46 × 42.8 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the ROBarm?
11 components, from 6 distinct parts. The full bill of materials is listed on this page.
Where can I download the ROBarm design files?
From the dodotronix/RobotClaire repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the ROBarm design in my own project?
The repository has no license, so all rights stay with dodotronix. Use it as a reference, and ask the author before reusing the design.
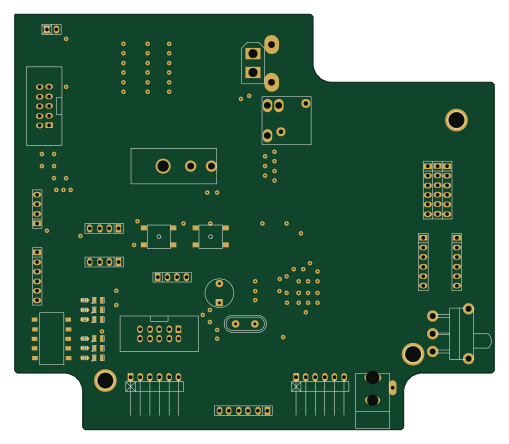
More boards in RobotClaire
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k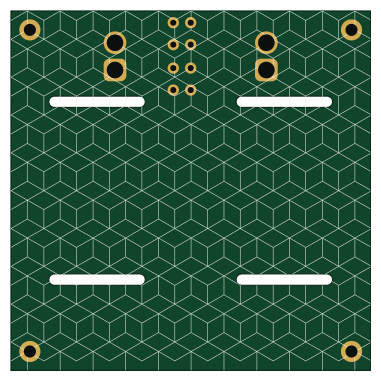
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k