
Robot motherboard

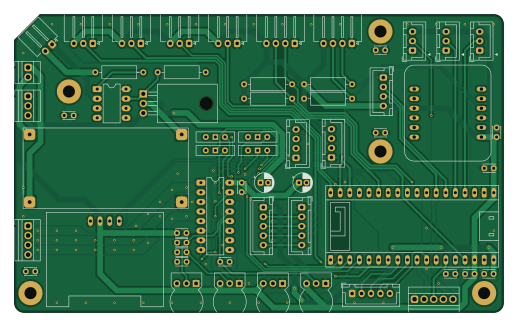
About the Robot motherboard PCB
Robot motherboard is an open source RP2040/RP2350 PCB design by enph253-2025-team5, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 129.3 × 78.7 mm, with 58 components from 39 distinct parts.
Its main chip is the ESP32_PICO-1, from the RP2040/RP2350 family. Other key parts include the MCT6, LM2596_BREAKOUT, CD4051B and BNO085. By type, the board carries 20 connectors, 17 capacitors, 6 resistors, 5 ICs, 4 switches and 1 transistor.
It belongs with the robotics & motion designs in this gallery.
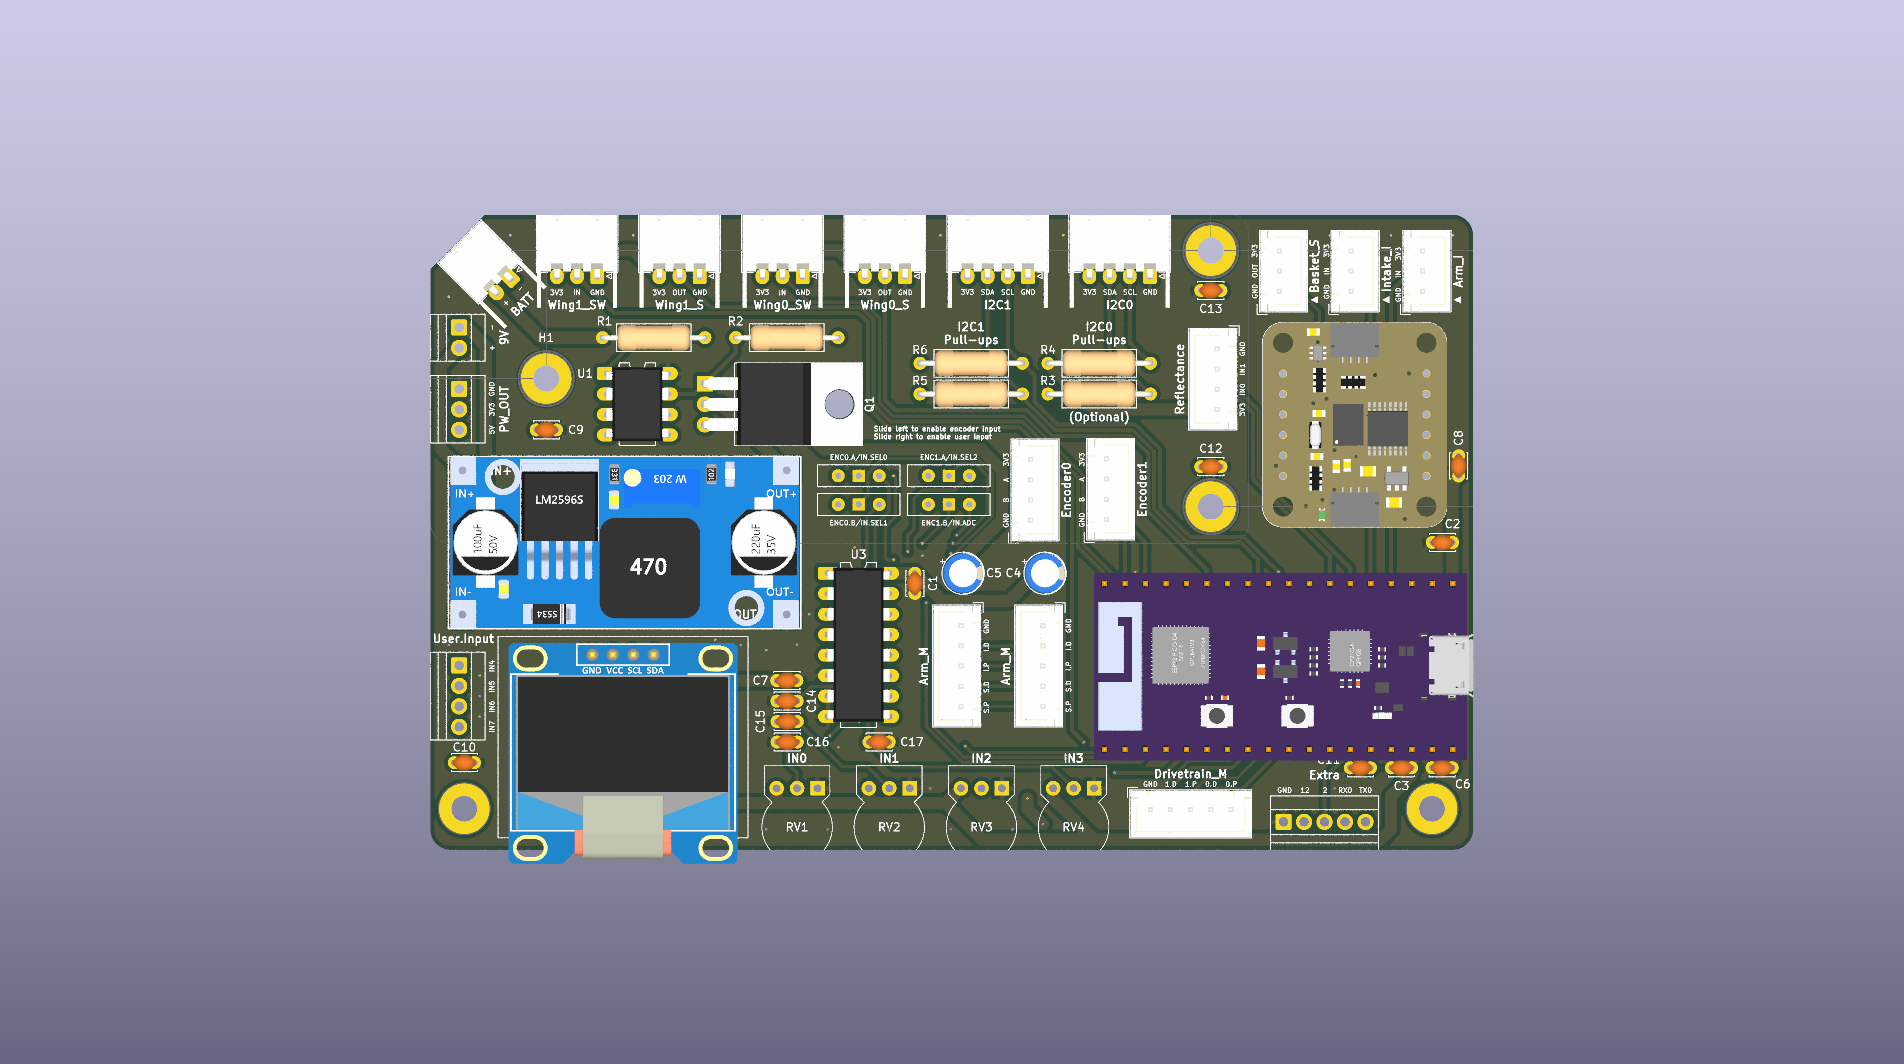
Main components on the Robot motherboard
Robot motherboard bill of materials (BOM)
58 components, 39 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MCT6 | DIP-8_W7.62mm_LongPads | U1 |
| 1 | LM2596_BREAKOUT LM2596_Breakout | LM2596_Breakout | U2 |
| 1 | CD4051B | DIP-16_W7.62mm_LongPads | U3 |
| 1 | ESP32_PICO-1 | ESP32_PICO_1_DEV_KIT | U4 |
| 1 | BNO085 | ADAFRUIT_BNO085 | U5 |
| 1 | IRFZ44 | TO-220-3_Horizontal_TabDown | Q1 |
| 1 | WING0_S Wing0_S | JST_XH_S3B-XH-A-1_1x03_P2.50mm_Horizontal | J1 |
| 1 | WING0_SW Wing0_SW | JST_XH_S3B-XH-A-1_1x03_P2.50mm_Horizontal | J2 |
| 1 | BATT | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J3 |
| 1 | WING1_S Wing1_S | JST_XH_S3B-XH-A-1_1x03_P2.50mm_Horizontal | J4 |
| 1 | WING1_SW Wing1_SW | JST_XH_S3B-XH-A-1_1x03_P2.50mm_Horizontal | J5 |
| 1 | 9V | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J6 |
| 1 | Drivetrain_M | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J7 |
| 2 | Arm_M | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J8, J9 |
| 1 | Reflectance | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J10 |
| 1 | Arm_I | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J11 |
| 1 | Intake_I | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J12 |
| 1 | User.Input | TerminalBlock_Xinya_XY308-2.54-4P_1x04_P2.54mm_Horizontal | J13 |
| 1 | I2C0 | JST_XH_S4B-XH-A-1_1x04_P2.50mm_Horizontal | J14 |
| 1 | Extra | TerminalBlock_Xinya_XY308-2.54-5P_1x05_P2.54mm_Horizontal | J15 |
Show 19 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | I2C1 | JST_XH_S4B-XH-A-1_1x04_P2.50mm_Horizontal | J16 |
| 1 | PW_OUT | TerminalBlock_Xinya_XY308-2.54-3P_1x03_P2.54mm_Horizontal | J17 |
| 1 | ENCODER1 Encoder1 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J18 |
| 1 | Basket_S | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J19 |
| 1 | ENCODER0 Encoder0 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J20 |
| 1 | IN0 | ENPH253_Potentiometer | RV1 |
| 1 | IN1 | ENPH253_Potentiometer | RV2 |
| 1 | IN2 | ENPH253_Potentiometer | RV3 |
| 1 | IN3 | ENPH253_Potentiometer | RV4 |
| 1 | ENC0.A/IN.SEL0 | SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mm | SW1 |
| 1 | ENC0.B/IN.SEL1 | SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mm | SW2 |
| 1 | ENC1.A/IN.SEL2 | SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mm | SW3 |
| 1 | ENC1.B/IN.ADC | SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mm | SW4 |
| 1 | SSD1306_OLED | ADAFRUIT_SSD1306_OLED | G1 |
| 15 | 100NF 100nF | C_Disc_D3.0mm_W2.0mm_P2.50mm | C1, C2, C3, C6, C7, C8, C9, C10 +7 |
| 2 | 47UF 47uF | CP_Radial_D5.0mm_P2.00mm | C4, C5 |
| 1 | 470R | R_Axial_DIN0309_L9.0mm_D3.2mm_P12.70mm_Horizontal | R1 |
| 1 | 10K | R_Axial_DIN0309_L9.0mm_D3.2mm_P12.70mm_Horizontal | R2 |
| 4 | 4K7 4k7 | R_Axial_DIN0309_L9.0mm_D3.2mm_P12.70mm_Horizontal | R3, R4, R5, R6 |
Robot motherboard design files
The KiCad project lives in the enph253-2025-team5/robot-motherboard-pcb repository on GitHub; these links point at the commit this page was built from.
Robot motherboard: common questions
What microcontroller does the Robot motherboard use?
The Robot motherboard is built around the ESP32_PICO-1, from the RP2040/RP2350 family.
How big is the Robot motherboard PCB?
The Robot motherboard measures 129.3 × 78.7 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot motherboard?
58 components, from 39 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Robot motherboard design files?
From the enph253-2025-team5/robot-motherboard-pcb repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Robot motherboard design in my own project?
Yes, under the terms of its GPL-3.0 license, which enph253-2025-team5 chose for the repository.
Can I test firmware for the Robot motherboard without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
LogicAnalyzer
gusmanb
57 × 55.2 mm6 parts2LGPL-3.05.0k RP2040/RP2350
Jitx design
55.5 × 65 mm26 parts4LGPL-3.05.0k RP2040/RP2350
Main
google
98 × 71 mm102 parts2LApache-2.02.9k