
Smart Posture Corrector

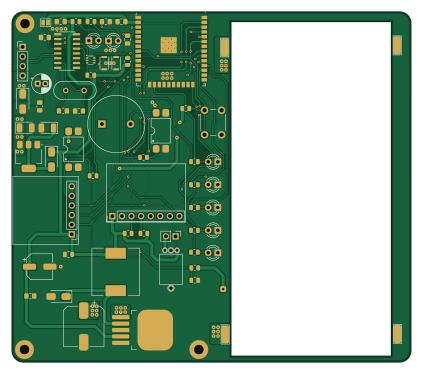
About the Smart Posture Corrector PCB
Smart Posture Corrector is an open source ESP32 PCB design by jsitech4, published on GitHub. It is a 2-layer board measuring 105.6 × 92.7 mm, with 64 components from 54 distinct parts.
Its main chip is the ESP32-WROOM, from the ESP32 family. Other key parts include the LM2596S-3.3V, LM2596S-12V and LM2596S-5V. By type, the board carries 16 resistors, 15 capacitors, 10 diodes, 8 connectors, 4 ICs and 3 switches.
It belongs with the sensors designs in this gallery.
From the project
This project is a modular Smart Posture Corrector System built around the ESP32-WROOM-32 using a structured PlatformIO architecture.
This project is a modular Smart Posture Corrector System built around the ESP32-WROOM-32 using a structured PlatformIO architecture.
The system monitors the user posture orientation using the MPU6050 gyroscope and accelerometer sensor and intelligently detects bad posture based on a calibrated body reference angle.
When poor posture is maintained for a configured duration, the system activates:
Main components on the Smart Posture Corrector
Smart Posture Corrector bill of materials (BOM)
64 components, 54 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LM2596S-3.3V | TO-263-5_TabPin6 | U1 |
| 1 | LM2596S-12V AMS1117-3.3 | SOT-223-3_TabPin2 | U2 |
| 1 | ESP32-WROOM | ESP32-WROOM-32 | U3 |
| 1 | LM2596S-5V CH340C | SOIC-16_3.9x9.9mm_P1.27mm | U4 |
| 1 | Motor_DC | PinHeader_1x02_P2.54mm_Vertical | M1 |
| 1 | UMH3N | SOT-363_SC-70-6 | Q1 |
| 1 | 12MHZ 12MHz | Crystal_HC49-4H_Vertical | Y1 |
| 1 | MPU6050 | PinHeader_1x08_P2.54mm_Vertical | J1 |
| 1 | +IN | TestPoint_Keystone_5015_Micro_Mini | J5 |
| 1 | -IN | TestPoint_Keystone_5015_Micro_Mini | J6 |
| 1 | +5V | TestPoint_Keystone_5015_Micro_Mini | J9 |
| 1 | -5V | TestPoint_Keystone_5015_Micro_Mini | J10 |
| 1 | USB_C Conn | PinHeader_1x04_P2.54mm_Vertical | J11 |
| 1 | SD MODULE | PinHeader_1x06_P2.54mm_Vertical | J15 |
| 1 | BSENS | SolderWire-0.1sqmm_1x01_D0.4mm_OD1mm | J24 |
| 1 | Buzzer | Buzzer_15x7.5RM7.6 | BZ1 |
| 1 | ~ | SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1 |
| 2 | PC817XFP PC817XI | SMDIP-4_W9.53mm | OC1, OC2 |
| 1 | SW_Push | SW_PUSH_6mm_H13mm | SW1 |
| 1 | SPST_CK_KXT3 RESET | SW_SPST_CK_KXT3 | SW2 |
Show 34 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SPST_CK_KXT3 FLASH | SW_SPST_CK_KXT3 | SW3 |
| 2 | 1N5819 | D_SMA | D1, D4 |
| 1 | 1N5824 | D_SMA | D2 |
| 1 | 1N5824 Red | LED_D3.0mm | D3 |
| 3 | SM4001 Red | LED_D3.0mm | D5, D7, D10 |
| 1 | SM4001 Green | LED_D3.0mm | D6 |
| 2 | Red | LED_D3.0mm | D8, D9 |
| 1 | 33UH 33uH | L_12x12mm_H6mm | L1 |
| 1 | 680UF/35V 104 | C_0805_2012Metric | C1 |
| 2 | 680UF/35V 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C7 |
| 1 | 470NF 680uF_35V | CP_Elec_10x12.5 | C3 |
| 1 | 100NF 4.7uF/16V | CP_EIA-3528-21_Kemet-B_HandSolder | C4 |
| 1 | 220UF/16V 470nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5 |
| 1 | 220UF/16V 10uF_16V | CP_Radial_D5.0mm_P2.00mm | C6 |
| 1 | 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8 |
| 1 | 2200UF/35V 4.7uF/16V | CP_EIA-3528-21_Kemet-B_HandSolder | C9 |
| 1 | 2200UF/35V 220uF_16V | CP_Elec_6.3x7.7 | C10 |
| 1 | 220UF/16V 22pF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C11 |
| 1 | 100NF 22pF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C12 |
| 1 | 100NF 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C13 |
| 1 | 470UF/25V 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C14 |
| 1 | 4.7UF/16V 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C15 |
| 1 | 680K 10k | R_0805_2012Metric | R1 |
| 1 | 680K 20k | R_0805_2012Metric | R2 |
| 1 | 100K 10k | R_0805_2012Metric | R3 |
| 3 | 330R | R_0805_2012Metric | R4, R5, R8 |
| 2 | 330R | R_0805_2012Metric | R6, R19 |
| 1 | 680K 330R | R_0805_2012Metric | R7 |
| 1 | 330R 10k | R_0805_2012Metric | R11 |
| 1 | 10k | R_0805_2012Metric | R13 |
| 1 | 330R/2W 10k | R_0805_2012Metric | R14 |
| 2 | 10K 10k | R_0805_2012Metric | R15, R17 |
| 1 | 10K 330R | R_0805_2012Metric | R16 |
| 1 | 150R 330R | R_0805_2012Metric | R18 |
Smart Posture Corrector design files
The KiCad project lives in the jsitech4/Projects repository on GitHub; these links point at the commit this page was built from.
Smart Posture Corrector: common questions
What microcontroller does the Smart Posture Corrector use?
The Smart Posture Corrector is built around the ESP32-WROOM, from the ESP32 family.
How big is the Smart Posture Corrector PCB?
The Smart Posture Corrector measures 105.6 × 92.7 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Smart Posture Corrector?
64 components, from 54 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Smart Posture Corrector design files?
From the jsitech4/Projects repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Smart Posture Corrector design in my own project?
The repository has no license, so all rights stay with jsitech4. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Smart Posture Corrector without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in Projects
 ESP32
Load Demand Response System
198.1 × 130.8 mm133 parts4LNo license0 ESP32
Smart Home Energy Management System
198.1 × 130.8 mm133 parts4LNo license0 ESP32
Smart Hybrid IOT energy management System
198.1 × 130.8 mm133 parts4LNo license0 ESP32
Solar Powered Egg Incubator
100 × 90.1 mm100 parts2LNo license0 ESP32
Predictive Maintenance System for Industrial Motor
108.8 × 83.6 mm81 parts2LNo license0 ESP32
Smart Transformer Health Monitoring System
108.8 × 83.6 mm81 parts2LNo license0 ESP32
Dual Axis Solar Tracker
101.2 × 76.6 mm75 parts2LNo license0 ESP32
Solar Powered Irrigation System
91.6 × 57.8 mm70 parts2LNo license0 ESP32
Motion Detection and Alarm Mesh System
67.3 × 100 mm59 parts2LNo license0 ESP32
Water Level Monitor and Control
88.6 × 88.7 mm51 parts2LNo license0 ESP32
NFC Card Payment System
97.8 × 137.6 mm41 parts2LNo license0
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k