
Sensory Adaptation Robot

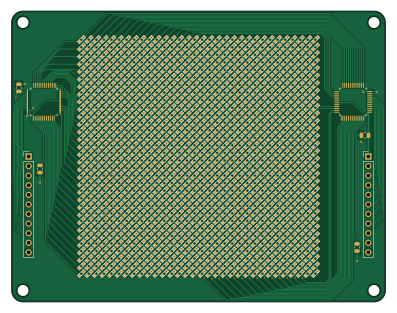
About the Sensory Adaptation Robot PCB
Sensory Adaptation Robot is an open source PCB design by lachlanchen, published on GitHub. It is a 2-layer board measuring 99 × 77 mm, with 1032 components from 5 distinct parts.
Other key parts include the ADG732. By type, the board carries 1024 transistors, 4 capacitors, 2 ICs and 2 connectors.
It belongs with the robotics & motion, test & measurement and science & space designs in this gallery.
From the project
HybridImager: open hybrid single-pixel, event, frame, and spectral scientific imaging research workspace
If you're reading this, it means I have started a new project but have neglected to update the README file. Please notify me of this by any means possible.
Twitter: @idlehandsdev Instagram: @idlehandsdev
Since you're reading this, go check out my YouTube Channel! http://youtube.com/seanhodginsfilms
Main components on the Sensory Adaptation Robot
Sensory Adaptation Robot bill of materials (BOM)
1032 components, 5 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | ADG732 | TQFP-48_7x7mm_P0.5mm | U1, U2 |
| 1024 | ALS-PT19 | ALS-PT19 | Q1, Q2, Q3, Q4, Q5, Q6, Q7, Q8 +1016 |
| 1 | ROW | PinHeader_1x11_P2.54mm_Vertical | J1 |
| 1 | COL | PinHeader_1x11_P2.54mm_Vertical | J2 |
| 4 | 0.1uF | C_0805_2012Metric | C1, C2, C3, C4 |
Sensory Adaptation Robot design files
The KiCad project lives in the lachlanchen/HybridImager repository on GitHub; these links point at the commit this page was built from.
Sensory Adaptation Robot: common questions
How big is the Sensory Adaptation Robot PCB?
The Sensory Adaptation Robot measures 99 × 77 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Sensory Adaptation Robot?
1032 components, from 5 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Sensory Adaptation Robot design files?
From the lachlanchen/HybridImager repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Sensory Adaptation Robot design in my own project?
The repository has no license, so all rights stay with lachlanchen. Use it as a reference, and ask the author before reusing the design.
More boards in HybridImager
Similar boards
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Rp2040 encoder
Twisted-Fields
36.7 × 33.3 mm10 parts2LCustom license417
DB9 High-Low Signal Generator
nanographs
47 × 30 mm10 parts2LNo license370
VESC Controller
paltatech
160 × 90 mm908 parts2LNo license354
OneInchEye
will127534
39 × 39 mm79 parts4LMIT346
${BOARD NAME} Assembly
EPFLXplore
45 × 43.5 mm21 parts4LApache-2.0345