
AI.R-Autonomous Robot

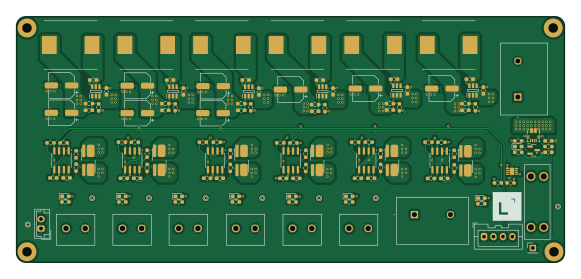
About the AI.R-Autonomous Robot PCB
AI.R-Autonomous Robot is an open source PCB design by Lapland-Robotics, published on GitHub under the MIT license. It is a 6-layer board measuring 145 × 65 mm, with 144 components from 38 distinct parts.
Other key parts include the STS30-DIS, ACS711xEXLT-31AB and INA219AxD. By type, the board carries 54 resistors, 41 capacitors, 12 connectors, 8 ICs, 8 test points and 8 diodes.
It belongs with the robotics & motion, power & battery and sensors designs in this gallery.
From the project
ROS2‑based platform designed to streamline the development and deployment of autonomous mobile robots.
The Universal Power Distribution PCB (UDP-PCB) provides the possibility for quick and easy power distribution in any robotics or electronics project ensuring maximum efficiency. A single battery can provide power to 6 different voltage rails with their respective voltage levels (24V, 19V, 16V, 12V, 12V, 5V). Each stage can supply up to 3.5 Amps continuously with a max voltage input of 60V.
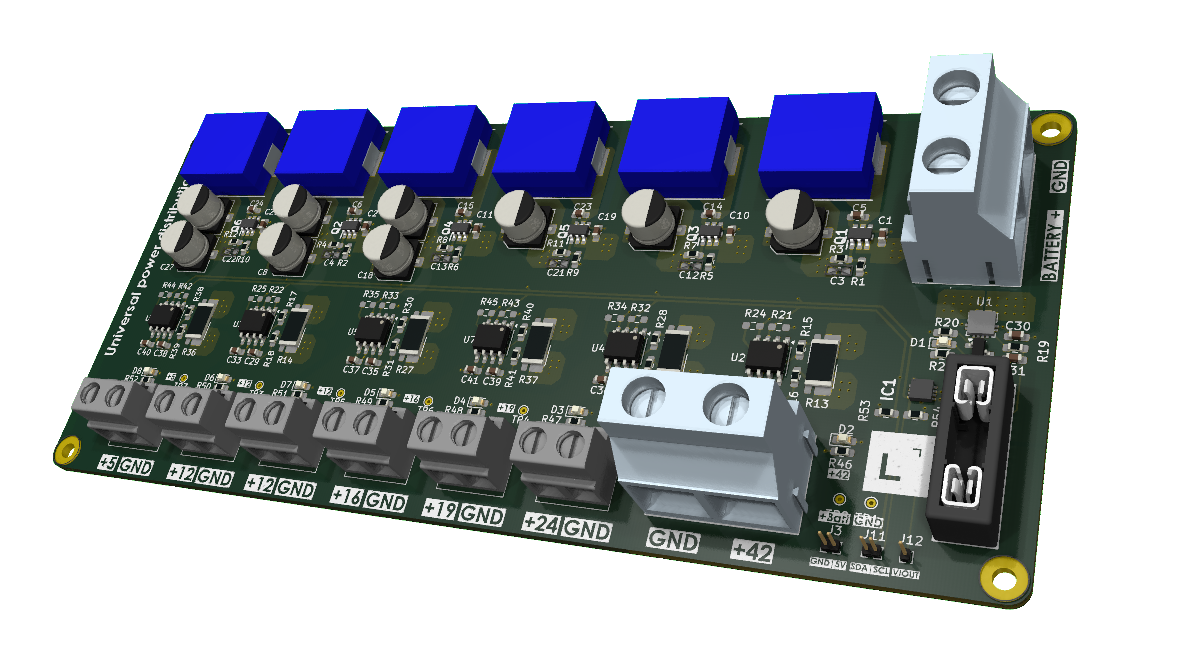
Main components on the AI.R-Autonomous Robot
AI.R-Autonomous Robot bill of materials (BOM)
144 components, 38 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STS30-DIS | SON50P250X250X100-9N-D | IC1 |
| 1 | ACS711xEXLT-31AB | Allegro_QFN-12-10-1EP_3x3mm_P0.5mm | U1 |
| 6 | INA219AxD | SOIC-8_3.9x4.9mm_P1.27mm | U2, U3, U4, U5, U6, U7 |
| 6 | LMR51635XDDCR | SOT95P280X110-6N | Q1, Q2, Q3, Q4, Q5, Q6 |
| 1 | BSS84 | SOT-23 | Q7 |
| 1 | 3557-2 25A Fuse holder | 3557-2 | J1 |
| 2 | 796739-2 | 7967392 | J2, J10 |
| 1 | Conn_01x02 | JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J3 |
| 6 | 1776119-2 | 17761192 | J4, J5, J6, J7, J8, J9 |
| 1 | Conn_01x04 | JST_XA_B04B-XASK-1_1x04_P2.50mm_Vertical | J11 |
| 1 | Conn_01x01 | PinHeader_1x01_P2.54mm_Vertical | J12 |
| 8 | TestPoint | TestPoint_THTPad_D1.0mm_Drill0.5mm | TP1, TP2, TP3, TP4, TP5, TP6, TP7, TP8 |
| 8 | LED | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1, D2, D3, D4, D5, D6, D7, D8 |
| 3 | PA4343.153NLT 33µH | INDPM140128X650N | L1, L3, L5 |
| 2 | PA4343.153NLT 22µH | INDPM140128X650N | L2, L4 |
| 1 | PA4343.153NLT 15µH | INDPM140128X650N | L6 |
| 6 | 2.2µF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1, C2, C10, C11, C19, C20 |
| 6 | DNP | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C3, C4, C12, C13, C21, C22 |
| 20 | 0.1µF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C5, C6, C14, C15, C23, C24, C28, C29 +12 |
| 5 | 22µF | CP_Elec_6.3x5.8 | C7, C9, C16, C18, C25 |
Show 18 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 10µF | CP_Elec_6.3x5.8 | C8, C17 |
| 2 | 33µF | CP_Elec_6.3x5.8 | C26, C27 |
| 6 | 10k2 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2, R5, R6, R9, R10 |
| 1 | 295k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3 |
| 2 | 143k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R4, R8 |
| 1 | 232k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R7 |
| 1 | 194k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R11 |
| 1 | 53k5 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R12 |
| 6 | 0.1R | R_shunt_different_pad_layout | R13, R14, R26, R27, R36, R37 |
| 12 | R50 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R15, R16, R17, R18, R28, R29, R30, R31 +4 |
| 1 | 0R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R19 |
| 2 | 1k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R20, R50 |
| 14 | 10k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R21, R22, R24, R25, R32, R33, R34, R35 +6 |
| 3 | 330 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R23, R51, R52 |
| 1 | 4k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R46 |
| 1 | 2.2k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R47 |
| 1 | 1.8k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R48 |
| 1 | 1.4k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R49 |
AI.R-Autonomous Robot design files
The KiCad project lives in the Lapland-Robotics/AI.R-Autonomous_Robot repository on GitHub; these links point at the commit this page was built from.
AI.R-Autonomous Robot: common questions
How big is the AI.R-Autonomous Robot PCB?
The AI.R-Autonomous Robot measures 145 × 65 mm, has 6 copper layers and is 1.66 mm thick.
How many components are on the AI.R-Autonomous Robot?
144 components, from 38 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the AI.R-Autonomous Robot design files?
From the Lapland-Robotics/AI.R-Autonomous_Robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the AI.R-Autonomous Robot design in my own project?
Yes, under the terms of its MIT license, which Lapland-Robotics chose for the repository.
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Display Carrier
AxxAxx
35.6 × 58.2 mm5 parts2LGPL-3.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k