
Puck

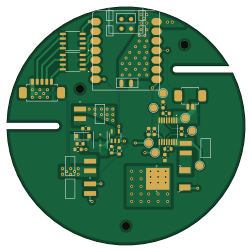
About the Puck PCB
Puck is an open source RP2040/RP2350 PCB design by oist, published on GitHub under the Apache-2.0 license. It is a 2-layer board measuring 63 × 62.9 mm, with 24 components from 20 distinct parts.
Its main chip is the RP2040, from the RP2040/RP2350 family. Other key parts include the NCP1117ST33T3G and SeeeduinoXIAO. By type, the board carries 7 capacitors, 4 test points, 3 ICs, 3 transistors, 3 resistors and 2 connectors.
It belongs with the robotics & motion designs in this gallery.
From the project
All 3D CAD and PCB design files for smartphone-robot project.
The most recent version was created in Kicad v7 so be sure to use that when opening the project else you may run into compatibility issues.
Note this repo uses a central library management system. Symbols, footprints, and models are maintained on a personal fork of the central kicad library repos. These forks are maintained as submodules within the kicad-symbols, kicad-footprints, and kicad-packages3D respectively under:
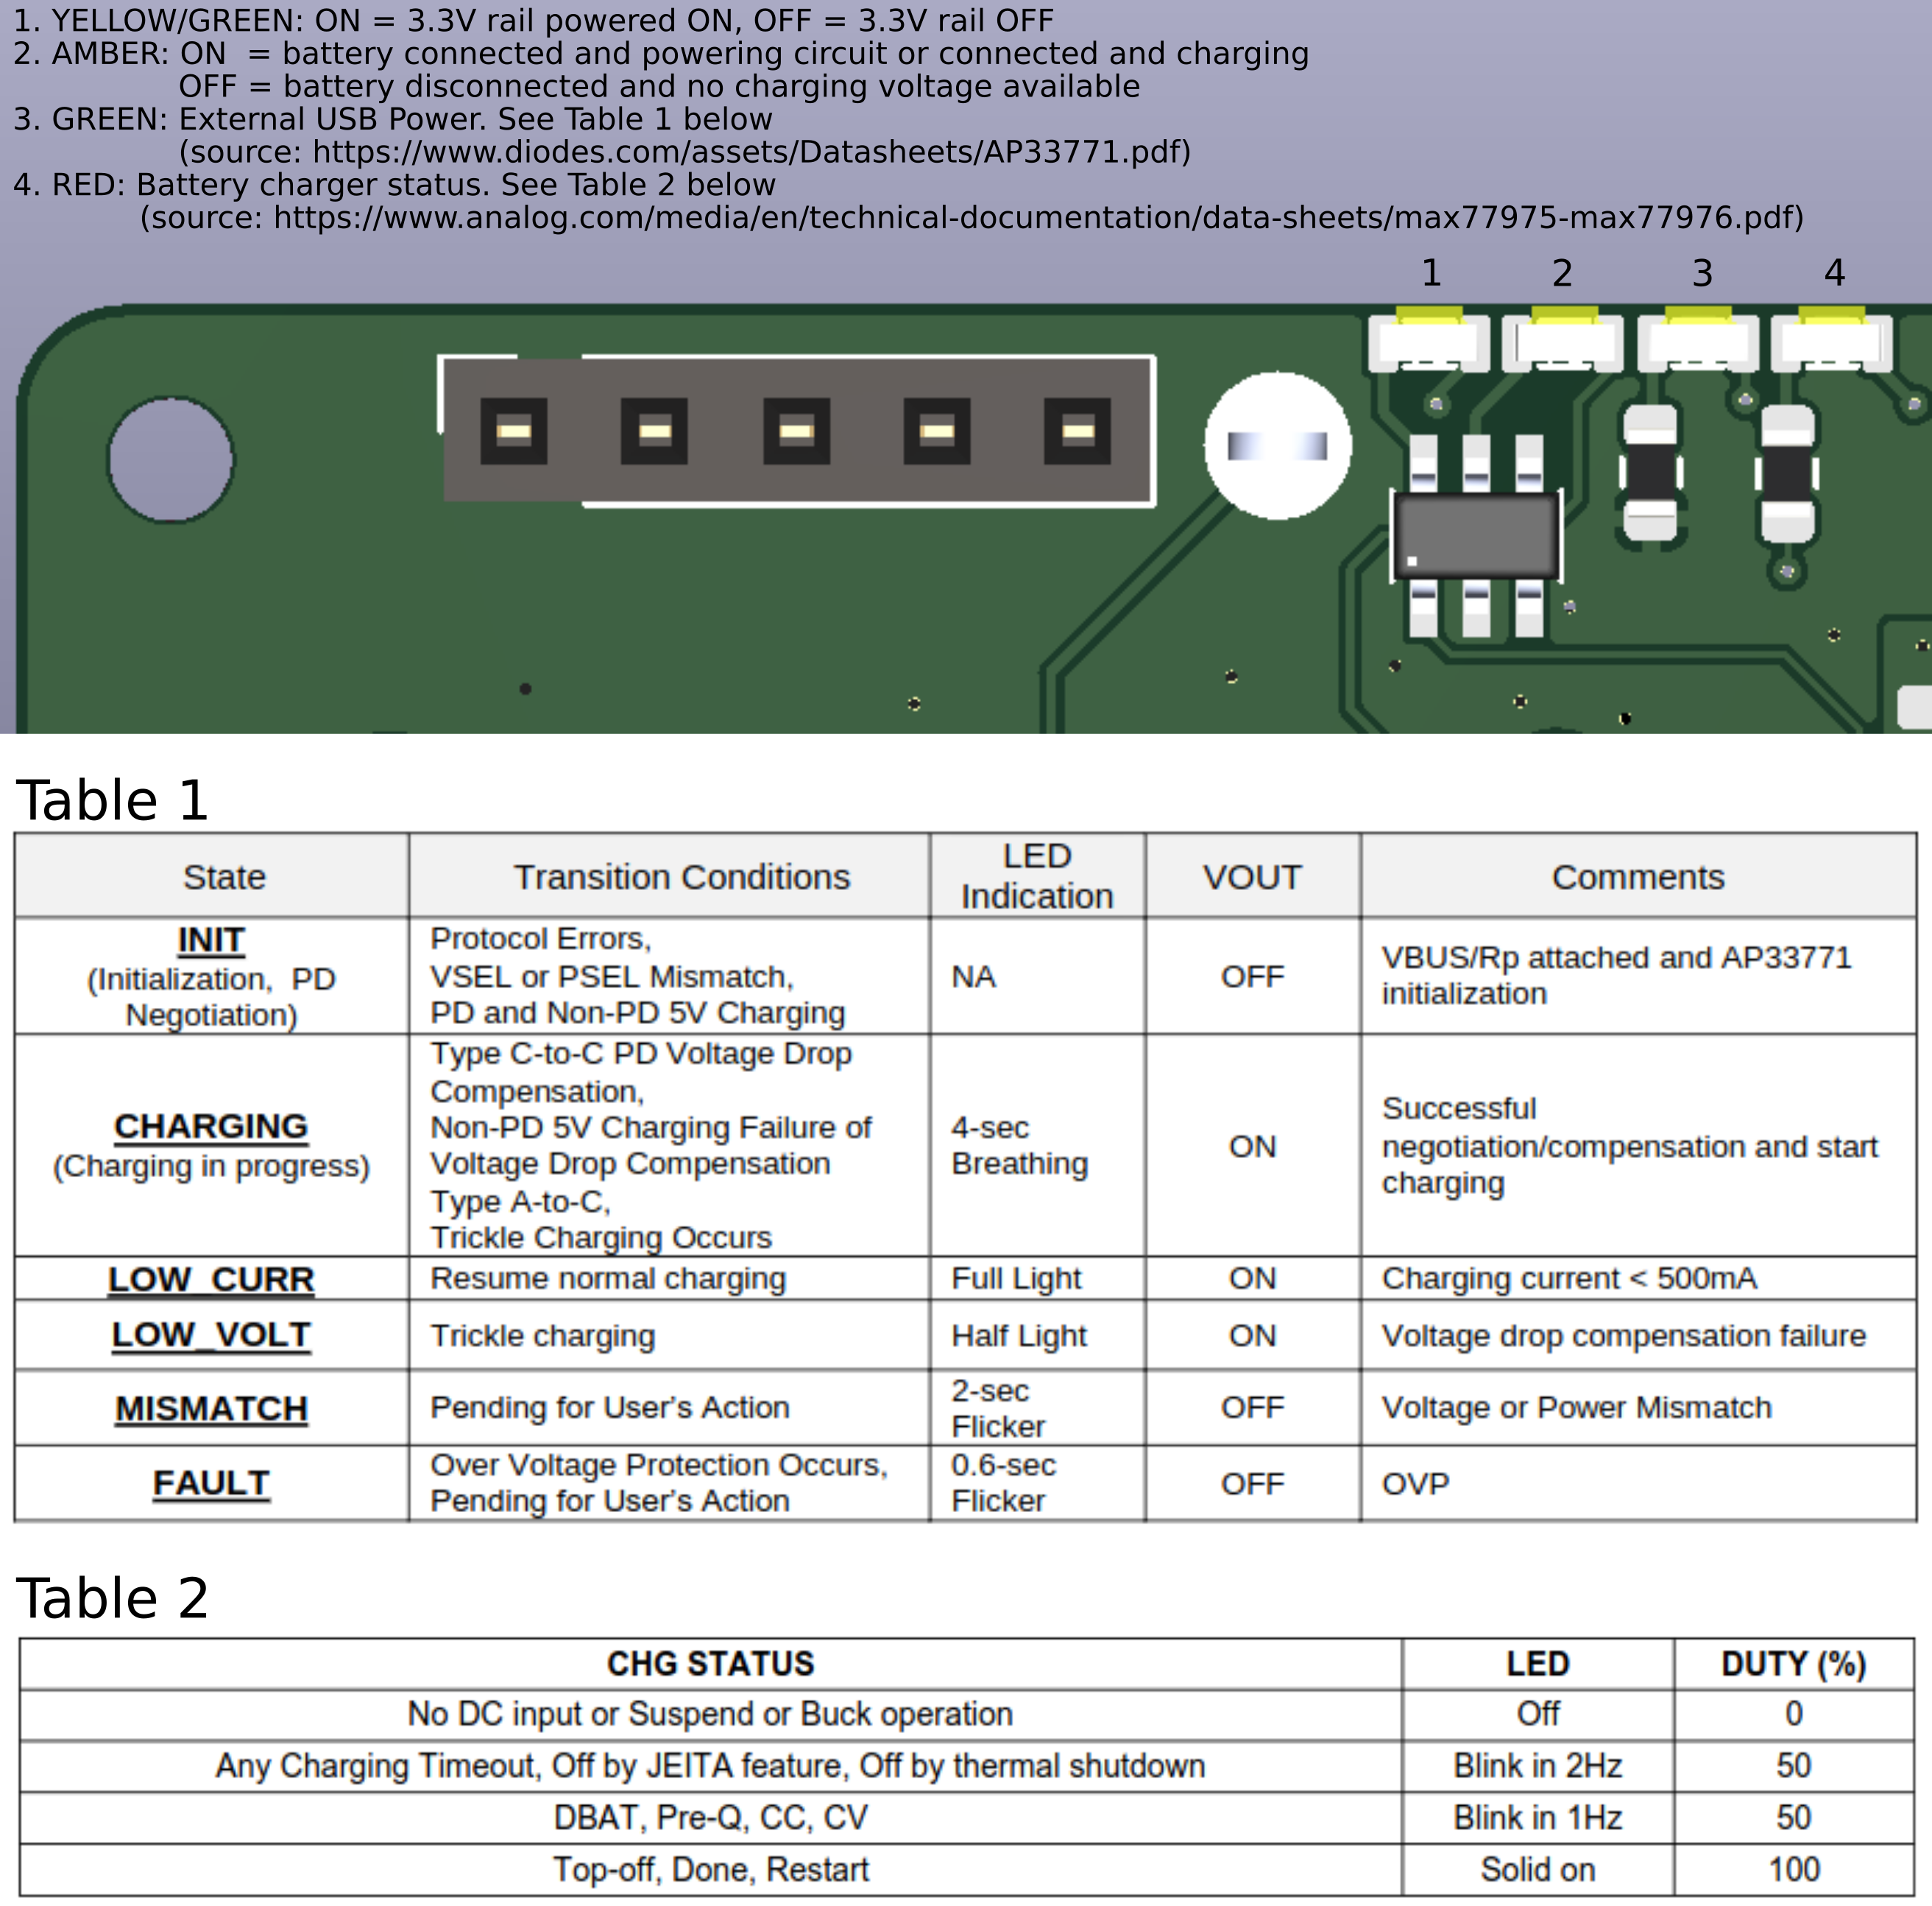
Main components on the Puck
Puck bill of materials (BOM)
24 components, 20 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | NCP1117ST33T3G AP3012KTR-G1 ON Semiconductor | SOT95P280X145-5N | U1 |
| 1 | SeeeduinoXIAO Winbond | Seeeduino_XIAO-MOUDLE14P-2p54-21X17p8MM | U2 |
| 1 | RP2040 INA250A3PWR Raspberry Pi | SOP65P640X120-16N | U3 |
| 2 | DMN3018SSD-13 | SOIC127P600X170-8N | Q1, Q2 |
| 1 | IRLR6225TRPBF | TO-252-3 | Q3 |
| 1 | 10103594-0001LF PicoBlade_5Pin_SMD_Horizontal Amphenol | Molex_PicoBlade_53261-0571_1x05-1MP_P1.25mm_Horizontal | J1 |
| 1 | TSW-102-23-T-S PicoBlade_2Pin_SMD_Horizontal Samtec | Molex_PicoBlade_53261-0271_1x02-1MP_P1.25mm_Horizontal | J2 |
| 4 | TestPoint_CurrentShunt | SAMTEC_TSM-102-01-T-SH | TP8, TP9, TP10, TP11 |
| 1 | 1N5819 | D_SOD-123 | D1 |
| 1 | 10u | IND_LQH43PN100M26L | L1 |
| 1 | GRM21BR61C106KE15K C_1uF Murata | C_0603_1608Metric | C1 |
| 1 | GCM1555C1H270JA16D C_1uF Murata | C_0603_1608Metric | C2 |
| 1 | GCM1555C1H270JA16D DNP Murata | C_0603_1608Metric_DNP | C3 |
| 1 | GRM21BR61C106KE15K DNP Murata | C_0603_1608Metric_DNP | C4 |
| 1 | GRM155R71E104KE14J C_0.1uF Murata | C_0603_1608Metric | C5 |
| 1 | GRM155R71E104KE14J C_1uF Murata | C_0603_1608Metric | C6 |
| 1 | GRM155R71E104KE14J DNP Murata | C_0603_1608Metric_DNP | C7 |
| 1 | RC0402FR-071KP 21.5k Yageo | R_0603_1608Metric | R1 |
| 1 | 1.37k | R_0603_1608Metric | R2 |
| 1 | RC0402FR-0727R4L 1.13k Yageo | R_0603_1608Metric | R3 |
Puck design files
The KiCad project lives in the oist/smartphone-robot-cad repository on GitHub; these links point at the commit this page was built from.
Puck: common questions
What microcontroller does the Puck use?
The Puck is built around the RP2040, from the RP2040/RP2350 family.
How big is the Puck PCB?
The Puck measures 63 × 62.9 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Puck?
24 components, from 20 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Puck design files?
From the oist/smartphone-robot-cad repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Puck design in my own project?
Yes, under the terms of its Apache-2.0 license, which oist chose for the repository.
Can I test firmware for the Puck without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
More boards in smartphone-robot-cad
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k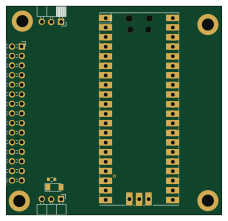 RP2040/RP2350
LogicAnalyzer
gusmanb
57 × 55.2 mm6 parts2LGPL-3.05.0k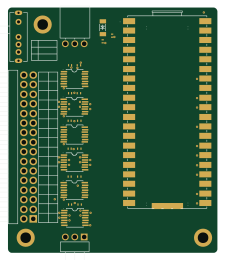 RP2040/RP2350
Jitx design
55.5 × 65 mm26 parts4LGPL-3.05.0k RP2040/RP2350
Main
google
98 × 71 mm102 parts2LApache-2.02.9k