
ESP32-Robotic-Arm-Car

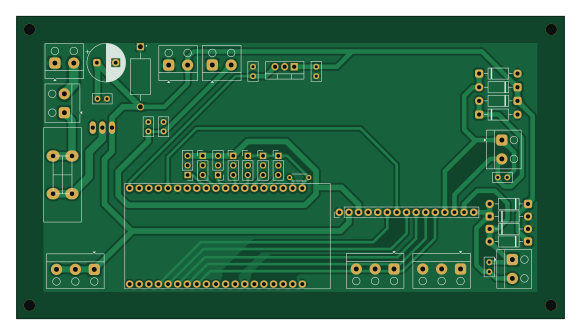
About the ESP32-Robotic-Arm-Car PCB
ESP32-Robotic-Arm-Car is an open source ESP32 PCB design by Omar-Hany00, published on GitHub. It is a 2-layer board measuring 145 × 80 mm, with 36 components from 25 distinct parts.
Its main chip is the ESP32-DEVKITC-32D, from the ESP32 family. Other key parts include the L7805 and L298N. By type, the board carries 16 connectors, 9 diodes, 5 capacitors, 3 ICs, 1 transistor and 1 resistor.
It belongs with the robotics & motion and iot & wireless designs in this gallery.
From the project
Custom ESP32-based RC robotic arm car with integrated PCB, motor control, and servo actuation.
A custom ESP32-based robotic arm car designed for embedded control, wireless operation, and integrated PCB-based hardware management.
The project combines robotics, embedded systems, PCB design, and motor actuation into a compact mobile robotic platform featuring a servo-actuated robotic arm and custom-designed electronics.
- ESP32-based embedded control system - Custom PCB designed using KiCad - DC motor drive system - Servo-controlled robotic arm - Integrated power and signal routing - Compact mobile robotic platform
Main components on the ESP32-Robotic-Arm-Car
ESP32-Robotic-Arm-Car bill of materials (BOM)
36 components, 25 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | L7805 | TO-220-3_Vertical | U1 |
| 1 | ESP32-DEVKITC-32D | MODULE_ESP32-DEVKITC-32D | U2 |
| 1 | L298N | PinHeader_1x15_P2.54mm_Vertical | U3 |
| 1 | IRF4905 | TO220BH | Q1 |
| 1 | Motor 1 | Altech_AK100_1x02_P5.00mm | J1 |
| 3 | Current Distribution | Altech_AK100_1x03_P5.00mm | J2, J4, J15 |
| 1 | Buck Converter Input | Altech_AK100_1x02_P5.00mm | J3 |
| 1 | Buck Converter Output | Altech_AK100_1x02_P5.00mm | J5 |
| 1 | Switch | Altech_AK100_1x02_P5.00mm | J6 |
| 1 | Battery Input | Altech_AK100_1x02_P5.00mm | J7 |
| 1 | Sensor1 | PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | Sensor2 | PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | Sensor3 | PinHeader_1x03_P2.54mm_Vertical | J10 |
| 1 | Servo1 | PinHeader_1x03_P2.54mm_Vertical | J11 |
| 1 | Servo2 | PinHeader_1x03_P2.54mm_Vertical | J12 |
| 1 | Servo3 | PinHeader_1x03_P2.54mm_Vertical | J13 |
| 1 | Servo4 | PinHeader_1x03_P2.54mm_Vertical | J14 |
| 1 | Motor 2 | Altech_AK100_1x02_P5.00mm | J'1 |
| 1 | MF-R600 | Fuse_Holder_5x20 | TH1 |
| 8 | 1N4007 | D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2, D3, D4, D5, D6, D7, D8 |
Show 5 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SMBJ18A | DIOAD1592W101L950D530 | D9 |
| 1 | 470uF | CP_Radial_D10.0mm_P5.00mm | C3 |
| 1 | 1uF | C_Disc_D5.0mm_W2.5mm_P2.50mm | C4 |
| 3 | 100nF | C_Disc_D5.0mm_W2.5mm_P2.50mm | C5, C'1, C'2 |
| 1 | 10K | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R1 |
ESP32-Robotic-Arm-Car design files
The KiCad project lives in the Omar-Hany00/ESP32-Robotic-Arm-Car repository on GitHub; these links point at the commit this page was built from.
ESP32-Robotic-Arm-Car: common questions
What microcontroller does the ESP32-Robotic-Arm-Car use?
The ESP32-Robotic-Arm-Car is built around the ESP32-DEVKITC-32D, from the ESP32 family.
How big is the ESP32-Robotic-Arm-Car PCB?
The ESP32-Robotic-Arm-Car measures 145 × 80 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the ESP32-Robotic-Arm-Car?
36 components, from 25 distinct parts. The full bill of materials is listed on this page.
Where can I download the ESP32-Robotic-Arm-Car design files?
From the Omar-Hany00/ESP32-Robotic-Arm-Car repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the ESP32-Robotic-Arm-Car design in my own project?
The repository has no license, so all rights stay with Omar-Hany00. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the ESP32-Robotic-Arm-Car without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k