
BLDC

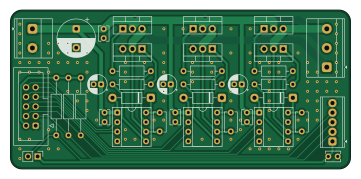
About the BLDC PCB
BLDC is an open source PCB design by paulmikael02, published on GitHub. It is a 2-layer board measuring 90 × 42 mm, with 38 components from 14 distinct parts.
Other key parts include the IRS2001. By type, the board carries 12 capacitors, 9 resistors, 6 transistors, 5 connectors, 3 ICs and 3 diodes.
It belongs with the robotics & motion, sensors and dev boards & breakouts designs in this gallery.
From the project
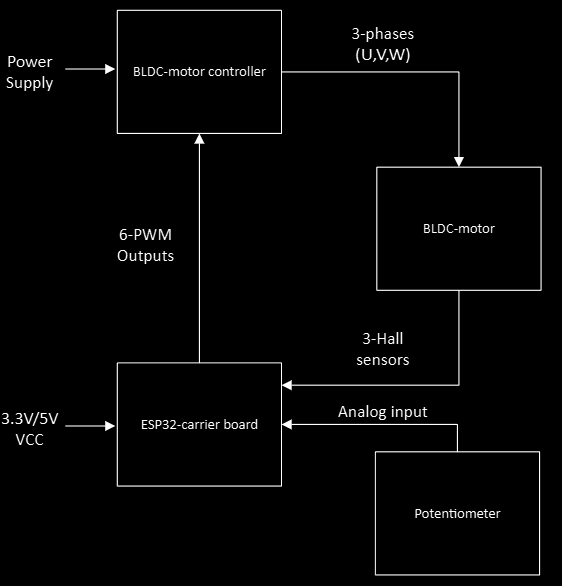
ESP32-based BLDC motor controller built with ESP-IDF, utilizing Hall sensors and the hardware MCPWM peripheral.
FI | Lue kattava suomenkielinen dokumentaatio tästä
This repository contains the hardware designs (KiCad) and embedded software (ESP-IDF) for a 3-phase brushless DC (BLDC) motor controller.
The project was developed as part of modernizing the educational equipment in the embedded systems laboratory at SeAMK. The old 8-bit ATmega architecture was upgraded to a modern 32-bit ESP32-C6 platform. The new motherboard was designed to directly support the laboratory's legacy analog and digital input/output expansion boards, preserving compatibility with the existing educational environment.
Main components on the BLDC
BLDC bill of materials (BOM)
38 components, 14 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | IRS2001 | DIP-8_W7.62mm_Socket | U1, U2, U3 |
| 6 | IRFZ44N | TO-220-3_Vertical | Q1, Q2, Q3, Q4, Q5, Q6 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J1 |
| 1 | Screw_Terminal_01x03 | TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J2 |
| 1 | Screw_Terminal_01x05 | TerminalBlock_Phoenix_MPT-0,5-5-2.54_1x05_P2.54mm_Horizontal | J3 |
| 1 | Conn_02x05_Odd_Even | IDC-Header_2x05_P2.54mm_Vertical | J4 |
| 1 | Conn_01x02 | PinHeader_1x02_P2.54mm_Vertical | J5 |
| 3 | 1N5819 | D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2, D3 |
| 5 | 100n | C_Disc_D3.8mm_W2.6mm_P2.50mm | C1, C5, C8, C10, C13 |
| 3 | 1u | C_Disc_D5.1mm_W3.2mm_P5.00mm | C2, C6, C9 |
| 3 | 10u | CP_Radial_D5.0mm_P2.00mm | C3, C4, C7 |
| 1 | 470u | CP_Radial_D10.0mm_P5.00mm | C11 |
| 6 | 10 | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R2, R3, R4, R5, R6 |
| 3 | 4k7 | R_Axial_DIN0207_L6.3mm_D2.5mm_P15.24mm_Horizontal | R7, R8, R9 |
BLDC design files
The KiCad project lives in the paulmikael02/ESP32-BLDC-Motor-Controller repository on GitHub; these links point at the commit this page was built from.
BLDC: common questions
How big is the BLDC PCB?
The BLDC measures 90 × 42 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the BLDC?
38 components, from 14 distinct parts. The full bill of materials is listed on this page.
Where can I download the BLDC design files?
From the paulmikael02/ESP32-BLDC-Motor-Controller repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the BLDC design in my own project?
The repository has no license, so all rights stay with paulmikael02. Use it as a reference, and ask the author before reusing the design.
More boards in ESP32-BLDC-Motor-Controller
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
Eecv breakout
rusefi
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
134pin 7-967288-1
139.7 × 73.7 mm38 parts2LGPL-3.01.2k