
DRV8825

About the DRV8825 PCB
DRV8825 is an open source PCB design by QUT-EESS, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 28 × 16.5 mm, with 18 components from 13 distinct parts.
Other key parts include the DRV8825. By type, the board carries 6 capacitors, 6 resistors, 3 modules, 2 connectors and 1 IC.
It belongs with the robotics & motion designs in this gallery.
From the project
EESS Modular Robotics Platform
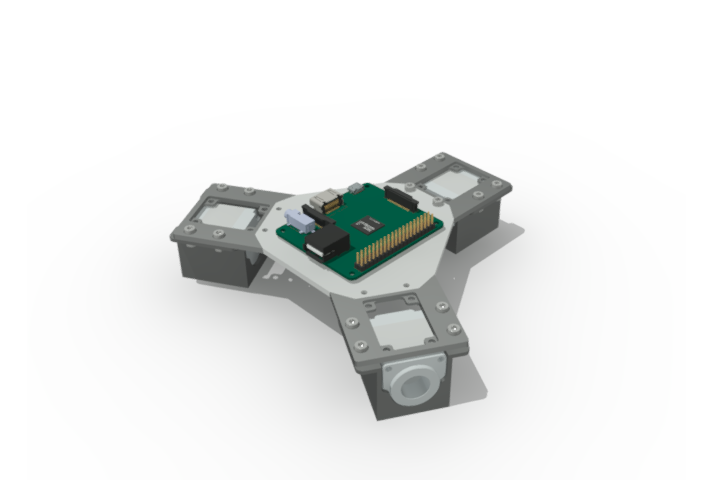
An open source modular robotics platform designed with KiCAD and FreeCAD. Custom designed Chassis designed to be laser cut/3d printed/CnC Milled. Custom fit stepper motor mounts with embedded motor controller PCB.
Main Processor unit consists of a Raspberry Pi A+ for path planning and general computation. An STM32 ARM microcontroller system controller will handle the stepper motor control via communication with the RPi A+ board and motor controllers.
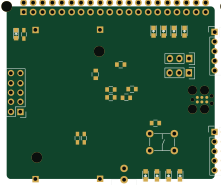
Main components on the DRV8825
DRV8825 bill of materials (BOM)
18 components, 13 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | DRV8825 | DRV-8825_FOOTPRINT | U1 |
| 3 | Jumper_NO_Small | C_0603 | M0, M1, M2 |
| 1 | CONN_01X10 | Pin_Header_Straight_2x05 | P1 |
| 1 | CONN_01X04 | Pin_Header_Straight_1x04 | P2 |
| 1 | 100uF | c_elec_6.3x7.7 | C1 |
| 3 | 0.1uF | C_0603 | C2, C3, C5 |
| 1 | 0.01uF | C_0603 | C4 |
| 1 | 0.47uF | C_0805 | C6 |
| 1 | 50K Pot | Potentiometer | R1 |
| 1 | 1M | R_0805 | R2 |
| 1 | 30K* | R_0603 | R3 |
| 2 | 100m | R_1206 | R4, R5 |
| 1 | 10K | R_0805 | R6 |
DRV8825 design files
The KiCad project lives in the QUT-EESS/OmniBot repository on GitHub; these links point at the commit this page was built from.
DRV8825: common questions
How big is the DRV8825 PCB?
The DRV8825 measures 28 × 16.5 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the DRV8825?
18 components, from 13 distinct parts. The full bill of materials is listed on this page.
Where can I download the DRV8825 design files?
From the QUT-EESS/OmniBot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the DRV8825 design in my own project?
Yes, under the terms of its GPL-3.0 license, which QUT-EESS chose for the repository.
More boards in OmniBot
Similar boards

Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Trollerv2
rene-dev
100 × 75 mm33 parts4LGPL-3.0979
Powerstep
95.2 × 71.5 mm28 parts4LGPL-3.0979
11ua
57.3 × 19 mm26 parts2LGPL-3.0979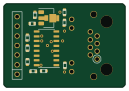
Diff driver
32 × 22 mm14 parts2LGPL-3.0979