
Diff drive mapping robot

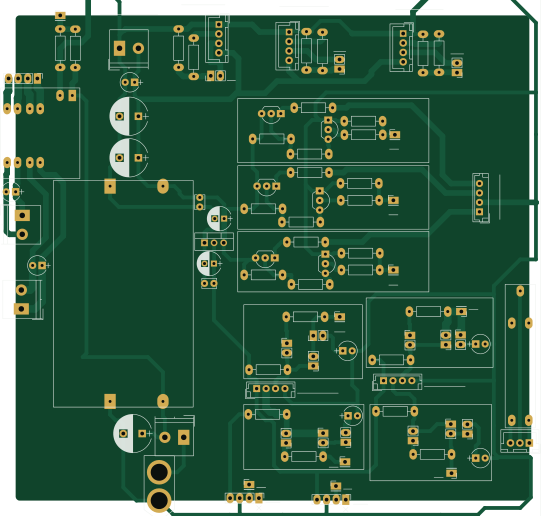
About the Diff drive mapping robot PCB
Diff drive mapping robot is an open source PCB design by rayvburn, published on GitHub. It is a 2-layer board measuring 136 × 128.5 mm, with 95 components from 46 distinct parts.
Other key parts include the LD1117S33TR. By type, the board carries 40 connectors, 31 resistors, 14 capacitors, 6 transistors and 1 IC.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
ROS driver for the Raspberry Pi based differential drive robot
Base of the robot was made of acrylic glass. The locomotion is provided by 3 wheels, including 1 caster. The two-wheel differential drive based on DC motors makes the machine nonholonomic.
Within the electronic part of the robot's construction, a printed circuit board was designed. All the necessary electronical components including reflective sensors used to measure the distance from obstacles were placed on the board. The sensor providing the largest amount of data is the camera. It is integrated with the Raspberry Pi microcomputer. The extension of the microcomputer's tasks to the reading…
Main components on the Diff drive mapping robot
Diff drive mapping robot bill of materials (BOM)
95 components, 46 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LD1117S33TR | TO-220-3_Vertical | U1 |
| 3 | Q_NMOS_SGD | TO-92_Inline_Wide | Q1, Q4, Q6 |
| 3 | Q_PNP_CBE | TO-92_Inline_Wide | Q2, Q5, Q7 |
| 1 | DiodaRGB | JST_EH_B04B-EH-A_04x2.50mm_Straight | J1 |
| 1 | ZasilanieRaspberry | TerminalBlock_Philmore_TB132_02x5mm_Straight | J2 |
| 1 | DiodaB_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J3 |
| 1 | Akumulator | XT60 | J4 |
| 1 | EnkoderA2_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J5 |
| 1 | Akumulator_BM | JST_XH_B03B-XH-A_03x2.50mm_Straight | J6 |
| 1 | DiodaG_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J7 |
| 1 | MotorA | TerminalBlock_Philmore_TB132_02x5mm_Straight | J8 |
| 1 | MotorB | TerminalBlock_Philmore_TB132_02x5mm_Straight | J9 |
| 1 | DiodaR_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J10 |
| 1 | WylacznikGlowny | TerminalBlock_Philmore_TB132_02x5mm_Straight | J11 |
| 1 | EnkoderB2_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J12 |
| 1 | SonarRAW1 | JST_XH_B04B-XH-A_04x2.50mm_Straight | J13 |
| 1 | Enkoder2 | JST_EH_B04B-EH-A_04x2.50mm_Straight | J14 |
| 12 | Zworka | Pin_Header_Straight_1x02_Pitch2.54mm | J15, J16, J17, J18, J19, J20, J23, J24 +4 |
| 1 | EnkoderA1_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J21 |
| 1 | EnkoderB1_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J22 |
Show 26 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Enkoder1 | JST_EH_B04B-EH-A_04x2.50mm_Straight | J25 |
| 1 | HBridgeInputs | Pin_Header_Straight_1x04_Pitch2.54mm | J28 |
| 1 | IR1_Out_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J31 |
| 1 | IR2_Out_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J32 |
| 1 | IR1 | Pin_Header_Straight_1x04_Pitch2.54mm | J33 |
| 1 | IR2 | Pin_Header_Straight_1x04_Pitch2.54mm | J34 |
| 1 | SonarRAW2 | JST_XH_B04B-XH-A_04x2.50mm_Straight | J35 |
| 1 | SonarRAW3 | JST_XH_B04B-XH-A_04x2.50mm_Straight | J36 |
| 1 | SonarRPi2 | Pin_Header_Straight_1x02_Pitch2.54mm | J37 |
| 1 | SonarRPi3 | Pin_Header_Straight_1x02_Pitch2.54mm | J38 |
| 1 | SonarRPi1 | Pin_Header_Straight_1x02_Pitch2.54mm | J39 |
| 1 | NapiecieAkumulatora_RPi | Pin_Header_Straight_1x01_Pitch2.54mm | J40 |
| 1 | HX-2S-01_5A | HX-2S-01_5A | BMS1 |
| 1 | XL4016 | XL4016 | BuckConverter1 |
| 1 | MX1508 | MX1508 | HBridge1 |
| 3 | 1000 uF / 25V | CP_Radial_D10.0mm_P5.00mm | C1, C9, C10 |
| 3 | 470 nF / 50V | CP_Radial_Tantal_D5.0mm_P2.50mm | C2, C3, C4 |
| 4 | 20 nF | CP_Radial_Tantal_D5.0mm_P2.50mm | C5, C6, C7, C8 |
| 2 | 100nF / 50V | C_Disc_D3.8mm_W2.6mm_P2.50mm | C11, C14 |
| 2 | 33uF / 63V | CP_Radial_D6.3mm_P2.50mm | C12, C13 |
| 6 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R3, R8, R10, R13, R15 |
| 3 | 100R | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R2, R9, R14 |
| 11 | 1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R4, R11, R16, R18, R19, R22, R23, R25 +3 |
| 3 | ???R | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5, R12, R17 |
| 4 | 2,2k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R6, R7, R20, R21 |
| 4 | 2k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R24, R27, R29, R31 |
Diff drive mapping robot design files
The KiCad project lives in the rayvburn/diff_drive_mapping_robot repository on GitHub; these links point at the commit this page was built from.
Diff drive mapping robot: common questions
How big is the Diff drive mapping robot PCB?
The Diff drive mapping robot measures 136 × 128.5 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Diff drive mapping robot?
95 components, from 46 distinct parts. The full bill of materials is listed on this page.
Where can I download the Diff drive mapping robot design files?
From the rayvburn/diff_drive_mapping_robot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Diff drive mapping robot design in my own project?
The repository has no license, so all rights stay with rayvburn. Use it as a reference, and ask the author before reusing the design.
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k