
Exoskeleton-Glove

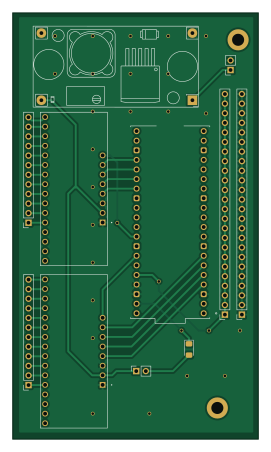
About the Exoskeleton-Glove PCB
Exoskeleton-Glove is an open source PCB design by ReeyanshShah, published on GitHub. It is a 2-layer board measuring 65 × 112.9 mm, with 11 components from 7 distinct parts.
Other key parts include the BOB-09056, YAAJ_DCDC_StepDown_LM2596 and SC0918. By type, the board carries 6 connectors, 3 ICs, 1 module and 1 diode.
It belongs with the power & battery designs in this gallery.
From the project
In a nutshell, our design collects data from rotary potentiometers serially, sends them to Rpi pico which in turn quickly cycles through the available channels in a round robin fashion while powering everything using an LM2596 Buck converter
In a nutshell, our design collects data from rotary potentiometers serially, sends them to Rpi pico which in turn quickly cycles through the available channels in a round robin fashion while powering everything using an LM2596 Buck converter
Our PCB design has the ability to support upto 24 rotary potentiometers due to which we have 24 ports connected to ground and 24 ports connected to VCC(3.3V output from sensor). We connected these to the 3.3v supply of Pico instead of our main power supply which is LM2596 because cd74hc4067 multiplexers are designed to take an input between 0 and 3.3V.…
Main components on the Exoskeleton-Glove
Exoskeleton-Glove bill of materials (BOM)
11 components, 7 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | BOB-09056 | MODULE_BOB-09056 | U1, U2 |
| 1 | YAAJ_DCDC_StepDown_LM2596 | YAAJ_DCDC_StepDown_LM2596 | U6 |
| 1 | SC0918 | MODULE_SC0918 | A1 |
| 2 | Conn_01x12_Pin | PinSocket_1x12_P2.54mm_Vertical | J1, J2 |
| 2 | Conn_01x02_Pin | PinSocket_1x02_P2.54mm_Vertical | J3, J6 |
| 2 | Conn_01x24_Socket | PinSocket_1x24_P2.54mm_Vertical | J4, J5 |
| 1 | D_Schottky | D_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D1 |
Exoskeleton-Glove design files
The KiCad project lives in the ReeyanshShah/Exoskeleton-Glove repository on GitHub; these links point at the commit this page was built from.
- Layoutpcb/PCB1/PCB.kicad_pcb
- Schematicpcb/PCB1/PCB.kicad_sch
- BOMbom.xlsx
Exoskeleton-Glove: common questions
How big is the Exoskeleton-Glove PCB?
The Exoskeleton-Glove measures 65 × 112.9 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Exoskeleton-Glove?
11 components, from 7 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Exoskeleton-Glove design files?
From the ReeyanshShah/Exoskeleton-Glove repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Exoskeleton-Glove design in my own project?
The repository has no license, so all rights stay with ReeyanshShah. Use it as a reference, and ask the author before reusing the design.
Similar boards
Display Carrier
AxxAxx
35.6 × 58.2 mm5 parts2LGPL-3.01.7k
ControllerCurrentShuntAddOn
stuartpittaway
26 × 16.9 mm9 parts2LCC-BY-NC-4.01.1k
TemperaturePCB PANEL
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k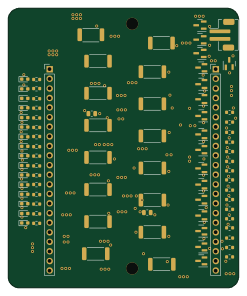
Module 16S PassiveBalanceAddOn
61 × 74 mm86 parts2LCC-BY-NC-4.01.1k
ProgrammingAdapter
10.5 × 83 mm3 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k