
Main Robot Board

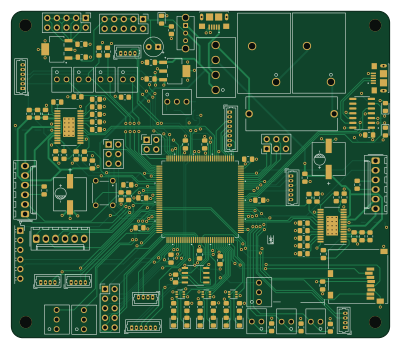
About the Main Robot Board
Main Robot Board is an open source PIC PCB design by satomm1, published on GitHub under the MIT license. It is a 4-layer board measuring 100 × 86.3 mm, with 109 components from 38 distinct parts.
Its main chip is the PIC32MZ2048EFH144-I/PL, from the PIC family. Other key parts include the AP2114HA-3.3TRG1, GSF7002DW, MCP2221A-I/SL, DRV8842PWPR and 22232041. By type, the board carries 40 resistors, 30 capacitors, 12 ICs, 10 connectors, 10 diodes and 6 switches.
It belongs with the robotics & motion, sensors and power & battery designs in this gallery.
From the project
Contains the electrical schematics and PCB gerber files for the Robot electronics. There are several Schematics/PCB designs for a variety of uses: - Main Board - the main motor controller and communicator with the Jetson - Microphone - a breakout board for a Mems omnidirectional
Contains the electrical schematics and PCB gerber files for the Robot electronics. There are several Schematics/PCB designs for a variety of uses: - Main Board - the main motor controller and communicator with the Jetson - Microphone - a breakout board for a Mems omnidirectional microphone - IMU Breakout - a breakout board containing a 6-axis IMU - Reflective Sensor - a breakout board containing a sensor for very short distance measurements
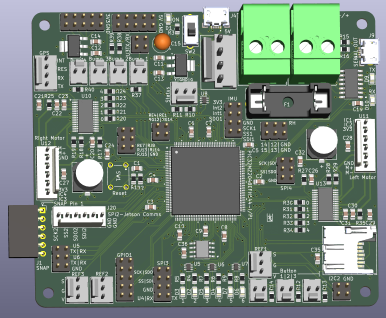
Main components on the Main Robot Board
Main Robot Board bill of materials (BOM)
109 components, 38 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | PIC32MZ2048EFH144-I/PL Microchip Technology | LQFP144_PL_MCH-M | U1 |
| 2 | AP2114HA-3.3TRG1 Diodes Incorporated | SOT-223_DIO-M | U2, U3 |
| 4 | GSF7002DW Good-Ark Semiconductor | SOT-363_SC-70-6 | U5, U6, U7, U8 |
| 1 | MCP2221A-I/SL MCP2221A-I_SL Microchip Technology | SOIC127P600X175-14N | U9 |
| 2 | DRV8842PWPR Texas Instruments | PWP0028C_M | U10, U13 |
| 2 | 22232041 Quad_Encoder_Motor Molex | Molex_KK-254_AE-6410-06A_1x06_P2.54mm_Vertical | U11, U12 |
| 1 | PRPC006SBAN-M71RC SNAP Program Sullins Connector Solutions | PinSocket_1x06_P2.54mm_Horizontal | J1 |
| 1 | PH2-10-UA 3.3V Supply Adam Tech | PinHeader_2x05_P2.54mm_Vertical | J2 |
| 1 | PH2-10-UA 5V Supply Adam Tech | PinHeader_2x05_P2.54mm_Vertical | J3 |
| 2 | 10118193-0001LF USB_B_Micro Amphenol ICC (FCI) | AMPHENOL_10118193-0001LF | J4, J9 |
| 2 | 1017514 Battery1 Phoenix Contact | CONN_1017514 | J5, J6 |
| 1 | 10129381-904003BLF Conn_01x04 Amphenol ICC (FCI) | Molex_PicoBlade_53047-0410_1x04_P1.25mm_Vertical | J18 |
| 1 | 10129381-906002BLF Conn_01x06 Amphenol ICC (FCI) | Molex_KK-254_AE-6410-06A_1x06_P2.54mm_Vertical | J20 |
| 1 | Conn_01x08 | Molex_PicoBlade_53047-0810_1x08_P1.25mm_Vertical | J30 |
| 1 | 4628 5A Fuse Keystone Electronics | FUSE_4628 | F1 |
| 1 | B3F-1020 Reset Omron Electronics Inc-EMC Div | SW_B3F-1000_OMR | SW1 |
| 1 | OS102011MS2QN1 5V Bypass C&K | SPDT_OS102011_CNK | SW2 |
| 1 | RA83231100 All Power Switch E-Switch | 26-60-4040_MOL | SW3 |
| 3 | 22232021 User_Button Molex | CONN_22232021_MOL | SW4, SW5, SW6 |
| 6 | 150080RS75000 LED Würth Elektronik | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D1, D2, D4, D6, D9, D10 |
Show 18 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | 150080VS75000 LED Würth Elektronik | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D3, D5, D7 |
| 1 | Status_LED | CONN3_22232031_MOL | D11 |
| 19 | CL21B104KBCNNNC 0.1 uF Samsung Electro-Mechanics | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2, C3, C4, C5, C6, C7, C8 +11 |
| 4 | CL21A475KAQNNNE 4.7 uF Samsung Electro-Mechanics | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C11, C12, C13, C14 |
| 1 | TAP106K016CRW 10 uF KYOCERA AVX | CP_Radial_Tantal_D5.0mm_P2.50mm | C15 |
| 2 | CL21B474KBFNNNE 0.47 uF Samsung Electro-Mechanics | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C20, C26 |
| 2 | CL21B103KBANNNC 0.01 uF Samsung Electro-Mechanics | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C21, C29 |
| 2 | UWT1H101MNL1GS 100 uF Nichicon | PCAP_8x10-ELECT_NCA-M | C25, C33 |
| 3 | RMCF0805FT10K0 10k Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R17, R27 |
| 4 | RMCF0805FT1K00 1k Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R12, R13, R14 |
| 11 | RMCF0805FT130R 130R Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3, R4, R5, R6, R7, R8, R9, R10 +3 |
| 2 | RMCF0805FT16K0 16k Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R18, R28 |
| 2 | RMCF0805FT51K0 51k Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R19, R29 |
| 10 | RMCF0805ZT0R00 0R Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R20, R21, R22, R23, R24, R30, R31, R32 +2 |
| 2 | RMCF0805FG1M00 1M Stackpole Electronics Inc | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R25, R35 |
| 2 | CSR0805FKR250 0.1R Stackpole Electronics Inc | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R26, R36 |
| 2 | 0.1R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R47, R49 |
| 2 | 0.05 R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R48, R50 |
Main Robot Board design files
The KiCad project lives in the satomm1/Robot repository on GitHub; these links point at the commit this page was built from.
Main Robot Board: common questions
What microcontroller does the Main Robot Board use?
The Main Robot Board is built around the PIC32MZ2048EFH144-I/PL, from the PIC family.
How big is the Main Robot Board?
The Main Robot Board measures 100 × 86.3 mm, has 4 copper layers and is 1.769872 mm thick.
How many components are on the Main Robot Board?
109 components, from 38 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Main Robot Board design files?
From the satomm1/Robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Main Robot Board design in my own project?
Yes, under the terms of its MIT license, which satomm1 chose for the repository.
Can I test firmware for the Main Robot Board without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug PIC firmware against it before you order a PCB.
More boards in Robot
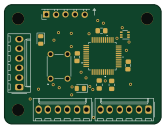 PIC
MCU DSP
41.5 × 31.6 mm20 parts2LMIT0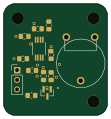 PIC
CO Sensor
27.3 × 29.4 mm13 parts2LMIT0 PIC
EnvironmentSensor2
19.3 × 14.2 mm9 parts2LMIT0
BME690 Breakout Board
18.3 × 16.7 mm4 parts2LMIT0 PIC
BMI323 Breakout Board
26.5 × 23.9 mm4 parts2LMIT0
Reflective Opto (Cliff) Sensor
26.5 × 6.5 mm4 parts2LMIT0
Microphone
20.8 × 15 mm3 parts2LMIT0
Similar boards
 PIC
Pslab hardware
fossasia
99 × 53.3 mm187 parts4LApache-2.01.7k PIC
Micro 8088
skiselev
152.4 × 101.6 mm71 partsGPL-3.0414 PIC
GB-MBCTEST
Gekkio
51.4 × 61 mm32 parts2LCC-BY-4.0376 PIC
GB-BENCH-G1
100 × 100 mm98 parts4LCC-BY-4.0376 PIC
GB-CARTPP-DIY
100 × 100 mm22 parts2LCC-BY-4.0376 PIC
GB-LIVE32
51.4 × 61 mm46 parts4LCC-BY-4.0376