
Self Balancing Bot

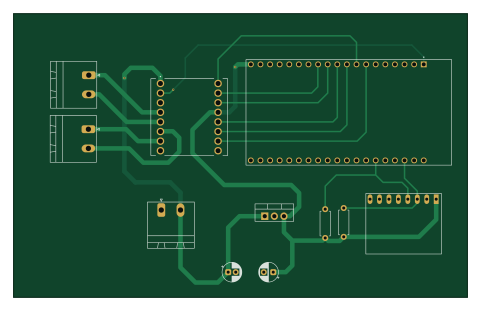
About the Self Balancing Bot PCB
Self Balancing Bot is an open source ESP32 PCB design by Shantu-2580, published on GitHub. It is a 2-layer board measuring 120 × 75 mm, with 11 components from 10 distinct parts.
Its main chip is the ESP32-DEVKITC-32D, from the ESP32 family. Other key parts include the L7805 and ROB-14450. By type, the board carries 4 ICs, 3 connectors, 2 capacitors and 2 resistors.
It belongs with the sensors, robotics & motion and iot & wireless designs in this gallery.
From the project
A two-wheeled self-balancing robot using ESP32, MPU6050 (accelerometer + gyroscope), TB6612FNG motor driver, and Bluetooth gamepad control via Bluepad32.
A two-wheeled self-balancing robot using ESP32, MPU6050 (accelerometer + gyroscope), TB6612FNG motor driver, and Bluetooth gamepad control via Bluepad32.
Features: - Basic PID balance control (100Hz loop) - Complementary filter for sensor fusion (MPU6050 accel + gyro) - Bluetooth gamepad control via Bluepad32 - TB6612FNG motor driver interface - Fall detection safety cutoff (>45°)
Main components on the Self Balancing Bot
Self Balancing Bot bill of materials (BOM)
11 components, 10 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | L7805 | TO-220-3_Vertical | U1 |
| 1 | ESP32-DEVKITC-32D | MODULE_ESP32-DEVKITC-32D | U2 |
| 1 | ROB-14450 | MODULE_ROB-14450 | U3 |
| 1 | ~ | Untitled | U4 |
| 1 | Battery | PhoenixContact_MSTBA_2,5_2-G-5,08_1x02_P5.08mm_Horizontal | J1 |
| 1 | Motor_L | PhoenixContact_MSTBA_2,5_2-G-5,08_1x02_P5.08mm_Horizontal | J2 |
| 1 | Motor_R | PhoenixContact_MSTBA_2,5_2-G-5,08_1x02_P5.08mm_Horizontal | J3 |
| 1 | 10uF | CP_Radial_D5.0mm_P2.00mm | C1 |
| 1 | 0.1uF | CP_Radial_D5.0mm_P2.50mm | C2 |
| 2 | 4.7K | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2 |
Self Balancing Bot design files
The KiCad project lives in the Shantu-2580/Prototypes repository on GitHub; these links point at the commit this page was built from.
Self Balancing Bot: common questions
What microcontroller does the Self Balancing Bot use?
The Self Balancing Bot is built around the ESP32-DEVKITC-32D, from the ESP32 family.
How big is the Self Balancing Bot PCB?
The Self Balancing Bot measures 120 × 75 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Self Balancing Bot?
11 components, from 10 distinct parts. The full bill of materials is listed on this page.
Where can I download the Self Balancing Bot design files?
From the Shantu-2580/Prototypes repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Self Balancing Bot design in my own project?
The repository has no license, so all rights stay with Shantu-2580. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Self Balancing Bot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in Prototypes
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k