
Sf motion

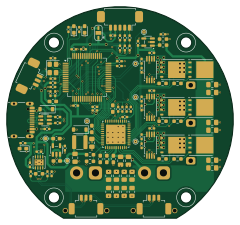
About the Sf motion PCB
Sf motion is an open source STM32 PCB design by sirojudinMunir, published on GitHub under the MIT license. It is a 2-layer board measuring 60 × 56 mm, with 123 components from 46 distinct parts.
Its main chip is the STM32F405RGTX, from the STM32 family. Other key parts include the DRV8323RHRGZR, LP2985-3.3, INA240A1PW, LM321 and USBLC6-2SC6. By type, the board carries 51 capacitors, 37 resistors, 11 connectors, 10 ICs, 6 transistors and 5 diodes.
It belongs with the robotics & motion and usb & debug tools designs in this gallery.
From the project
Open-source Motion Control Platform
Open-source BLDC/PMSM motor control platform based on STM32 and Field-Oriented Control (FOC).
- FOC firmware - Custom motor driver hardware - KiCad schematic and PCB design - Gerber and BOM files - Python communication and control tools - PyQt/PyQtGraph GUI for motor monitoring and testing
You will need: - FOC Driver Board - ST-Link programmer/debugger with 3-pin Molex pico-blade P1.25mm connector - DC power supply - BLDC/PMSM motor - diametrical magnet - USB type-C cable - power cable with XT-30 female connector
Main components on the Sf motion
Sf motion bill of materials (BOM)
123 components, 46 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F405RGTX STM32F405RGTx | LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | DRV8323RHRGZR | QFN50P700X700X100-49N | U2 |
| 1 | LP2985-3.3 | SOT-23-5 | U3 |
| 3 | INA240A1PW | TSSOP-8_4.4x3mm_P0.65mm | U4, U6, U7 |
| 1 | LM321 | SOT-23-5 | U5 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U8 |
| 1 | TJA1051TK-3 | HVSON-8-1EP_3x3mm_P0.65mm_EP1.6x2.4mm | U9 |
| 1 | AS5047D | TSSOP-14_4.4x5mm_P0.65mm | U10 |
| 6 | WSD30100DN56 | TDSON-8-1 | Q1, Q2, Q3, Q4, Q5, Q6 |
| 1 | 12MHZ 12MHz | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 3 | CONN_01X03_MOUNTINGPIN Conn_01x03_MountingPin | Molex_PicoBlade_53261-0371_1x03-1MP_P1.25mm_Horizontal | J1, J8, J9 |
| 2 | CONN_01X02 Conn_01x02 | AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | J2, J3 |
| 3 | CONN_01X01 Conn_01x01 | SolderWire-0.25sqmm_1x01_D0.65mm_OD2mm | J4, J5, J6 |
| 1 | USB_C_RECEPTACLE_USB2.0_16P USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_G-Switch_GT-USB-7010ASV | J7 |
| 1 | CONN_01X06_MOUNTINGPIN Conn_01x06_MountingPin | Molex_PicoBlade_53261-0671_1x06-1MP_P1.25mm_Horizontal | J10 |
| 1 | CONN_01X05_MOUNTINGPIN Conn_01x05_MountingPin | Molex_PicoBlade_53261-0571_1x05-1MP_P1.25mm_Horizontal | J11 |
| 2 | C19171390 LED RED | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1, D2 |
| 1 | C2986048 LED GREEN | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D3 |
| 2 | MBR0530 | D_SOD-123 | D4, D5 |
| 1 | C19330 fcm 1608-0603 | L_0603_1608Metric_Pad1.05x0.95mm_HandSolder | FB1 |
Show 26 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 22UH 22uH | L_SMD_4X4 | L1 |
| 19 | 100NF 100nF | C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C1, C2, C3, C4, C5, C7, C10, C11 +11 |
| 1 | 1UF 1uF | C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C6 |
| 2 | 33PF 33pF | C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C8, C9 |
| 17 | 10UF 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C12, C16, C17, C25, C26, C27, C28, C29 +9 |
| 2 | 0.1UF 0.1uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C13, C15 |
| 1 | 4.7UF 4.7uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C14 |
| 3 | 1UF 1uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C18, C20, C22 |
| 1 | 47NF 47nF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C19 |
| 1 | 2.2UF 2.2uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C23 |
| 1 | 10NF 10nF | C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C24 |
| 3 | 1NF 1nF | C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C36, C42, C46 |
| 2 | 10K 10k | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R1, R3 |
| 9 | 1k | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R2, R4, R5, R14, R20, R24, R32, R33 +1 |
| 1 | 18K 18k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R6 |
| 4 | R | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R7, R8, R10, R11 |
| 1 | 3K3 3k3 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R9 |
| 6 | 10R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R12, R15, R17, R21, R22, R25 |
| 3 | 0.01R | R_Shunt_Ohmite_LVK20 | R13, R19, R23 |
| 1 | 39K 39k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R16 |
| 1 | 2K2 2k2 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R18 |
| 1 | 1K8 1k8 | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R26 |
| 2 | 100R | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R27, R28 |
| 2 | 30R | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R29, R31 |
| 1 | 120R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R30 |
| 3 | 2k | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R35, R36, R37 |
Sf motion design files
The KiCad project lives in the sirojudinMunir/sf-motion repository on GitHub; these links point at the commit this page was built from.
Sf motion: common questions
What microcontroller does the Sf motion use?
The Sf motion is built around the STM32F405RGTX, from the STM32 family.
How big is the Sf motion PCB?
The Sf motion measures 60 × 56 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Sf motion?
123 components, from 46 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Sf motion design files?
From the sirojudinMunir/sf-motion repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Sf motion design in my own project?
Yes, under the terms of its MIT license, which sirojudinMunir chose for the repository.
Can I test firmware for the Sf motion without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k STM32
Brain board STM32F407
61.8 × 73.2 mm69 parts2LGPL-3.01.2k