
TB6612FNG

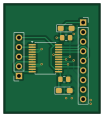
About the TB6612FNG PCB
TB6612FNG is an open source PCB design by SohumNigam, published on GitHub. It is a 2-layer board measuring 25.5 × 29 mm, with 7 components from 5 distinct parts.
Other key parts include the TB6612FNG. By type, the board carries 4 capacitors, 2 connectors and 1 IC.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
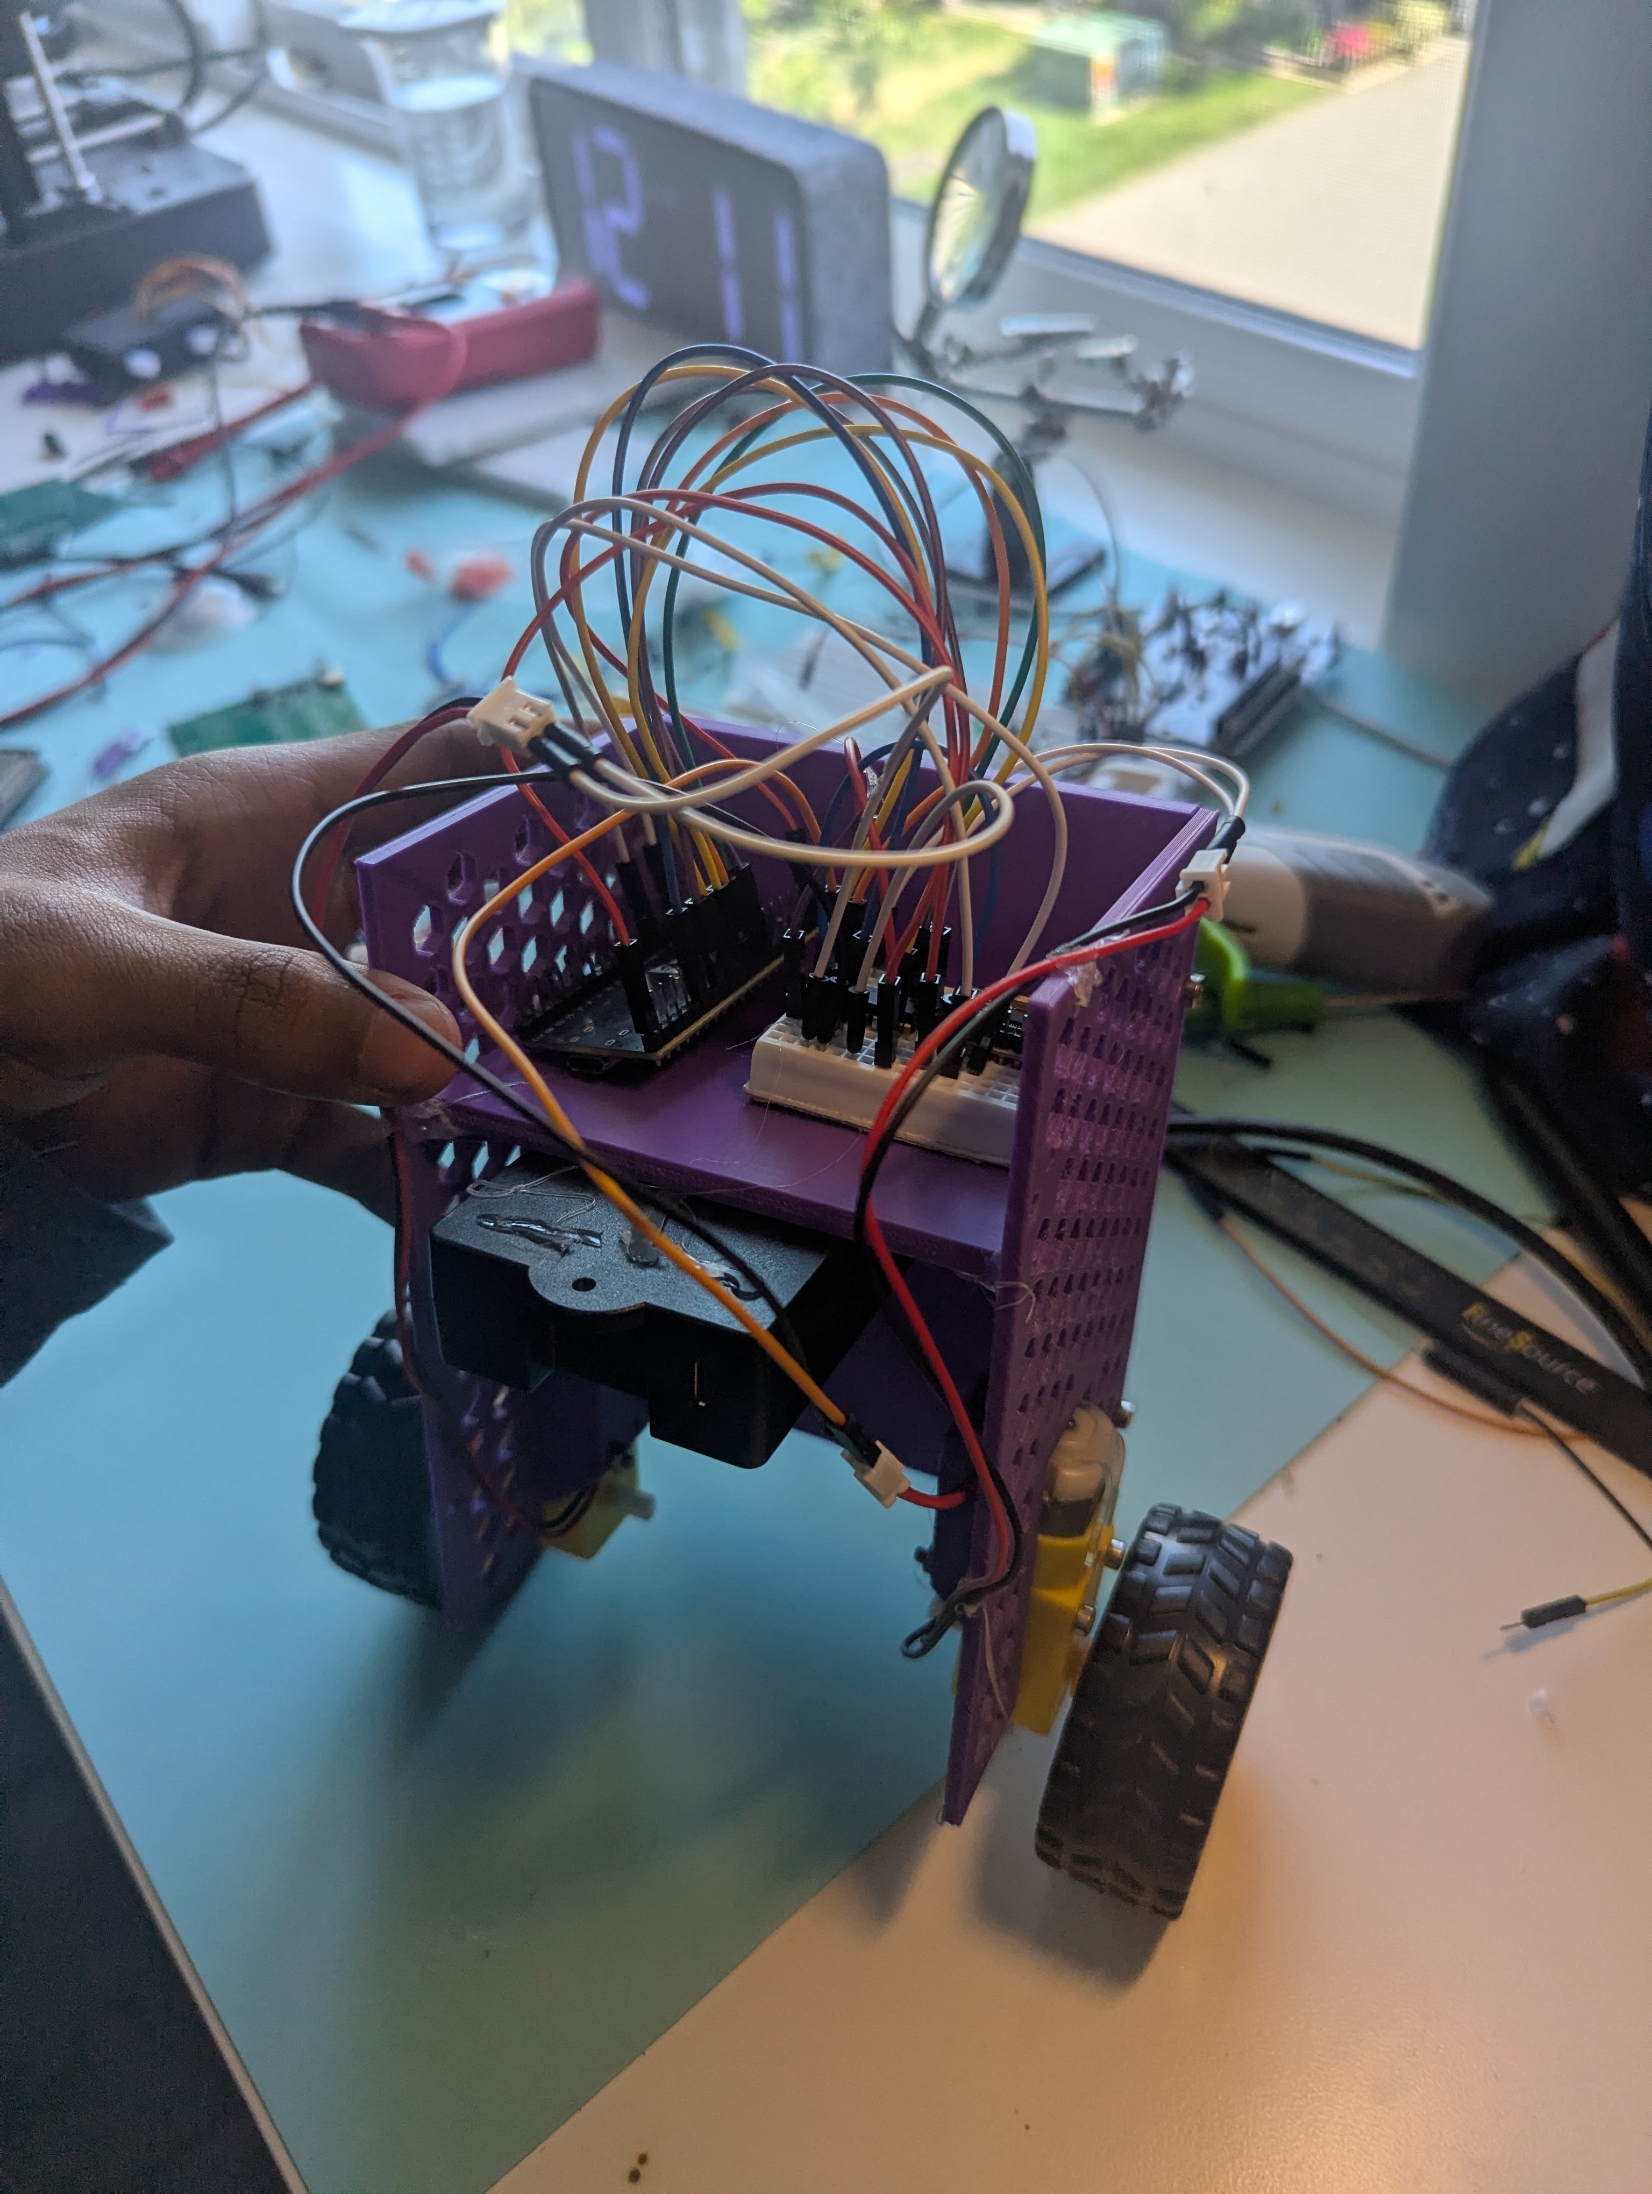
A self-balancing two-wheeled robot. an inverted pendulum stabilized by IMU feedback and PID motor control, being built up toward full 4-state LQR control on a custom PCB.
A self-balancing two-wheeled robot. an inverted pendulum stabilized by IMU feedback and PID motor control, being built up toward full 4-state LQR control on a custom PCB.
Full write-up / showcase: sohumnigam.github.io/projects/stabilitybotMK1.html
I wanted a project that went past the usual "balance a robot with a PID loop" hobby build. Something that let me go deep on control theory (state-space modeling, LQR, Kalman filtering), embedded firmware, and PCB design all at once. The long-term goal is a robot that balances using a full 4-state LQR controller (θ, θ̇, x, ẋ) on hardware I designed…
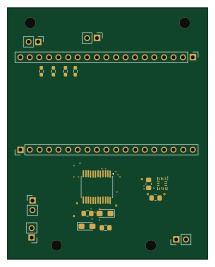
Main components on the TB6612FNG
TB6612FNG bill of materials (BOM)
7 components, 5 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TB6612FNG | SSOP-24_5.3x8.2mm_P0.65mm | U2 |
| 1 | Conn_01x09_Pin | PinSocket_1x09_P2.54mm_Vertical | J1 |
| 1 | Conn_01x05_Pin | PinSocket_1x05_P2.54mm_Vertical | J2 |
| 2 | 10uF | CP_EIA-3216-18_Kemet-A_HandSolder | C1, C2 |
| 2 | 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3, C4 |
TB6612FNG design files
The KiCad project lives in the SohumNigam/StabilityBot_MK1 repository on GitHub; these links point at the commit this page was built from.
TB6612FNG: common questions
How big is the TB6612FNG PCB?
The TB6612FNG measures 25.5 × 29 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the TB6612FNG?
7 components, from 5 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the TB6612FNG design files?
From the SohumNigam/StabilityBot_MK1 repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the TB6612FNG design in my own project?
The repository has no license, so all rights stay with SohumNigam. Use it as a reference, and ask the author before reusing the design.
More boards in StabilityBot_MK1


Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k