
Egaki

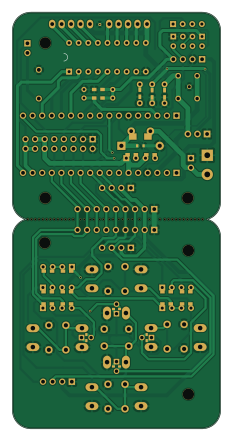
About the Egaki PCB
Egaki is an open source ESP8266 PCB design by abierto-cc, published on GitHub. It is a 2-layer board measuring 55 × 110.1 mm, with 73 components from 36 distinct parts.
Its main chip is the ESP01, from the ESP8266 family. Other key parts include the ULN2803 and LM1117-SOT. By type, the board carries 23 resistors, 11 switches, 8 LEDs, 7 ICs, 6 capacitors and 2 fuses.
It belongs with the robotics & motion designs in this gallery.
From the project
Diseño de robot basado en el Escornabot, completamente hecho en KiCAD. Con amor para todo el mundo desde Malmo - Suecia.
Diseño de robot basado en el Escornabot, completamente hecho en KiCAD.
Con amor para todo el mundo desde Malmo - Suecia.
Los creadores originales de Escornabot www.escornabot.com y su comunidad de usuarios y desarrolladores
Abierto es una inciativa de D. Cuartielles gracias a la generosa aportación de la Fundación PUIG por intermediación de la Fundación Ashoka de cara a contribuir a la creación de material educativo de libre acceso y circulación
Main components on the Egaki
Egaki bill of materials (BOM)
73 components, 36 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ULN2803 | DIP-18_W7.62mm_Socket | IC1 |
| 4 | CONN_01X04 | Pin_Header_Straight_1x04_Pitch2.54mm | U1, U3, U4, U5 |
| 1 | ESP01 | ESP01 | U2 |
| 1 | LM1117-SOT | TO-220_Vertical | U6 |
| 1 | Screw_Terminal_1x02 | bornier2 | X1 |
| 1 | FUSE | Fuse_TE5_Littlefuse-395Series | F1 |
| 1 | FUSE | R_1206_HandSoldering | F1.1 |
| 1 | CONN_01X02 | Pin_Header_Straight_1x02_Pitch2.54mm | JP1 |
| 1 | CONN_01X02 | Pin_Header_Angled_1x02_Pitch2.54mm | JP2 |
| 5 | switch | Button | S1, S2, S3, S4, S5 |
| 5 | switch | SW_PUSH_6mm | S1.1, S2.1, S3.1, S4.1, S5.1 |
| 1 | switch | on_off_Switch | S7 |
| 1 | GS3 | GS3 | SJ1 |
| 1 | JUMPER | GS2 | SJ2 |
| 1 | CONN_02X08 | Pin_Header_Straight_2x08_Pitch2.54mm | SV1 |
| 2 | CONN_01X17 | Pin_Header_Straight_1x17_Pitch2.54mm | SV2, SV3 |
| 2 | CONN_01X09 | Pin_Header_Straight_1x09_Pitch2.54mm | SV4, SV6 |
| 2 | CONN_01X05 | B5B-XH-A | XH3, XH4 |
| 1 | buzzer | MagneticBuzzer_StarMicronics_HMB-06_HMB-12 | Z1 |
| 1 | G*** | svg2mod | svg2mod |
Show 16 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | L | LED_D3.0mm | LED1, LED2, LED3, LED4 |
| 4 | L | LED_0603 | LED1.1, LED2.1, LED3.1, LED4.1 |
| 1 | ZENER | D_DO-41_SOD81_P10.16mm_Horizontal | D1 |
| 1 | ZENER | D_0603 | D1.1 |
| 1 | 100nF | C_Disc_D5.0mm_W2.5mm_P5.00mm | C2 |
| 1 | 100nF | C_0603_HandSoldering | C2.1 |
| 2 | 10uF | C_Disc_D5.0mm_W2.5mm_P5.00mm | C3, C4 |
| 2 | 10uF | C_0603_HandSoldering | C3.1, C4.1 |
| 5 | 10K | R_Array_SIP4 | R1, R2, R3, R6, R14 |
| 9 | 10K | R_0603_HandSoldering | R1.1, R2.2, R3.1, R4.1, R5.1, R7.1, R12.1, R14A.1 +1 |
| 2 | 1K | R_Array_SIP4 | R4, R5 |
| 3 | 1K | R_0603_HandSoldering | R6.1, R8.1, R9.1 |
| 1 | 100R | R_0603_HandSoldering | R10.1 |
| 1 | 10K | R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R12 |
| 1 | 18K | R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R13 |
| 1 | 18K | R_0603_HandSoldering | R13.1 |
Egaki design files
The KiCad project lives in the abierto-cc/escornabot repository on GitHub; these links point at the commit this page was built from.
Egaki: common questions
What microcontroller does the Egaki use?
The Egaki is built around the ESP01, from the ESP8266 family.
How big is the Egaki PCB?
The Egaki measures 55 × 110.1 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Egaki?
73 components, from 36 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Egaki design files?
From the abierto-cc/escornabot repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Egaki design in my own project?
The repository has no license, so all rights stay with abierto-cc. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Egaki without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP8266 firmware against it before you order a PCB.
More boards in escornabot
Similar boards
 ESP8266
ControllerCircuit
stuartpittaway
75 × 30 mm20 parts2LCC-BY-NC-4.01.1k ESP8266
HASwitchPlate
aderusha
60 × 40 mm8 parts2LMIT738 ESP8266
Goatgdo
Kaldek
32.9 × 53.3 mm23 parts2LMIT506 ESP8266
RatGDO-OpenSource-Bare-ESP8266
55 × 82.7 mm20 parts2LMIT506 ESP8266
RatGDO-OpenSource-D1Mini-ESP8266
47.8 × 63.3 mm12 parts2LMIT506 ESP8266
Iaq board
nkitanov
70.1 × 43.2 mm17 parts2LNo license398