
Self Balancing Hexapod Robot

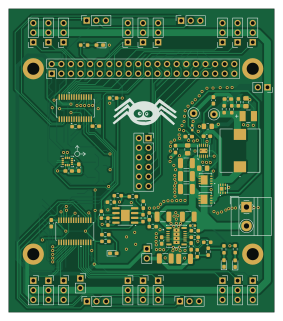
About the Self Balancing Hexapod Robot PCB
Self Balancing Hexapod Robot is an open source PCB design by aeventre, published on GitHub under the Apache-2.0 license. It is a 2-layer board measuring 70 × 80 mm, with 132 components from 53 distinct parts.
Other key parts include the TLVM13640RDLR, TPS40305DRCR, LM393, PCA9685PW and LSM6DSO32TR. By type, the board carries 52 resistors, 28 connectors, 21 capacitors, 12 jumpers, 6 ICs and 6 transistors.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
Since this project is using slightly different hardware to his and additional sensors might be placed on it in the future,some parts of the central body will eventually be modified and that CAD will be uploaded here.
Since this project is using slightly different hardware to his and additional sensors might be placed on it in the future,some parts of the central body will eventually be modified and that CAD will be uploaded here.
For this project a custom PCB was designed to rest on top of a Raspberry pi 4b in order to make the wiring for everything neater and because PCB design is fun.
Main components on the Self Balancing Hexapod Robot
Self Balancing Hexapod Robot bill of materials (BOM)
132 components, 53 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TLVM13640RDLR | B3QFN20_RDL_TEX | U1 |
| 1 | TPS40305DRCR | VSON-10-1EP_3x3mm_P0.5mm_EP1.2x2mm_ThermalVias | U2 |
| 1 | LM393 | SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.29x3mm | U3 |
| 2 | PCA9685PW | SOT361-1_NXP | U4, U5 |
| 1 | LSM6DSO32TR | LGA-14L_2P5X3X0P83_STM | U6 |
| 2 | CSD17304Q3 | 8VSON | Q1, Q2 |
| 1 | CSD13202Q2 | Q2_SON6_TEX | Q3 |
| 3 | BSS138 | SOT-23_3L_ONS | Q4, Q5, Q6 |
| 1 | Ras Pi 4 Interface | PinSocket_2x20_P2.54mm_Vertical | J1 |
| 1 | Leg Switches | PinSocket_2x06_P2.54mm_Vertical | J2 |
| 1 | 5V Connect | PinSocket_1x02_P2.54mm_Vertical | J3 |
| 1 | Terminal Block | TerminalBlock_MetzConnect_Type011_RT05502HBWC_1x02_P5.00mm_Horizontal | J4 |
| 1 | 6V Connect | PinSocket_1x02_P2.54mm_Vertical | J5 |
| 22 | Conn_01x03 | PinSocket_1x03_P2.54mm_Vertical | J6, J7, J8, J9, J10, J11, J12, J13 +14 |
| 1 | 5V to 6V Connect | PinSocket_1x02_P2.54mm_Vertical | J28 |
| 12 | SolderJumper_2_Open | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | JP1, JP2, JP3, JP4, JP5, JP6, JP7, JP8 +4 |
| 1 | 6V Line | TestPoint_Loop_D1.80mm_Drill1.0mm_Beaded | TP1 |
| 1 | U1 Feedback | TestPoint_Loop_D1.80mm_Drill1.0mm_Beaded | TP2 |
| 1 | LED Blue | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1 |
| 2 | LED Green | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D2, D3 |
Show 33 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LED Red | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D4 |
| 1 | 240nH | IND_IHLP-4040DZ_VIS | L1 |
| 1 | 8.2pF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1 |
| 2 | 10uF | C_1210_3225Metric_Pad1.33x2.70mm_HandSolder | C2, C3 |
| 5 | 47uF | C_1210_3225Metric_Pad1.33x2.70mm_HandSolder | C4, C5, C7, C8, C9 |
| 1 | 1uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C6 |
| 1 | 1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C10 |
| 1 | 2.2uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C11 |
| 1 | 3300pF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C12 |
| 3 | 0.1uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C13, C20, C21 |
| 1 | 330pF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C14 |
| 1 | 1200pF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C15 |
| 1 | 47uF | PCAP_TPE_B2_PAN_1411 | C16 |
| 1 | 270pF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C17 |
| 2 | 10uF | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C18, C19 |
| 31 | 10k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2, R4, R5, R6, R7, R8, R9 +23 |
| 1 | 1.2k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3 |
| 3 | 100k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10, R15, R17 |
| 1 | 42.2k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R11 |
| 1 | 84.5k | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R12 |
| 1 | 11.8k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R13 |
| 3 | 1.6k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R16, R23, R25 |
| 1 | 2.1k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R18 |
| 1 | 17.4k | R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R20 |
| 1 | 1.1k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R21 |
| 1 | 3.2k | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | R22 |
| 1 | 51k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R24 |
| 1 | 750k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R28 |
| 1 | 82k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R30 |
| 1 | 1k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R31 |
| 1 | 27k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R32 |
| 1 | 30k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R33 |
| 1 | 2k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R35 |
Self Balancing Hexapod Robot design files
The KiCad project lives in the aeventre/Self_Balancing_Hexapod_Robot repository on GitHub; these links point at the commit this page was built from.
Self Balancing Hexapod Robot: common questions
How big is the Self Balancing Hexapod Robot PCB?
The Self Balancing Hexapod Robot measures 70 × 80 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Self Balancing Hexapod Robot?
132 components, from 53 distinct parts. The full bill of materials is listed on this page.
Where can I download the Self Balancing Hexapod Robot design files?
From the aeventre/Self_Balancing_Hexapod_Robot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Self Balancing Hexapod Robot design in my own project?
Yes, under the terms of its Apache-2.0 license, which aeventre chose for the repository.
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k