
Navigator

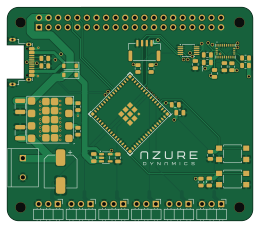
About the Navigator PCB
Navigator is an open source ESP32 PCB design by azure-dynamics, published on GitHub under the CERN-OHL-S-2.0 license. It is a 4-layer board measuring 65 × 56.5 mm, with 49 components from 23 distinct parts.
Its main chip is the ESP32-S3-MINI-1U, from the ESP32 family. Other key parts include the AP2112K-3.3, MPM3550EGLE, BNO086 and INA226. By type, the board carries 17 resistors, 13 capacitors, 10 connectors, 5 ICs, 2 switches and 2 diodes.
It belongs with the sensors and robotics & motion designs in this gallery.
From the project
Flight-controller Pi HAT for Azure Dynamics' Radiance ROV
Flight-controller Pi HAT for Azure Dynamics' Radiance ROV
Navigator is a Raspberry Pi HAT designed to host the low-level flight controller for the Radiance ROV. It manages communication between the Raspberry Pi and the ROV's hardware, monitoring system power and routing control signals.
Flight Control: Powered by an ESP32-S3 processor. Power Management: On-board voltage regulation supplying power directly to the Raspberry Pi and HAT logic. Propulsion Signals: Six dedicated ESC signal outputs for motor control. Sensor Integration: Includes battery voltage monitoring and I2C expansion support…
Main components on the Navigator
Navigator bill of materials (BOM)
49 components, 23 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AP2112K-3.3 | SOT-23-5 | U1 |
| 1 | MPM3550EGLE | MPS_LGA-18-10EP_12x12mm_P3.3mm | U2 |
| 1 | BNO086 | BNO086 | U3 |
| 1 | ESP32-S3-MINI-1U | ESP32-S3-MINI-1U | U4 |
| 1 | INA226 | TSSOP-10_3x3mm_P0.5mm | U5 |
| 6 | BLDC-1 | PinHeader_1x03_P2.54mm_Horizontal | J1, J2, J3, J4, J5, J6 |
| 1 | CONN_01X02_PIN Conn_01x02_Pin | 282837-2 | J7 |
| 1 | USB_C_RECEPTACLE_USB2.0_16P USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_Amphenol_12401948E412A | J8 |
| 1 | CONN_01X04_PIN Conn_01x04_Pin | JST_GH_BM04B-GHS-TBT_1x04-1MP_P1.25mm_Vertical | J9 |
| 1 | GPIO | PinSocket_2x20_P2.54mm_Vertical | J10 |
| 2 | SW_SPST | SW_SPST_TL3305A | SW1, SW2 |
| 2 | D_Schottky | D_SOD-123 | D1, D2 |
| 1 | 100UF 100uF | CP_Elec_8x10.5 | C1 |
| 1 | 10UF 10uF | C_1210_3225Metric | C2 |
| 2 | 10UF 10uF | C_0805_2012Metric | C3, C6 |
| 2 | 1UF 1uF | C_0805_2012Metric | C4, C12 |
| 1 | 47UF 47uF | C_1210_3225Metric | C5 |
| 6 | 0.1UF 0.1uF | C_0805_2012Metric | C7, C8, C9, C10, C11, C13 |
| 11 | 10K 10k | R_0805_2012Metric | R1, R2, R3, R4, R5, R6, R9, R14 +3 |
| 1 | 100K 100k | R_0805_2012Metric | R7 |
Show 3 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 14K3 14k3 | R_0805_2012Metric | R8 |
| 2 | 5K1 5k1 | R_0805_2012Metric | R10, R11 |
| 2 | 2K2 2k2 | R_0805_2012Metric | R12, R13 |
Navigator design files
The KiCad project lives in the azure-dynamics/navigator repository on GitHub; these links point at the commit this page was built from.
Navigator: common questions
What microcontroller does the Navigator use?
The Navigator is built around the ESP32-S3-MINI-1U, from the ESP32 family.
How big is the Navigator PCB?
The Navigator measures 65 × 56.5 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Navigator?
49 components, from 23 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Navigator design files?
From the azure-dynamics/navigator repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Navigator design in my own project?
Yes, under the terms of its CERN-OHL-S-2.0 license, which azure-dynamics chose for the repository.
Can I test firmware for the Navigator without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k